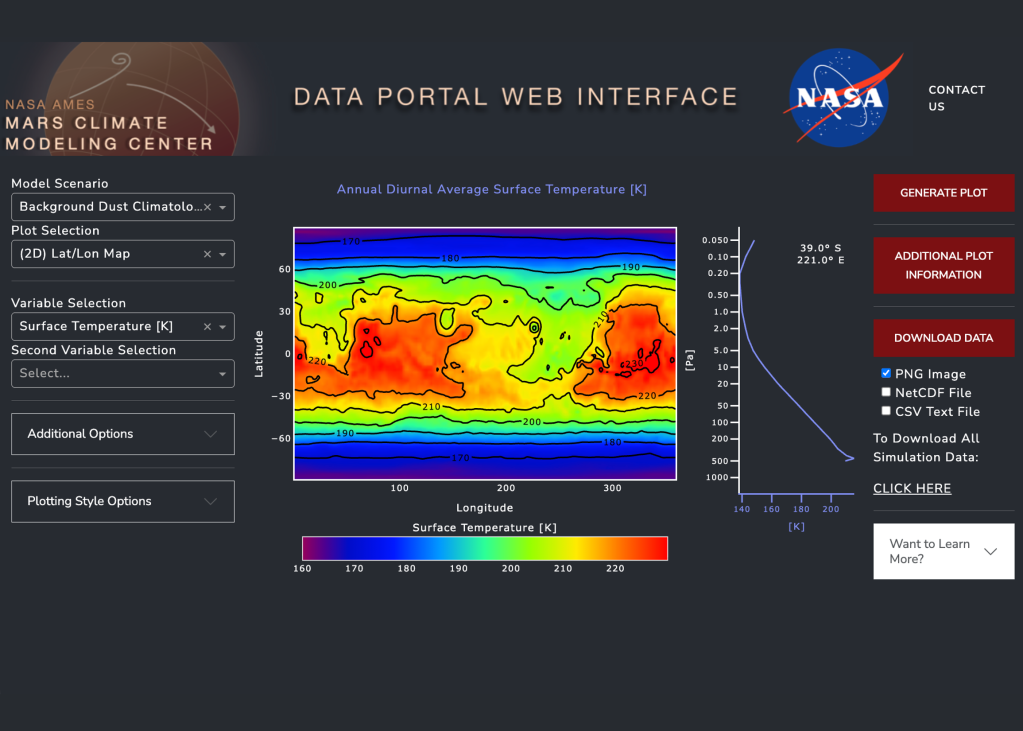
The Mars Climate Modeling Center (MCMC) presents the webserver, a website for interactive plotting and downloading Mars Global Climate Model (MGCM) output.
The model visualization tool offers the most accessible introduction to Mars Global Climate Model (MGCM) data. It is an online dashboard that allows users to interactively plot, explore, and download model output stored on the NAS Data Portal (see the MGCM Output tab for more information).
GCM analysis tools
MGCM Webserver
You can explore, plot, and download the MGCM output through our user-friendly web interface.
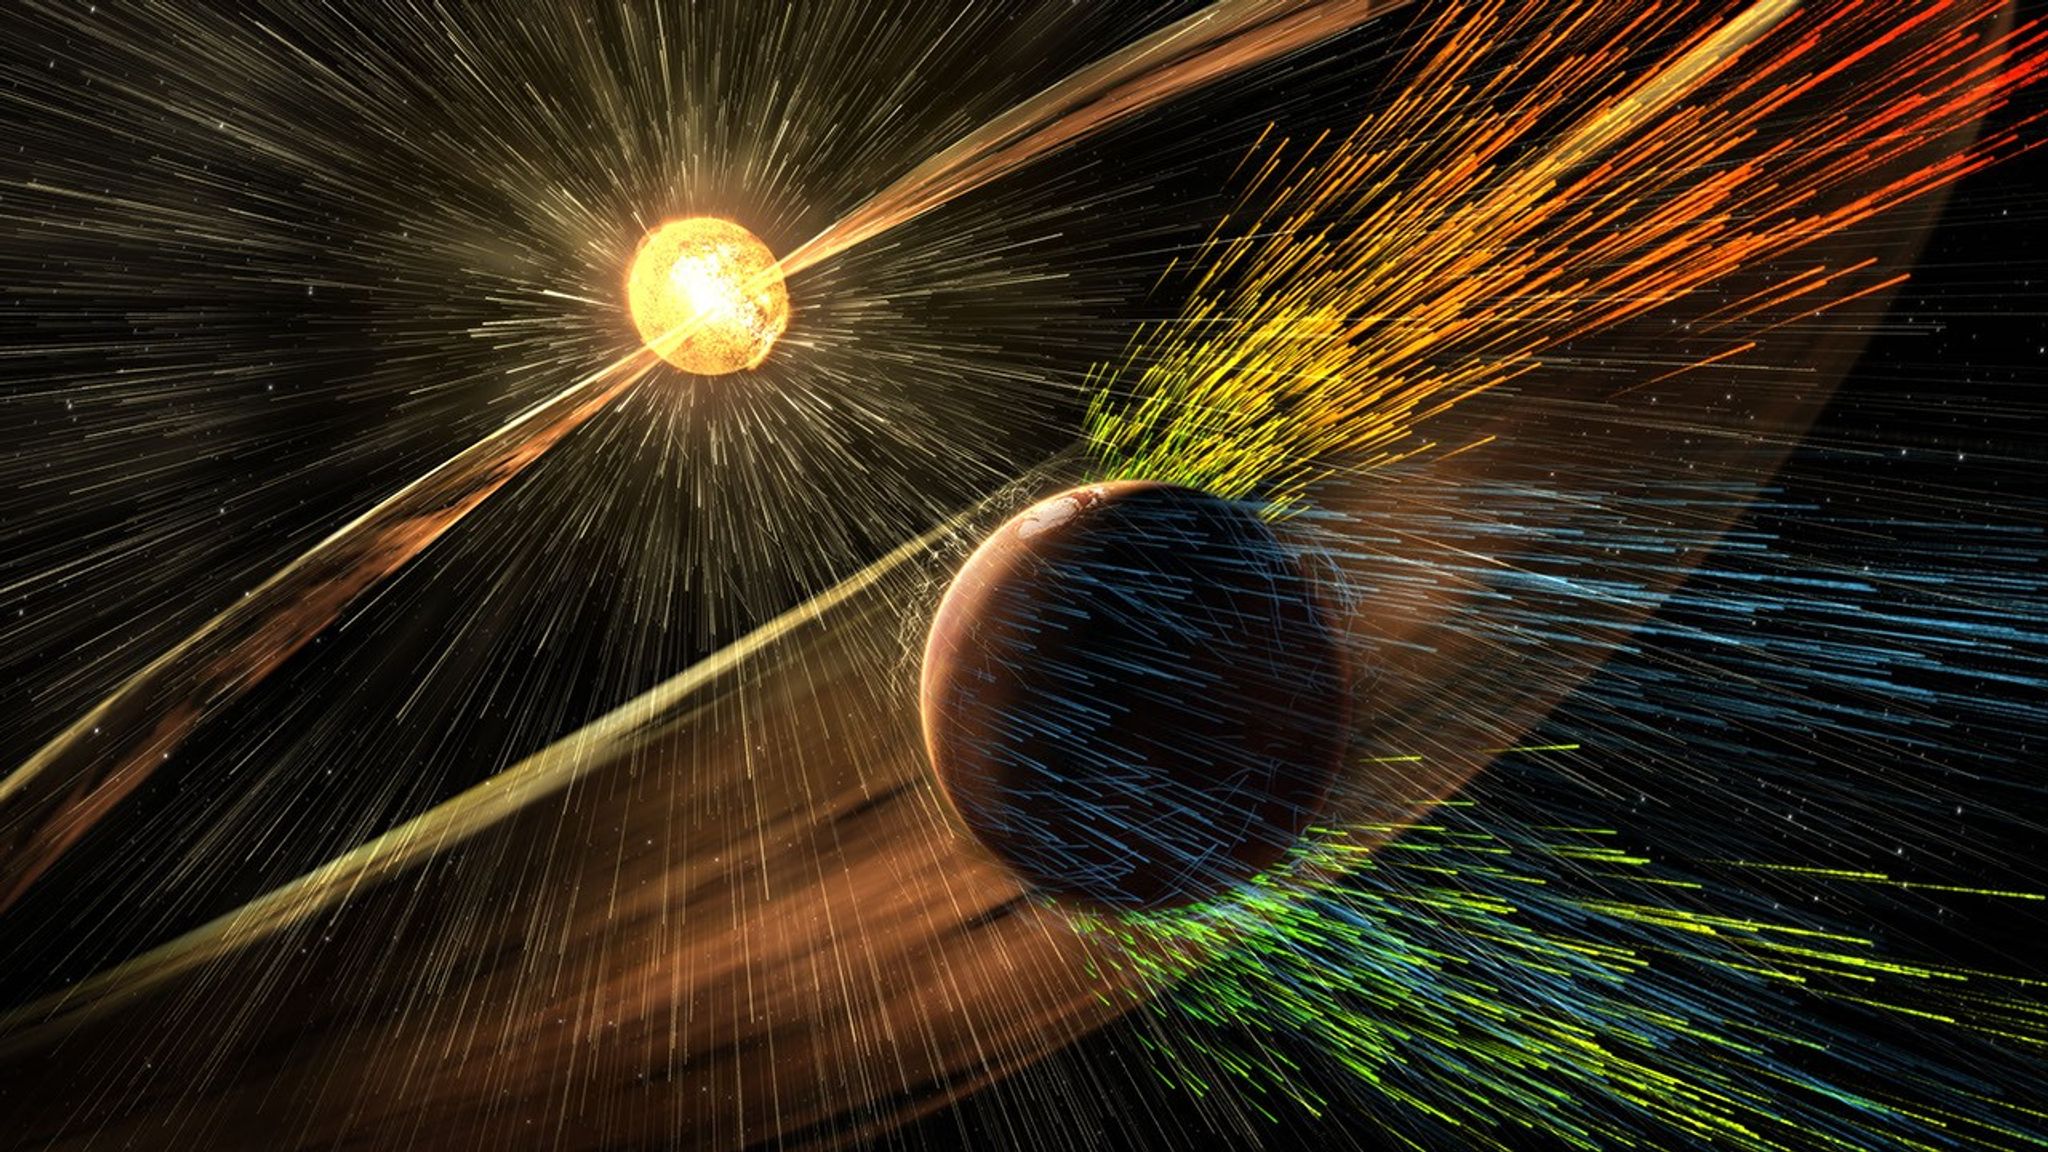
This illustration depicts charged particles from a solar storm stripping away charged particles of Mars’ atmosphere, one of the processes of Martian atmosphere loss studied by NASA’s MAVEN mission.
NASA/GSFC
NASA MAVEN (Mars Atmosphere and Volatile Evolution) mission scientists have uncovered a key puzzle piece in understanding certain types of auroras on Mars, finding that they form in a similar way to Earth-based auroras.
Results published Thursday in Nature Communications show the same mechanism that circulates and catapults charged particles into Earth’s atmosphere is happening at Mars on much smaller scales because of differences in the two planets’ magnetic fields.
The MAVEN spacecraft, in orbit around Mars, experienced a loss of signal with ground stations on Earth on Dec. 6, 2025. On June 3, NASA declared the mission had concluded after finding the spacecraft to be unrecoverable. However, data from the mission is still being used to inform NASA science and future missions to Mars.
When the Sun’s magnetic field lines get close to Earth’s magnetosphere, the large magnetic bubble protecting the planet, they can reconnect and inject energy and mass throughout Earth’s magnetosphere and magnetotail, ultimately firing electrons back into the atmosphere to generate Earth’s auroras. This process, called the Dungey cycle, drives electrical currents, accelerates charged particles that create auroras, and controls the circulation of plasma in Earth’s magnetosphere and ionosphere.
This new study shows that a miniature version of the Dungey cycle is happening over Mars’ strong crustal magnetic fields, which gives scientists a better look into the physics of Martian auroras.
“We knew that magnetic reconnection was happening at Mars but did not expect it to be like the Dungey cycle,” said Shaosui Xu, lead author of the study and associate research physicist at the Space Sciences Laboratory at the University of California, Berkeley.
Mars does not have a global magnetic field like Earth. Earth’s magnetic field is created by our planet’s churning core, while Mars has numerous miniature magnetospheres that arise from intensely magnetized crust scattered around the planet. These regions were formed around 4 billion years ago when lava cooled in the presence of Mars’ ancient global magnetic field, which has since disappeared due to intense solar wind stripping the planet’s atmosphere.
The MAVEN mission has observed highly localized auroras over these crustal fields, similar to Earth’s auroras at the poles, but it wasn’t until now that scientists could fully understand the physics of how they form. The study used several instruments aboard the MAVEN spacecraft to build up a picture of the Dungey-like behavior: the Magnetometer and Solar Wind Electron Analyzer instruments, which were used to determine the magnetic configuration and derive electrical currents, and the STATIC (Suprathermal and Thermal Ion Composition) instrument, which was used to measure plasma flows in the ionosphere.
“We really pushed the limit of STATIC to get the data we needed,” said Xu. “It was the final piece to the puzzle in understanding these localized auroras.”
The realization that a Dungey-like cycle was happening within these crustal magnetic fields answered the question of how the electrons were being energized to create the auroras. It also shows that a Dungey-like mechanism can happen on both large and small scales, giving more insight into where in the solar system this process could be taking place.
“This is a remarkable result that changes how we think of Martian auroras and is another important step toward understanding why Mars and Earth have evolved so differently despite being governed by the same underlying physics.” said Shannon Curry, MAVEN’s principal investigator and a research scientist at the Laboratory for Atmospheric and Space Physics at the University of Colorado Boulder. “I am incredibly proud of our team’s work on this discovery and excited to uncover new insights into the Red Planet and its evolution.”
By finding out more about this process, scientists also are gaining a better understanding of how the solar environment interacts with the Red Planet as a whole, which is essential for future robotic and crewed missions.
“I remember in graduate school discussing with my advisor how the cycling of crustal magnetic fields could work at Mars,” said Xu. “It’s incredible to be part of the team that found the answer to that question.”
The MAVEN mission is part of NASA’s Mars Exploration Program portfolio. The mission’s principal investigator is based at the Laboratory for Atmospheric and Space Physics at the University of Colorado Boulder, which also is responsible for managing science operations and public outreach and communications. NASA’s Goddard Space Flight Center in Greenbelt, Maryland, manages the MAVEN mission. Lockheed Martin Space built the spacecraft and is responsible for mission operations. NASA’s Jet Propulsion Laboratory in Southern California provides navigation and Deep Space Network support.
For more information on NASA’s MAVEN mission, visit:
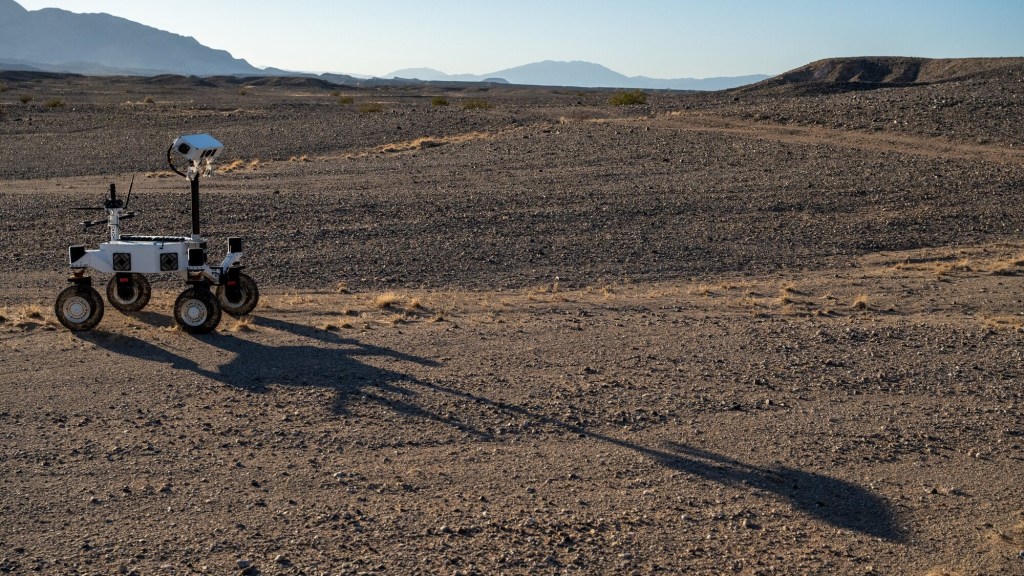
Developed at NASA’s Jet Propulsion Laboratory, ERNEST (Exploration Rover for Navigating Extreme Sloped Terrain) is used in a desert field test to help refine mobility hardware and autonomy software that could be used for a potential future long-range lunar rover mission.
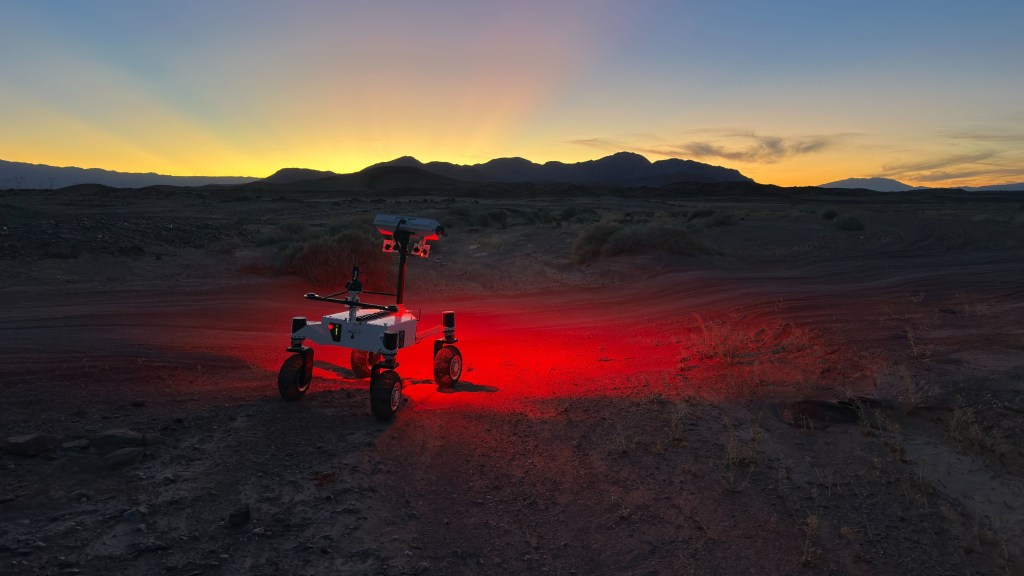
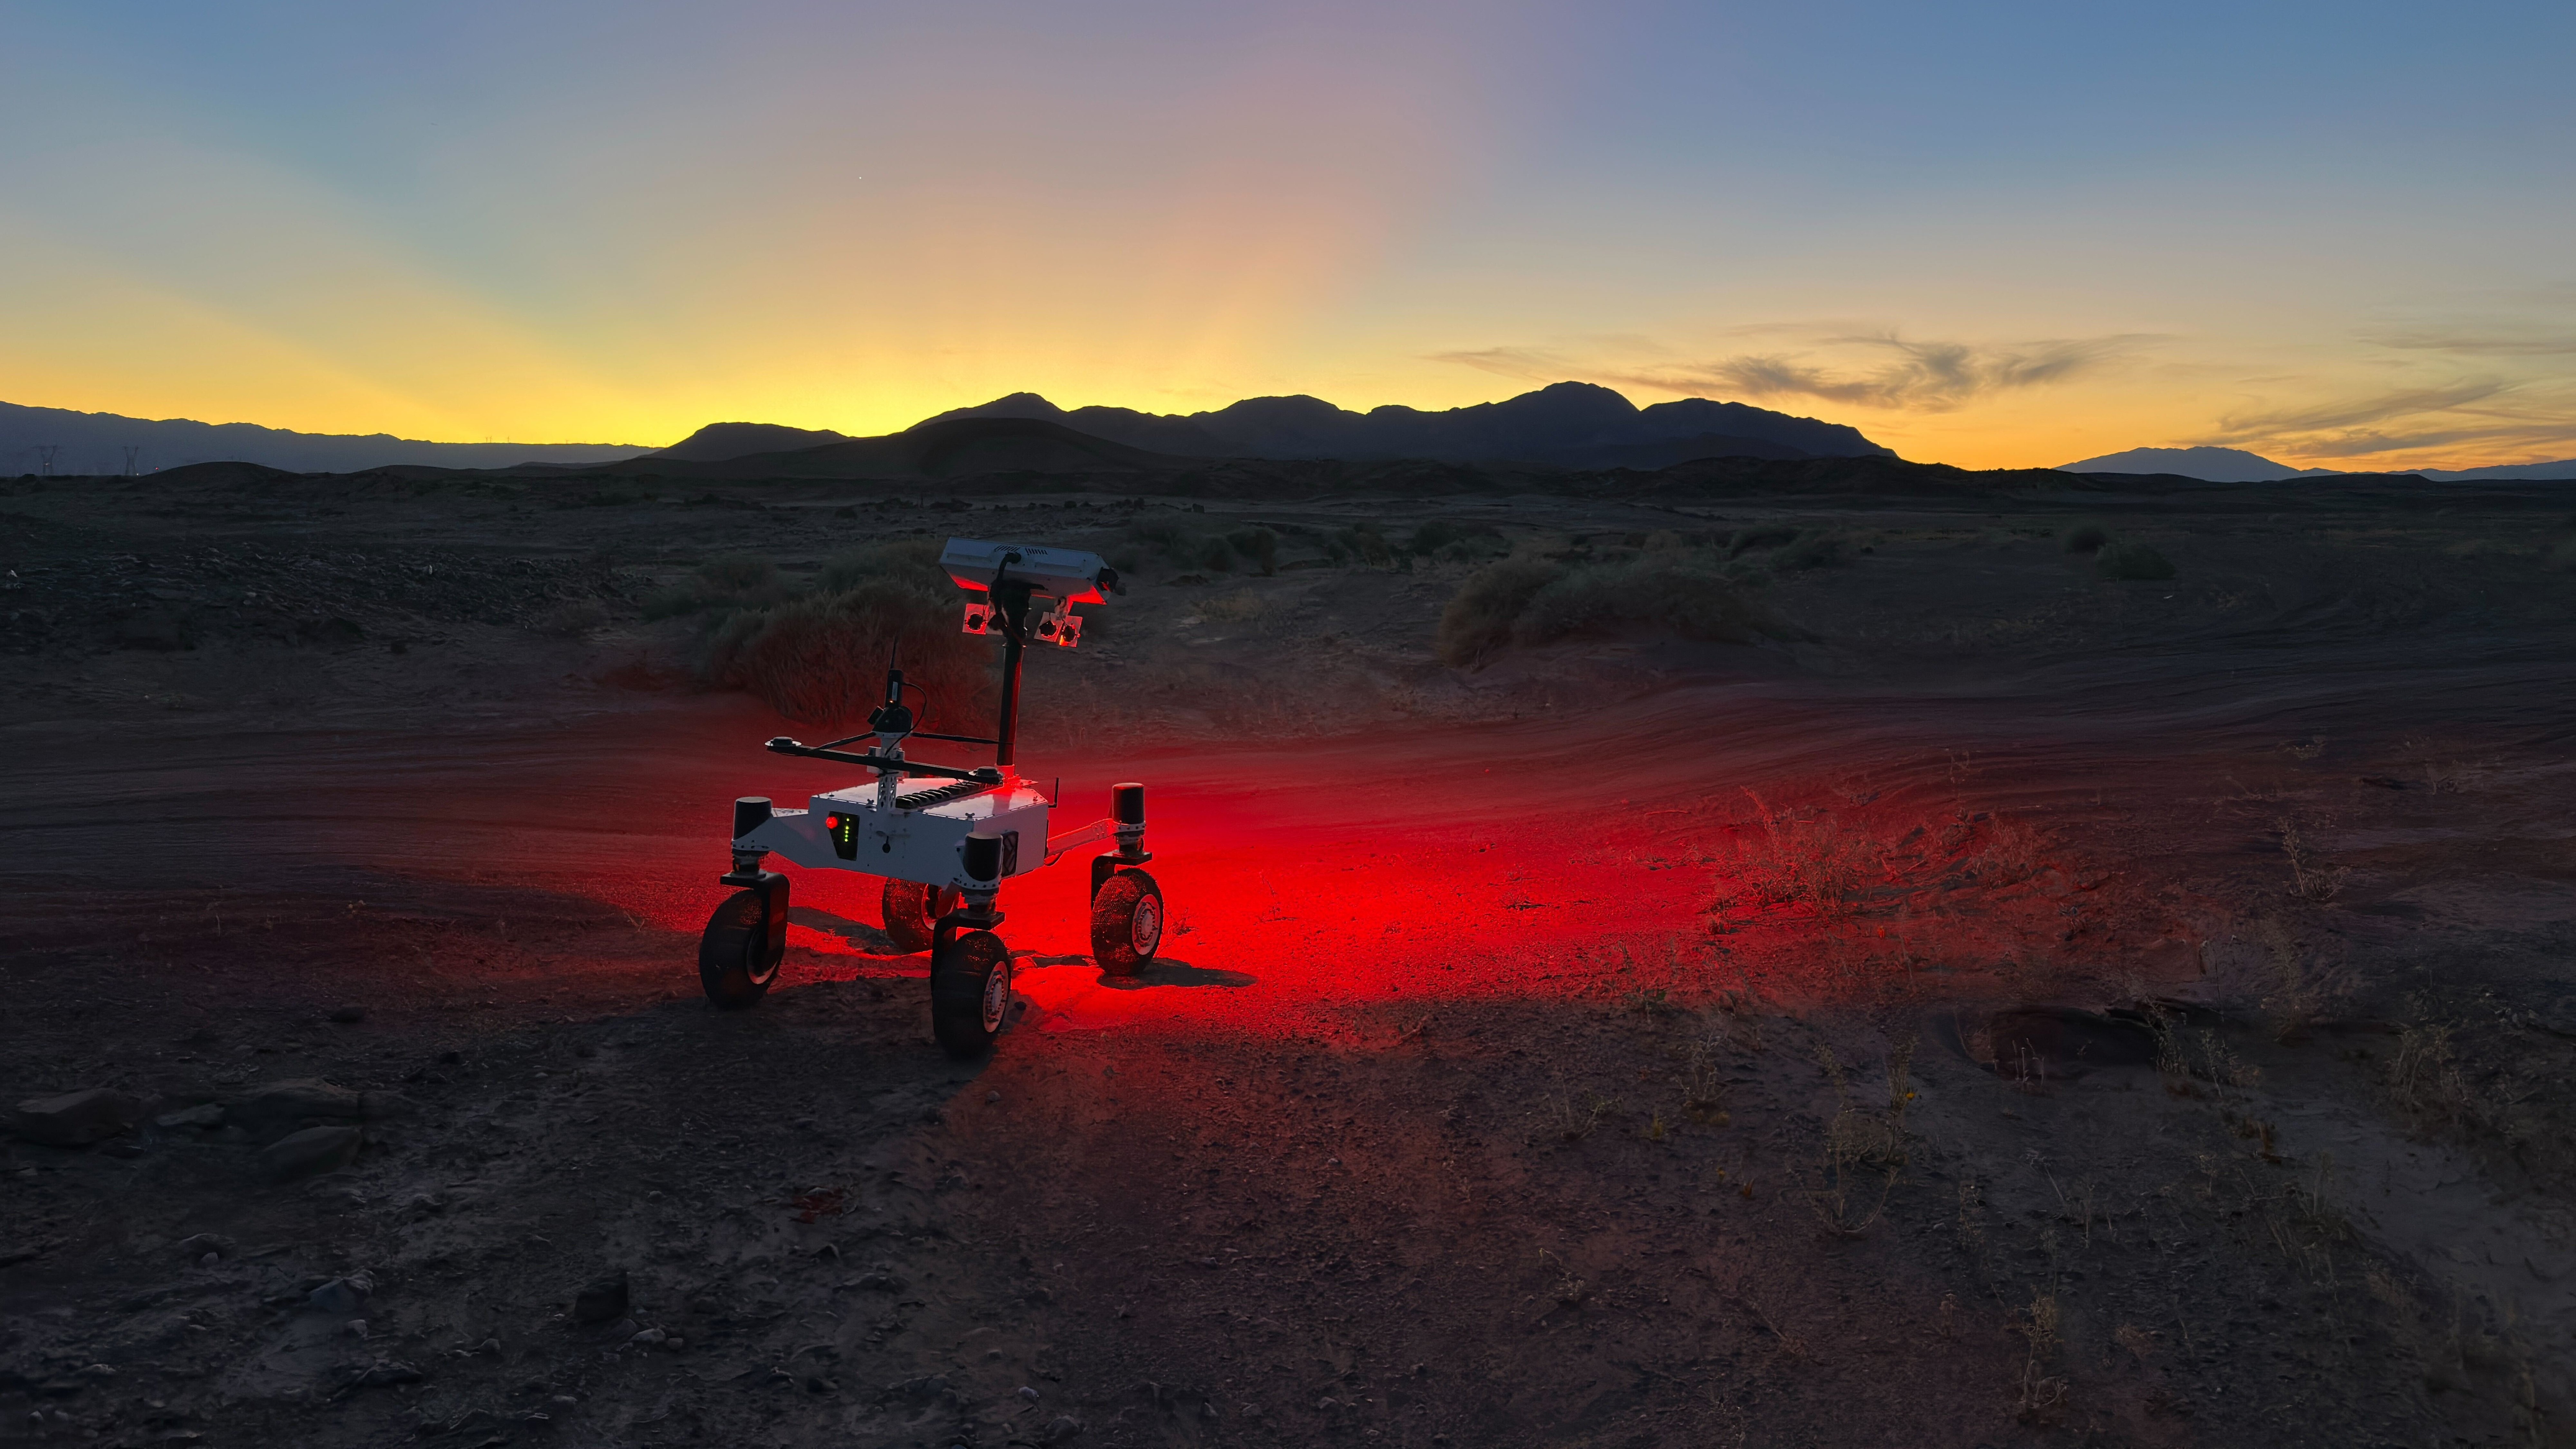
During the field test, which took place in March 2026 in the Colorado Desert of Southern California, the JPL team deployed ERNEST at all times of the day — including dusk, dawn, and nighttime, when lighting conditions create long shadows like those seen on the Moon’s polar regions.
On a bleak stretch of the Colorado Desert in Southern California, a compact four-wheeled rover recently trundled about 16 miles (26 kilometers) with minimal intervention from the team of engineers trailing it. Called ERNEST (Exploration Rover for Navigating Extreme Sloped Terrain), this prototype is being used by NASA to advance both robotic autonomy and the ability to traverse challenging landscapes.
Developed at NASA’s Jet Propulsion Laboratory in Southern California, ERNEST is 4 feet (1.2 meters) long. Not only can it lift each of its mesh wheels to get past obstacles that would stymie Curiosity and Perseverance, NASA’s six-wheeled Mars rovers, but the prototype also has enhanced independent decision-making capabilities. These mobility and autonomy advances could be infused into future missions that will venture to previously inaccessible areas of the Red Planet or the Moon.
ERNEST serves as a testbed for a potential future lunar rover mission requiring high speeds and extreme distances. In a recent field test, the prototype traveled 16 miles over the course of 37 hours, going an order of magnitude above the top speed at which NASA’s current Mars rovers can navigate. Credit: NASA/JPL-Caltech
In the field, ERNEST served as a testbed for a potential future lunar mission requiring higher speeds and much greater mileage than can be accomplished by current rovers. This technology could be used to inform future designs for exploration efforts on the Moon and beyond.
“This testing is helping us refine the mobility hardware and autonomy software to navigate extreme distances across a wide range of terrain and lighting conditions anticipated on the Moon,” said Issa Nesnas, a principal technologist at JPL who led the recent testing as head of autonomy for a NASA mission concept for a potential future long-range lunar rover.
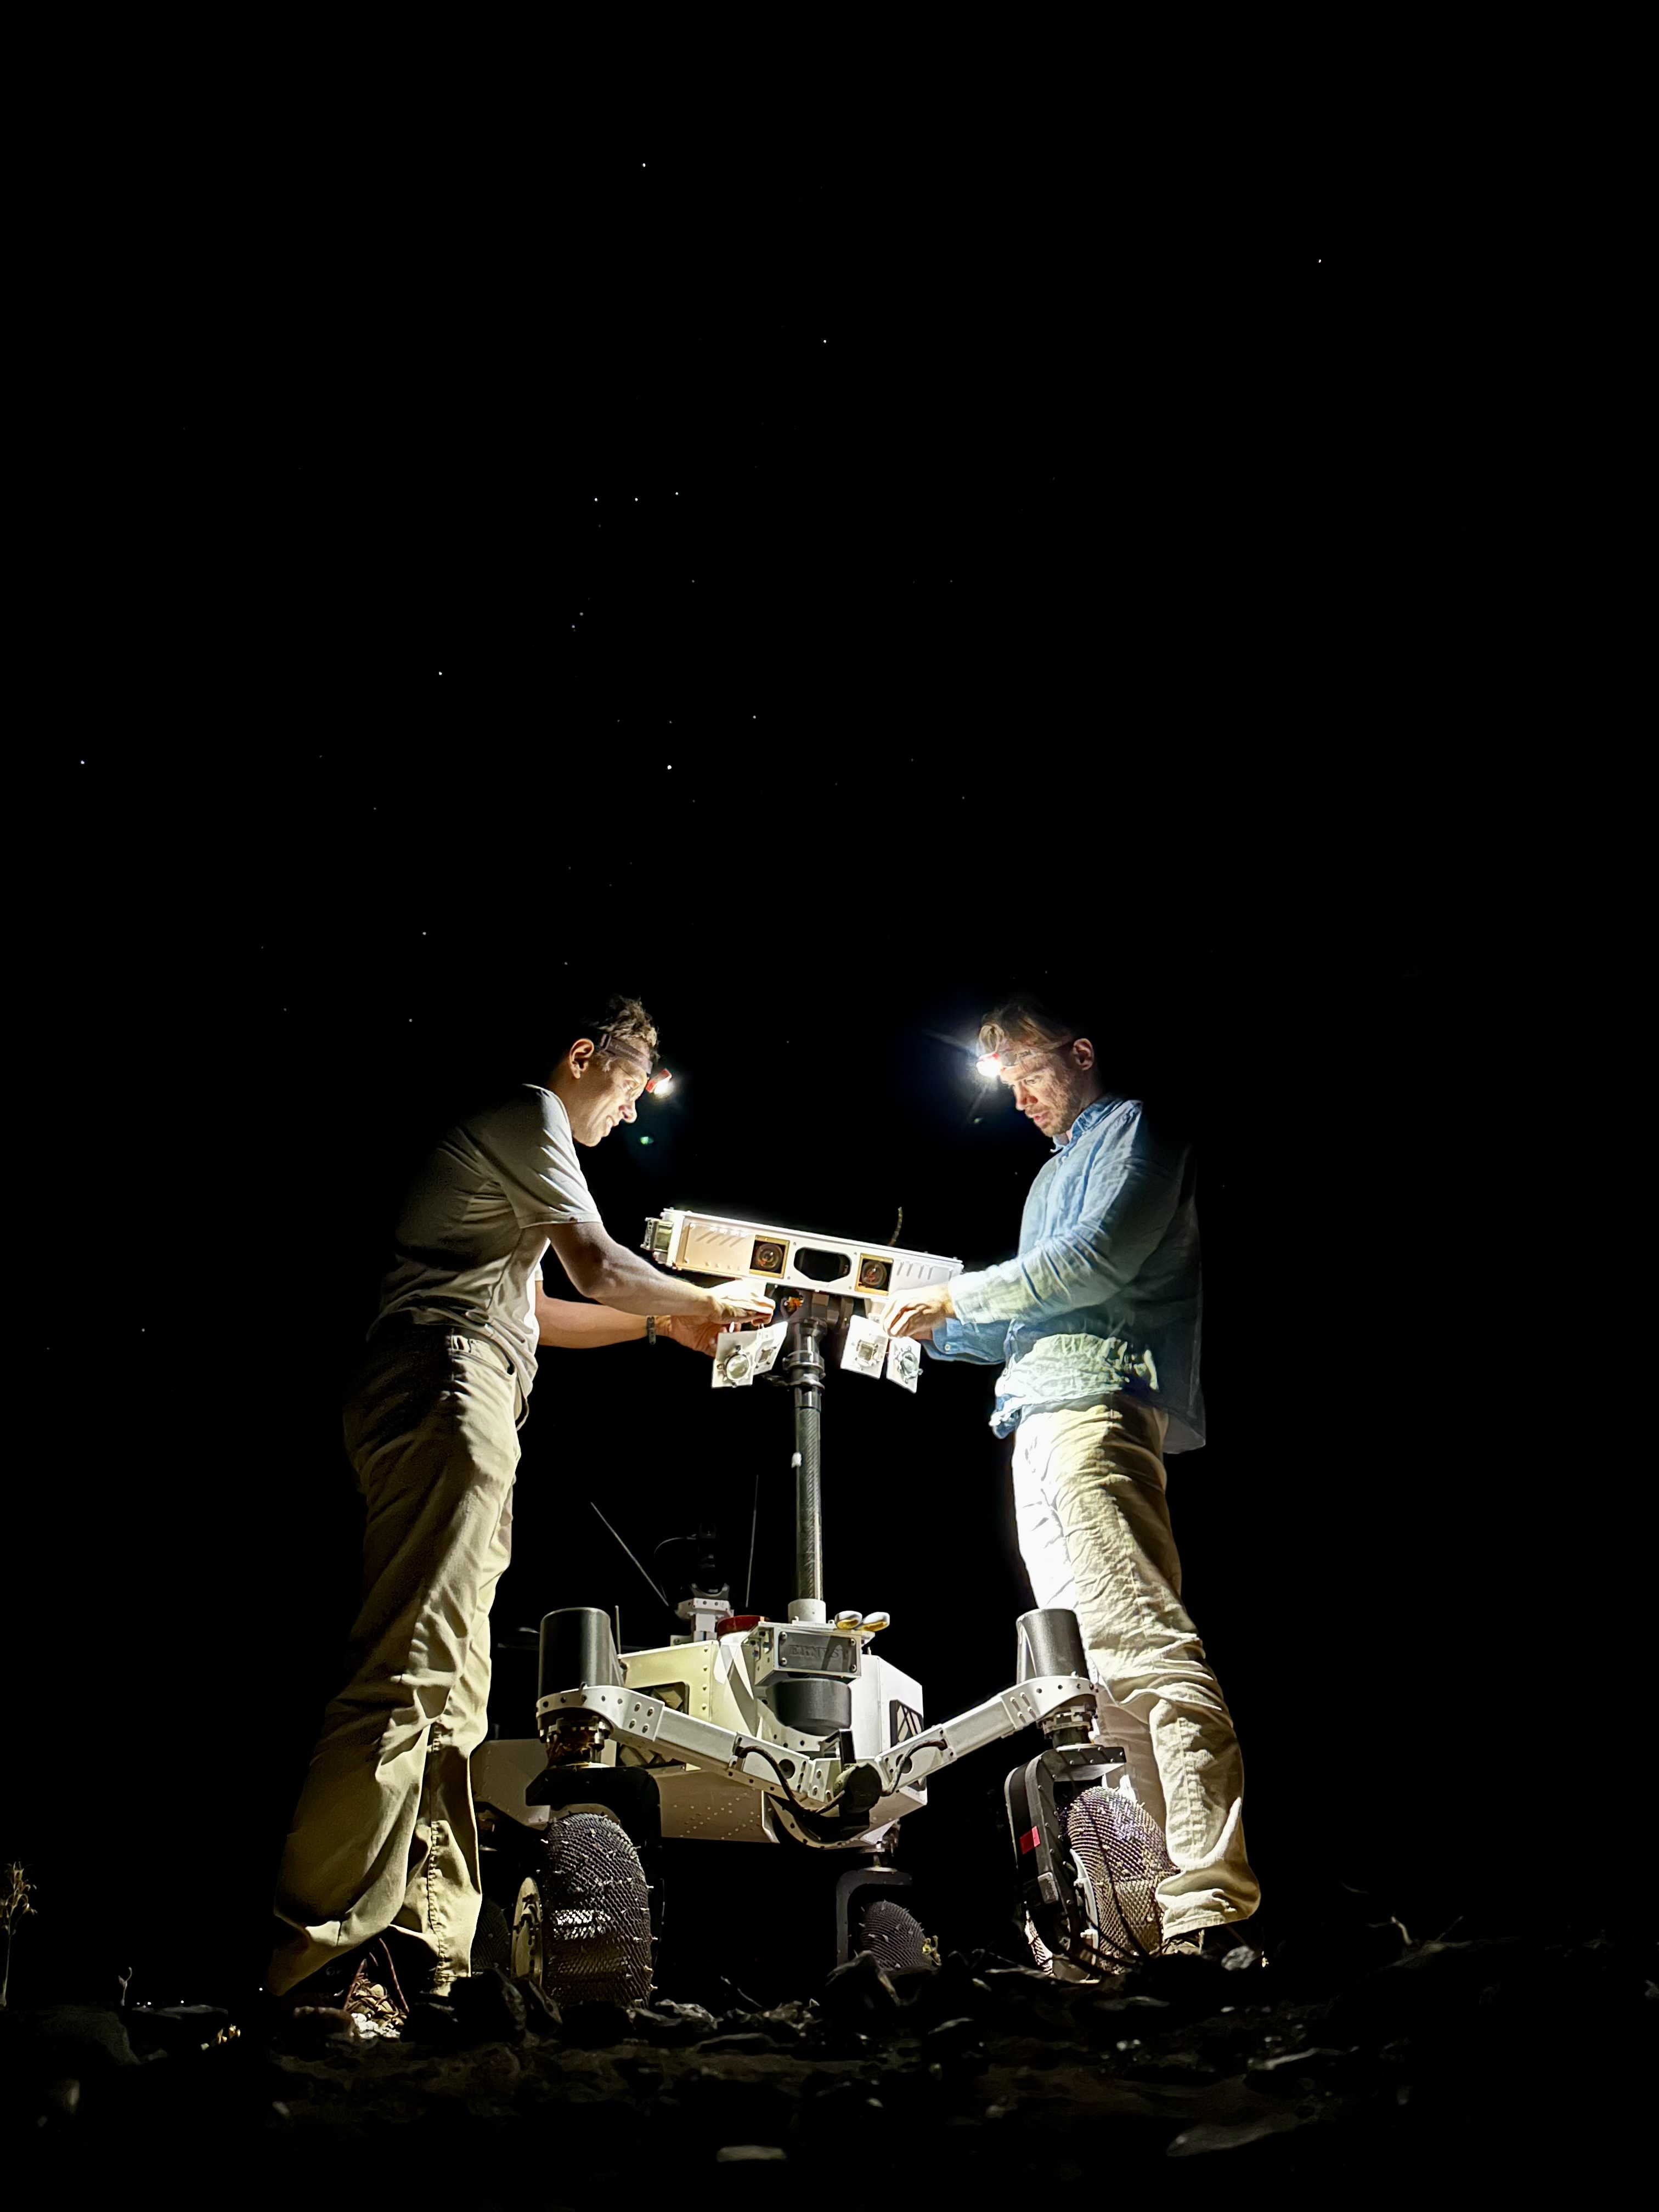
Engineers from JPL set up illuminators after transporting ERNEST for a pre-sunrise test during a seven-day desert field campaign.
NASA/JPL-Caltech
Nesnas’ team is using ERNEST to demonstrate it is possible to build a rover that’s twice as big as the prototype and capable of a long-distance Moon mission. During the recent campaign, ERNEST traveled at speeds up to 0.6 mph (1 kph) over 37 hours of driving, across seven days of intermittent testing. That’s an order of magnitude above the top speed Perseverance and Curiosity can navigate.
“You could do a science road trip across the Moon — or Mars — with this vehicle,” said James Keane, a JPL planetary scientist working on lunar missions.
The initial goal of the team that developed ERNEST was mechanical: to design a relatively simple, low-cost rover that advances the trusted rocker-bogie suspension system featured on every Mars rover since NASA’s Sojourner. This passive system keeps relatively constant weight on all six wheels, thanks to pivot points and struts that enable each one to adapt to the changing surface.
The mobility and autonomy advances developed at JPL for the ERNEST prototype rover could be infused into future NASA missions to previously inaccessible areas of the Red Planet or the Moon. Credit: NASA/JPL-Caltech
On ERNEST, the active suspension lets the rover manage weight distribution among its wheels. Two powered joints in front articulate a gimbal that allows the rover to drive using different gaits like squirming, wheel-walking, and obstacle-climbing. With a clutch mechanism, it can switch between active and passive suspension, which is less terrain capable but more energy efficient. With four steerable wheels, it can drive in any direction, including sideways.
“We started by postulating that we could do better in designing a planetary surface robotic mobility system,” said Hari Nayar, a JPL principal technologist leading the ERNEST team. “While the rocker-bogie system has been very successful over the past 30 years, there’s been a lot of research in that time on mobility and understanding terrain interaction.”
Before arriving at today’s version of ERNEST, the team built two earlier prototypes, each about 2 feet (0.6 meters) long, to test 11 active suspension configurations. In a trailer filled with lunar regolith simulant, they ran experiments at different slope angles over several months before landing on a final design.
Then the team scaled up, including adding a rectangular head mounted on a 4.5-foot-tall (1.4-meter-tall) mast. The hardware was completed in September 2024, but the rover still needed a human operator to joystick it, sending commands to instruct the rover on how to move over obstacles.
In order to train the rover to think on its own, the ERNEST team turned to reinforcement learning, a type of artificial intelligence where the robot learns by interacting with its environment. The Dynamics and Real-Time Simulation Laboratory at JPL developed a high-fidelity virtual testing environment that replicates the rover’s behavior. The team fed the simulator data collected by engineers who documented the response of the actual rover hardware to a variety of terrain types. On a high-performance computing cluster, the team ran many simulations at once, sometimes completing thousands of hours of tests over a single weekend.
After months of virtual training, the ERNEST team was ready to see if the rover could use its new autonomous algorithms to figure out how to drive over terrain features that would halt a passive-suspension rover. They set up an obstacle course with sand ripples, rubble piles, steps, and steep slopes in JPL’s Mars Yard, an outdoor terrain proving ground. Then they watched as the rover maneuvered the terrain on its own. Since then, ERNEST has completed many such courses.
Nayar’s team is starting a new autonomy project which involves integrating the rover’s ability to determine when and how to use its active suspension with longer-range intelligent navigation. The goal is to enable ERNEST to plan an efficient path so that it can tackle surmountable obstacles and circumnavigate hazardous ones. These capabilities could contribute to potential future rover missions encountering formidable landscapes on Mars or more rugged areas of the Moon.
Work on ERNEST began in 2022 was initially supported by JPL internal research and development funds. It is currently funded by NASA’s Mars Exploration Program and the agency’s Exploration Science Strategy and Integration Office in its Science Mission Directorate at NASA Headquarters in Washington. Caltech in Pasadena, California, manages JPL for NASA.
Engineers from NASA’s Jet Propulsion Laboratory are field-testing advanced capabilities for potential future Moon and Mars rovers. In the Colorado Desert nea...

 Login