❌

Normal view

Curiosity Blog, Sols 4927–4933: Let’s Drive to That Smooth Area

24 June 2026 at 05:34

4 min read

Curiosity Blog, Sols 4927–4933: Let’s Drive to That Smooth Area

A black-and-white landscape photograph of the Martian surface taken by the Curiosity rover. The ground features a heavily textured, polygonal cracked pattern, with light-colored material forming raised veins or ridges along many of the cracks. Several dark, flat rock slabs and smaller loose rocks are scattered across the foreground and middle ground. On the right side of the image, the textured tread marks of the rover's wheels are clearly visible pressed into the soil, curving slightly as they trail off into the distance.
NASA’s Mars rover Curiosity acquired this image showing a breathtaking diversity of polygons, veins, and other textural features waiting for investigation by the Mars Science Laboratory team. Curiosity captured the image using its Left Navigation Camera on June 17, 2026 – Sol 4928, or Martian day 4,928 of the Mars Science Laboratory mission – at 17:47:52 UTC.
NASA/JPL-Caltech

By Susanne P. Schwenzer, Professor of Planetary Mineralogy at The Open University, UK

Earth planning date: Thursday, June 18, 2026

In the area Curiosity is currently exploring, the science team has mapped several areas with different-looking surface texture on the orbital images. If you wanted to have a look yourself at what there is to see, check the “Where is Curiosity?” map. You’ll discover different shades of orange and beige as well as more rough and more smooth-looking textures. This is what the geomorphologists in our team use to map the areas for exploration by the rover. Of course, we then supplement this all with ground-based images, including bespoke “drive direction imaging,” which is taken after each drive by the Mast Camera. Drive planning is done using a combination of all this information. So there shouldn’t be any surprises, right?

On Monday the team planned three sols in preparation for a Thursday planning to account for the U.S. federal holiday weekend. The workspace turned out to be a little spiky, so we could not find an area we could DRT. APXS still found one good bedrock target, “Rio Baker,” which also had MAHLI documentation. In addition, ChemCam investigated “Rica Aventura,” a textured bedrock, and “Tabebuia,” a darker-looking individual block, using its LIBS and conducted a passive spectral observation on a second dark float block called “Lago Ranco.” Of course, the team also wanted to look into the distance with ChemCam remote imaging, extending our investigation of the Cordillera base outcrop.

Imaging is always high on the list. In Monday’s plan Mastcam is looking into the modern dunes with the “Tacaza” mosaic, and with more mosaics looking forward to the future parking areas, some of which looked really smooth from that vantage point. We also continue our environmental and atmospheric observations looking for dust devils, the opacity of the atmosphere, and monitoring pressure and temperature. After all this, the rover drove about 35 meters (about 115 feet) to an area that looked really smooth in all images we had available at that point. So we were hoping for a good spot to deploy the DRT, but didn’t think we could be in for a surprise.

The drive ended exactly as planned, spot-on in the middle of that — from a distance — smooth-looking area. But when we opened the post-drive images on Thursday morning, we were all reacting with a lot of surprise. From up close, the parking spot looks anything but smooth. You can see the surprise in the title image of this blog. There are polygons, veins, lamination, and probably more, once we inspect the higher-resolution images taken today. “Higher-resolution” is the key for why we were in for such a surprise! The features are quite small, a few centimeters across, and therefore we could not see them in the orbital images or from a distance in our navigation and mast camera images. The camera resolution from a distance just isn’t enough to see them. But up close, the terrain revealed all its beauty! And I am sure there will be more in the even higher resolution of today’s MAHLI and ChemCam RMI imager images!

So, what did we plan after we caught our breath on Thursday? First, you guessed it, images, images, and more images. Mastcam takes a full panorama with its “left eye” and adds a range of closer-up mosaics with its higher-resolution “right eye.” In addition there is a ChemCam Remote Micro Imager image to document structures further afield at high resolution. ChemCam is investigating three targets using LIBS: “Rio Chimore” is a lighter-toned band; you can see some of those in the cover image of this blog, too. The other two LIBS targets are “Rio de Lava,” a vein target, and “Rio de Salta,” one of the polygons. APXS is also looking at the bedrock and the ridges, at the targets “Pampa Grande” and “Iquique Ridge.” MAHLI is having the above-mentioned close “hand lens” look. Let’s see what we will discover when we get those images.

Finally, Curiosity drove up the hill along very smooth-looking terrain that is just littered with tiny polygons. Let’s see if we are in for another surprise reverberating around all our offices — and across two continents, as I had the good fortune to be among the first ones, here in England (Or maybe it was our French ChemCam colleagues, who are in a time zone one hour ahead of me?). Whichever it is, this terrain has a lot to say about the geologic history of Mars!

A rover sits on the hilly, orange Martian surface beneath a flat grey sky, surrounded by chunks of rock.
NASA’s Curiosity rover at the base of Mount Sharp
NASA/JPL-Caltech/MSSS

Share

Details

Last Updated
Jun 24, 2026

Related Terms

Curiosity Blog, Sols 4927–4933: Let’s Drive to That Smooth Area

24 June 2026 at 05:34

4 min read

Curiosity Blog, Sols 4927–4933: Let’s Drive to That Smooth Area

A black-and-white landscape photograph of the Martian surface taken by the Curiosity rover. The ground features a heavily textured, polygonal cracked pattern, with light-colored material forming raised veins or ridges along many of the cracks. Several dark, flat rock slabs and smaller loose rocks are scattered across the foreground and middle ground. On the right side of the image, the textured tread marks of the rover's wheels are clearly visible pressed into the soil, curving slightly as they trail off into the distance.
NASA’s Mars rover Curiosity acquired this image showing a breathtaking diversity of polygons, veins, and other textural features waiting for investigation by the Mars Science Laboratory team. Curiosity captured the image using its Left Navigation Camera on June 17, 2026 – Sol 4928, or Martian day 4,928 of the Mars Science Laboratory mission – at 17:47:52 UTC.
NASA/JPL-Caltech

By Susanne P. Schwenzer, Professor of Planetary Mineralogy at The Open University, UK

Earth planning date: Thursday, June 18, 2026

In the area Curiosity is currently exploring, the science team has mapped several areas with different-looking surface texture on the orbital images. If you wanted to have a look yourself at what there is to see, check the “Where is Curiosity?” map. You’ll discover different shades of orange and beige as well as more rough and more smooth-looking textures. This is what the geomorphologists in our team use to map the areas for exploration by the rover. Of course, we then supplement this all with ground-based images, including bespoke “drive direction imaging,” which is taken after each drive by the Mast Camera. Drive planning is done using a combination of all this information. So there shouldn’t be any surprises, right?

On Monday the team planned three sols in preparation for a Thursday planning to account for the U.S. federal holiday weekend. The workspace turned out to be a little spiky, so we could not find an area we could DRT. APXS still found one good bedrock target, “Rio Baker,” which also had MAHLI documentation. In addition, ChemCam investigated “Rica Aventura,” a textured bedrock, and “Tabebuia,” a darker-looking individual block, using its LIBS and conducted a passive spectral observation on a second dark float block called “Lago Ranco.” Of course, the team also wanted to look into the distance with ChemCam remote imaging, extending our investigation of the Cordillera base outcrop.

Imaging is always high on the list. In Monday’s plan Mastcam is looking into the modern dunes with the “Tacaza” mosaic, and with more mosaics looking forward to the future parking areas, some of which looked really smooth from that vantage point. We also continue our environmental and atmospheric observations looking for dust devils, the opacity of the atmosphere, and monitoring pressure and temperature. After all this, the rover drove about 35 meters (about 115 feet) to an area that looked really smooth in all images we had available at that point. So we were hoping for a good spot to deploy the DRT, but didn’t think we could be in for a surprise.

The drive ended exactly as planned, spot-on in the middle of that — from a distance — smooth-looking area. But when we opened the post-drive images on Thursday morning, we were all reacting with a lot of surprise. From up close, the parking spot looks anything but smooth. You can see the surprise in the title image of this blog. There are polygons, veins, lamination, and probably more, once we inspect the higher-resolution images taken today. “Higher-resolution” is the key for why we were in for such a surprise! The features are quite small, a few centimeters across, and therefore we could not see them in the orbital images or from a distance in our navigation and mast camera images. The camera resolution from a distance just isn’t enough to see them. But up close, the terrain revealed all its beauty! And I am sure there will be more in the even higher resolution of today’s MAHLI and ChemCam RMI imager images!

So, what did we plan after we caught our breath on Thursday? First, you guessed it, images, images, and more images. Mastcam takes a full panorama with its “left eye” and adds a range of closer-up mosaics with its higher-resolution “right eye.” In addition there is a ChemCam Remote Micro Imager image to document structures further afield at high resolution. ChemCam is investigating three targets using LIBS: “Rio Chimore” is a lighter-toned band; you can see some of those in the cover image of this blog, too. The other two LIBS targets are “Rio de Lava,” a vein target, and “Rio de Salta,” one of the polygons. APXS is also looking at the bedrock and the ridges, at the targets “Pampa Grande” and “Iquique Ridge.” MAHLI is having the above-mentioned close “hand lens” look. Let’s see what we will discover when we get those images.

Finally, Curiosity drove up the hill along very smooth-looking terrain that is just littered with tiny polygons. Let’s see if we are in for another surprise reverberating around all our offices — and across two continents, as I had the good fortune to be among the first ones, here in England (Or maybe it was our French ChemCam colleagues, who are in a time zone one hour ahead of me?). Whichever it is, this terrain has a lot to say about the geologic history of Mars!

A rover sits on the hilly, orange Martian surface beneath a flat grey sky, surrounded by chunks of rock.
NASA’s Curiosity rover at the base of Mount Sharp
NASA/JPL-Caltech/MSSS

Share

Details

Last Updated
Jun 24, 2026

Related Terms

The post Curiosity Blog, Sols 4927–4933: Let’s Drive to That Smooth Area appeared first on NASA Science.

Curiosity Blog, Sols 4920-4926: Surveying the Bands

19 June 2026 at 01:50

3 min read

Curiosity Blog, Sols 4920-4926: Surveying the Bands

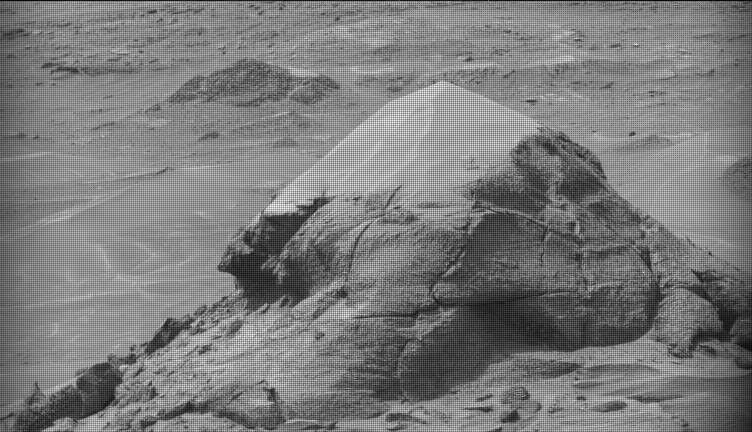
A black-and-white image of a barren Martian landscape featuring a prominent, roughly pyramidal rock outcropping in the foreground. The rock's lower half is rugged with deep cracks and textured layers, while its peak appears lighter and smoother, possibly covered in dust. The surrounding terrain stretches into the background with scattered smaller rocks and another low mound in the distance.
NASA’s Mars rover Curiosity acquired this image of small butte, “Miraflores,” using its Mast Camera (Mastcam) on June 11, 2026 — Sol 4922, or Martian day 4,922 of the Mars Science Laboratory mission — at 09:12:13 UTC.
NASA/JPL-Caltech/MSSS

Written by William Farrand, Senior Research Scientist, Space Science Institute

Earth planning date: Friday, June 12, 2026

Rather than going from stage to stage at a music festival to hear different bands playing different varieties of music, Curiosity has been ascending up Mount Sharp through physical bands of exposed rocks with textural and tonal differences.

Planning for sols 4920 and 4921 were done with the rover in the middle of a unit with a rougher texture and dark-toned bedrock. With the rougher-textured bedrock, brushing wasn’t possible, but APXS chemistry and MAHLI micro-imaging were planned on “as is” bedrock targets “Salto La Cascada” and “Puerto de Rosas.” ChemCam was targeted to perform LIBS spectroscopy on a bedrock target “Kishuara” and a small, layered float rock “La Rosita.” ChemCam’s Remote Micro-Imager (RMI) collected views of the “Mishe Mokwa” butte and another looking at dunes with tonal differences. Mastcam mosaics were collected on the “Valle Grande” channel, “Kimsa Chata” butte, nearby troughs, and the aircraft carrier shaped rock “El Matir.”

Another drive brought Curiosity closer to the upper border of the dark-toned band. Again, brushing of the rocks was not possible, but APXS and MAHLI were collected on dark-toned bedrock targets “Santa Gracia” and “Laguna San Rafael” with ChemCam LIBS also targeting the bedrock. Mastcam mosaics were collected of a layered rock and nearby troughs and a mosaic of the nearby smaller butte, “Miraflores” which displays an interesting layered structure with ragged dark-toned rocks on one side and a stack of dust piled on top (see accompanying image). Other activities included a long-distance RMI mosaic of a bright unit on “Mishe Mokwa”, and Navcam dust-devil surveys in both sols.

Communicating between Earth and Mars has come to seem routine, but at times can still be a challenging endeavor and this was demonstrated to the team on Friday when we did not get a timely downlink of data for the drive planned for Sol 4923. Without these images another drive, in situ examinations, or targeted remote sensing could not be planned. However, there are always interesting things to be done on Mars and the three-sol plan (4924 to 4926) included a 360-degree Mastcam mosaic, the automatic AEGIS targeting of LIBS measurements on each sol, a Navcam dust-devil survey, APXS atmospheric measurements, as well as several other environmental activities.

On Monday, the delayed downlink will be used to plan the first investigation of the next band of surface materials, this one being smooth-textured and light-toned, as well as another drive to continue the surveying of the bands.

A rover sits on the hilly, orange Martian surface beneath a flat grey sky, surrounded by chunks of rock.
NASA’s Curiosity rover at the base of Mount Sharp
NASA/JPL-Caltech/MSSS

Share

Details

Last Updated
Jun 18, 2026

Related Terms

The post Curiosity Blog, Sols 4920-4926: Surveying the Bands appeared first on NASA Science.

Curiosity Blog, Sols 4920-4926: Surveying the Bands

19 June 2026 at 01:50

3 min read

Curiosity Blog, Sols 4920-4926: Surveying the Bands

A black-and-white image of a barren Martian landscape featuring a prominent, roughly pyramidal rock outcropping in the foreground. The rock's lower half is rugged with deep cracks and textured layers, while its peak appears lighter and smoother, possibly covered in dust. The surrounding terrain stretches into the background with scattered smaller rocks and another low mound in the distance.
NASA’s Mars rover Curiosity acquired this image of small butte, “Miraflores,” using its Mast Camera (Mastcam) on June 11, 2026 — Sol 4922, or Martian day 4,922 of the Mars Science Laboratory mission — at 09:12:13 UTC.
NASA/JPL-Caltech/MSSS

Written by William Farrand, Senior Research Scientist, Space Science Institute

Earth planning date: Friday, June 12, 2026

Rather than going from stage to stage at a music festival to hear different bands playing different varieties of music, Curiosity has been ascending up Mount Sharp through physical bands of exposed rocks with textural and tonal differences.

Planning for sols 4920 and 4921 were done with the rover in the middle of a unit with a rougher texture and dark-toned bedrock. With the rougher-textured bedrock, brushing wasn’t possible, but APXS chemistry and MAHLI micro-imaging were planned on “as is” bedrock targets “Salto La Cascada” and “Puerto de Rosas.” ChemCam was targeted to perform LIBS spectroscopy on a bedrock target “Kishuara” and a small, layered float rock “La Rosita.” ChemCam’s Remote Micro-Imager (RMI) collected views of the “Mishe Mokwa” butte and another looking at dunes with tonal differences. Mastcam mosaics were collected on the “Valle Grande” channel, “Kimsa Chata” butte, nearby troughs, and the aircraft carrier shaped rock “El Matir.”

Another drive brought Curiosity closer to the upper border of the dark-toned band. Again, brushing of the rocks was not possible, but APXS and MAHLI were collected on dark-toned bedrock targets “Santa Gracia” and “Laguna San Rafael” with ChemCam LIBS also targeting the bedrock. Mastcam mosaics were collected of a layered rock and nearby troughs and a mosaic of the nearby smaller butte, “Miraflores” which displays an interesting layered structure with ragged dark-toned rocks on one side and a stack of dust piled on top (see accompanying image). Other activities included a long-distance RMI mosaic of a bright unit on “Mishe Mokwa”, and Navcam dust-devil surveys in both sols.

Communicating between Earth and Mars has come to seem routine, but at times can still be a challenging endeavor and this was demonstrated to the team on Friday when we did not get a timely downlink of data for the drive planned for Sol 4923. Without these images another drive, in situ examinations, or targeted remote sensing could not be planned. However, there are always interesting things to be done on Mars and the three-sol plan (4924 to 4926) included a 360-degree Mastcam mosaic, the automatic AEGIS targeting of LIBS measurements on each sol, a Navcam dust-devil survey, APXS atmospheric measurements, as well as several other environmental activities.

On Monday, the delayed downlink will be used to plan the first investigation of the next band of surface materials, this one being smooth-textured and light-toned, as well as another drive to continue the surveying of the bands.

A rover sits on the hilly, orange Martian surface beneath a flat grey sky, surrounded by chunks of rock.
NASA’s Curiosity rover at the base of Mount Sharp
NASA/JPL-Caltech/MSSS

Share

Details

Last Updated
Jun 18, 2026

Related Terms

NASA’s X-59 Reaches Speed, Altitude for Future Quiet Supersonic Flights

12 June 2026 at 20:35
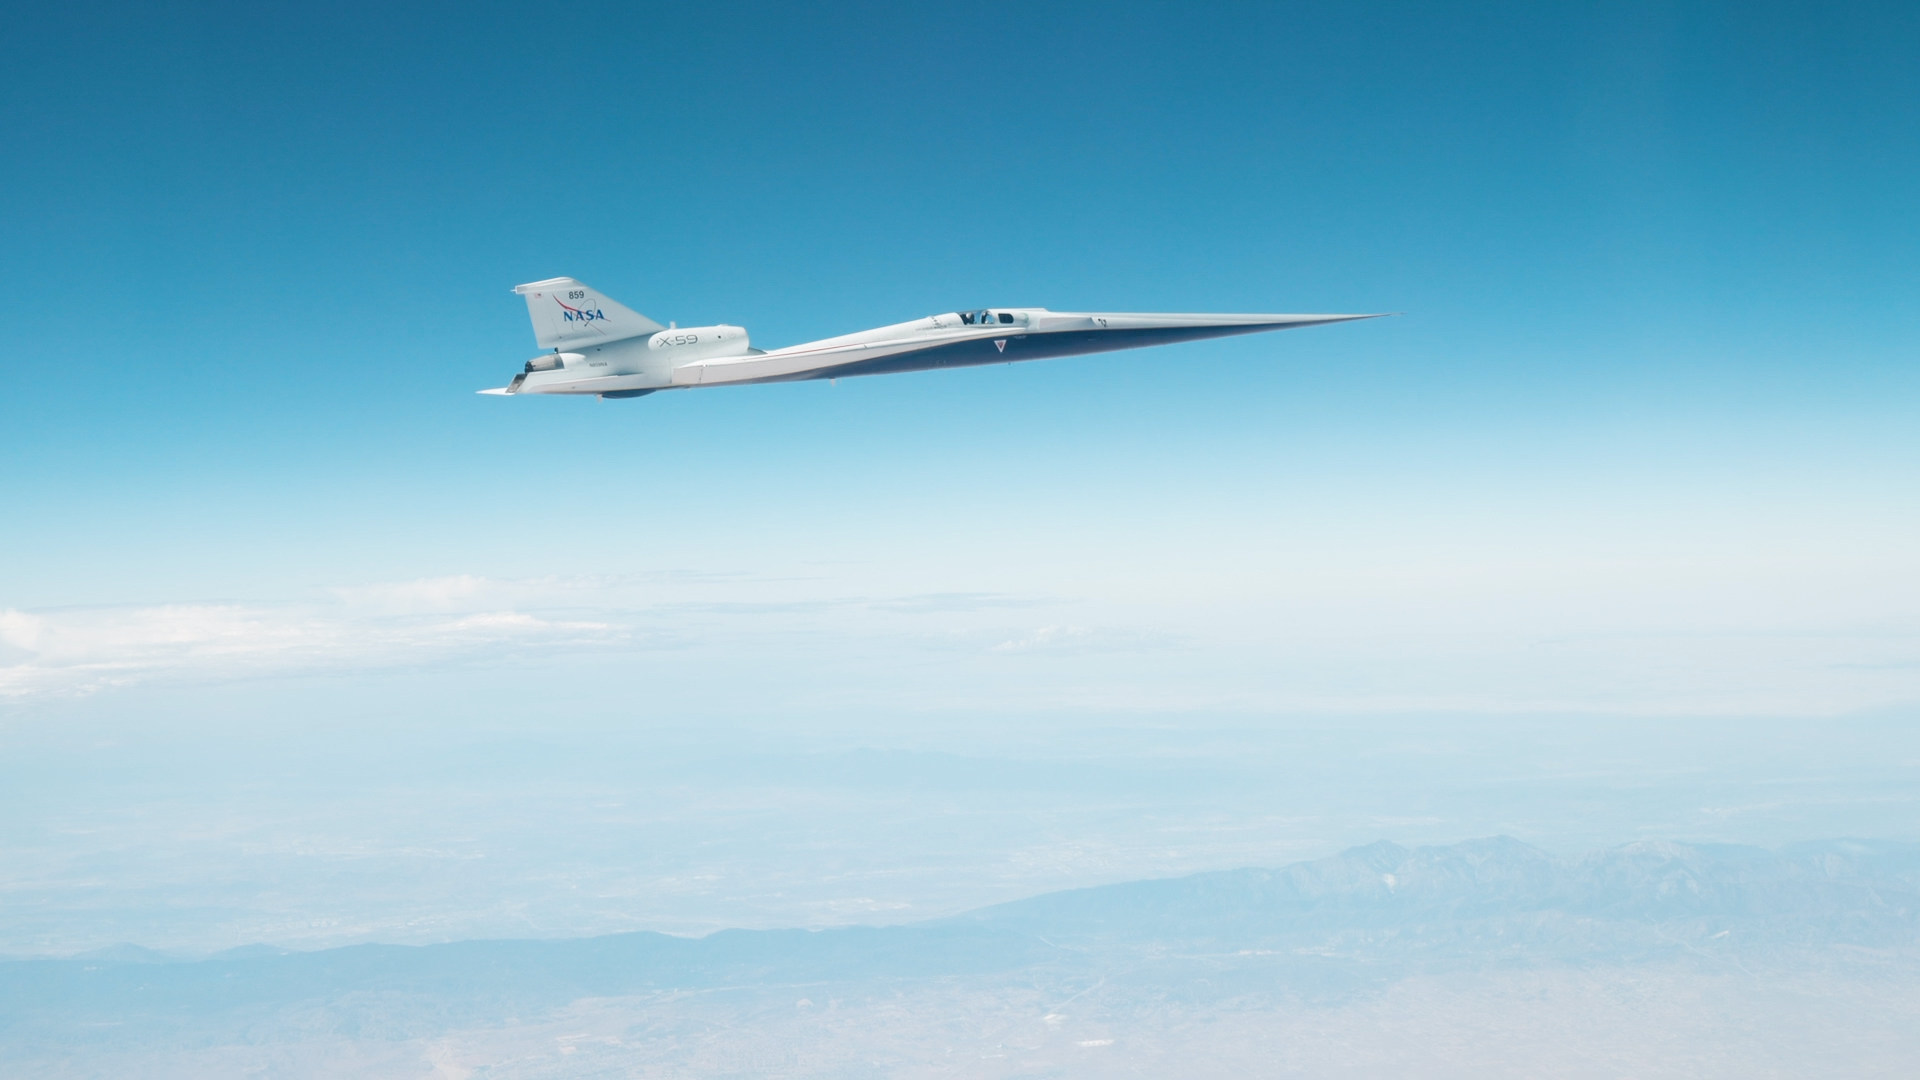
The X-59 in flight on June 12, 2026 against a blue sky.
NASA’s X-59 quiet supersonic research aircraft reached its target speed and altitude for future community overflights for the first time during a flight on Friday, June 12, 2026. The milestone marked the first time the aircraft flew at Mach 1.4 and 55,000 feet — conditions it will fly when gathering community response data to its quiet sonic thump.
NASA/Lori Losey

NASA’s X-59 experimental aircraft reached a major milestone Friday, June 12, flying Mach 1.4 (about 924 mph) and an altitude of 55,000 feet, the conditions required for the aircraft to make future flights critical to its mission.  

The X-59 still has months of performance testing ahead, but after those are complete, NASA’s Quesst mission will fly the aircraft over several U.S. communities to collect data on public perception of the quiet sonic thump it will make at supersonic speeds. Those community overflights will include flights at Mach 1.4 and 55,000 feet. 

The milestone comes just days after the X-59’s first supersonic flight. That flight showed the aircraft performed as expected at Mach 1.1, but Friday’s mission conditions flight was an even more critical step for NASA. 

The aircraft’s team has steadily expanded the aircraft’s flight envelope by evaluating its performance at a variety of speeds and altitudes, and having its pilots take on a battery of maneuvers.  

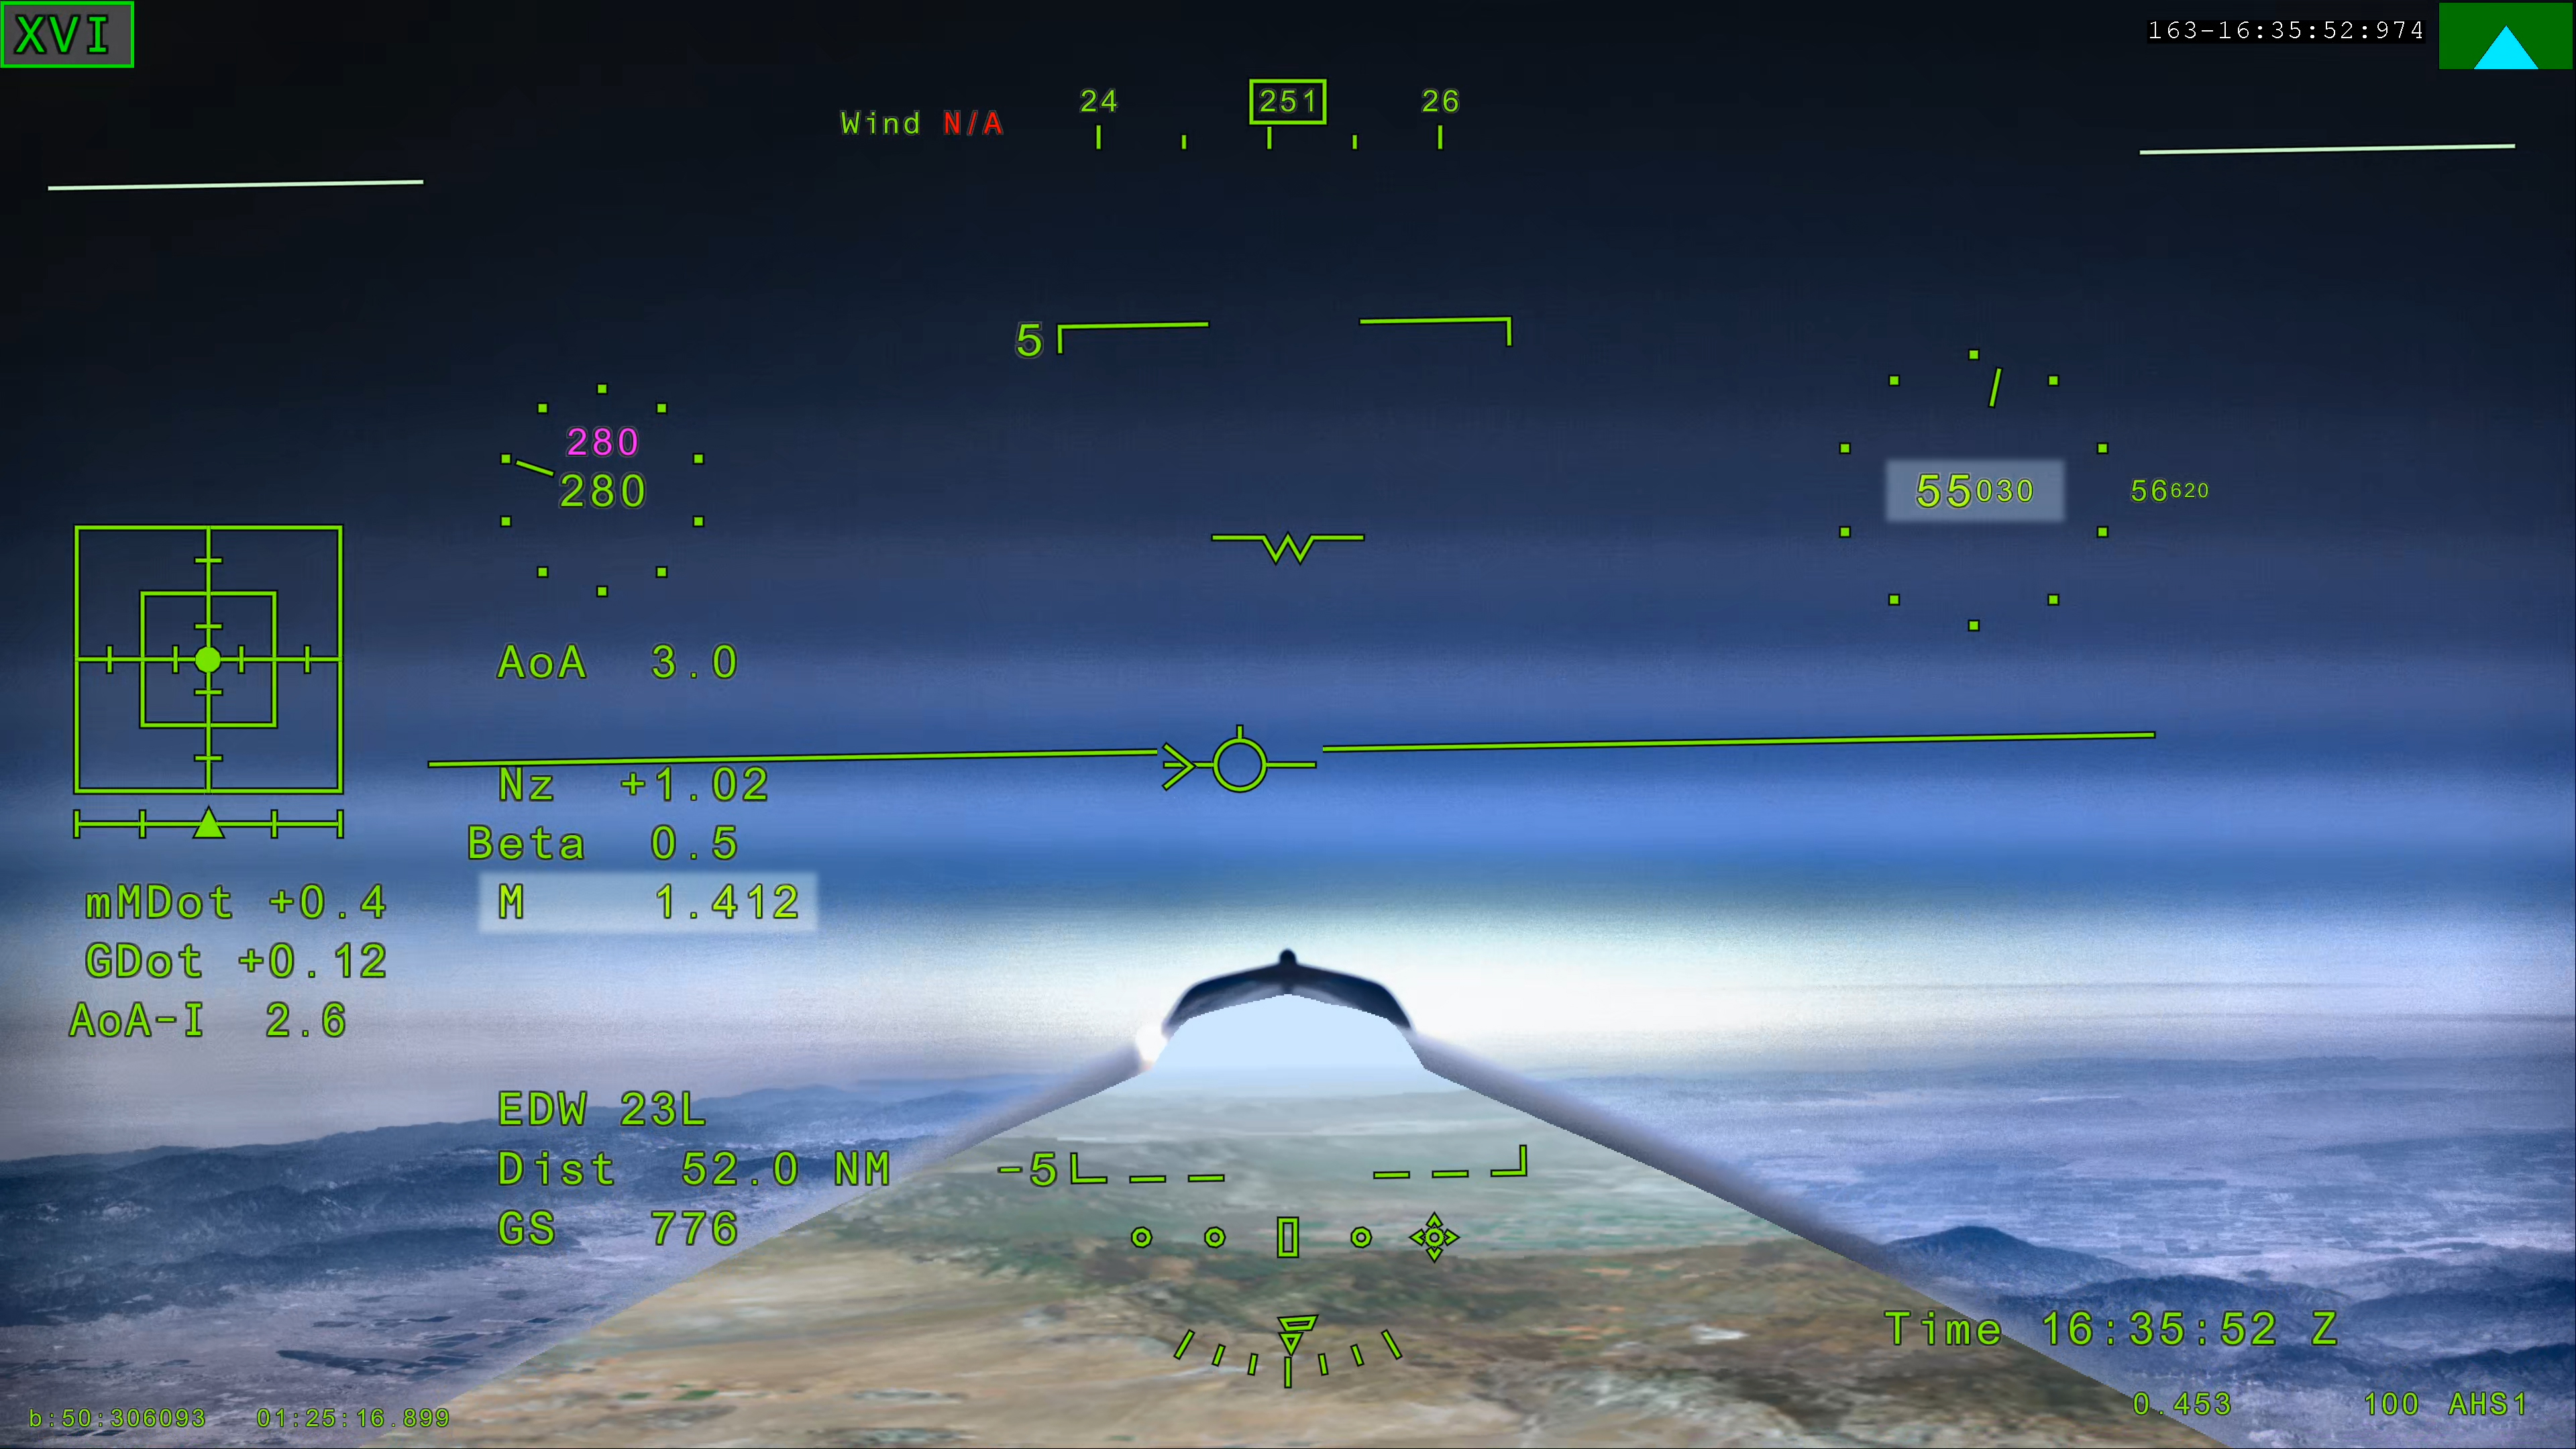
Photo of the XVS screen on the X-59 showing Mach 1.4 at 55,030 was achieved.
NASA’s X‑59 eXternal Vision System (XVS) shows Mach 1.4 at 55,030 feet on Friday, June 12, 2026 during the aircraft’s first mission conditions flight, the approximate conditions it will fly when gathering community response data to its quiet “sonic thump.” The milestone marks the first time the aircraft flew at its designed speed and altitude.
NASA/Lori Losey

The X-59 was designed to fly supersonic without causing a loud sonic boom. However, for these early supersonic flights it has been accompanied by a NASA F-15 research aircraft, a traditional supersonic jet that causes booms obscuring any noise the X-59 makes. During upcoming flights, a shock-sensing probe mounted to the F-15 will gather measurements of the X-59’s shock wave signature, an early measure of its supersonic performance. 

After the team conducts more tests at a variety of altitudes and conditions to complete envelope expansion, the X-59 will enter the acoustic validation phase of Quesst. During this phase, researchers will thoroughly measure the aircraft’s supersonic acoustic signature — the quiet thump it’s designed to make — to confirm it is performing as intended. 

Each flight brings NASA one step closer to flying the X-59 over communities and gathering feedback that could help shape the future of commercial supersonic flight over land. 

More X-59 to Explore

quesst-logo-horizontal-051826sm

Read more on the Quesst mission page.

The post NASA’s X-59 Reaches Speed, Altitude for Future Quiet Supersonic Flights appeared first on NASA Science.

Curiosity Blog: Sols 4913-4919: Planetary explorers, freewheeling to the Yardang unit!

10 June 2026 at 22:23

3 min read

Curiosity Blog: Sols 4913-4919: Planetary explorers, freewheeling to the Yardang unit!

Black-and-white Mars rover image showing a rocky, flat terrain in the foreground with jagged hills and layered buttes in the distance under a hazy sky.
Navcam image from sol 4916 showing the rough drive direction. The yardang unit can be seen as a series of pale coloured hills in the centre of the image, at the very back.
NASA/JPL-Caltech

Written by Catherine O’Connell-Cooper, APXS Strategic Planner and Payload Uplink/Downlink Lead, University of New Brunswick, Canada

Earth planning day: Friday, June 5th, 2026

In a very broad sense, Curiosity has two modes of doing science – one centred around a defined science campaign (such as the recent boxwork campaign) and the other as we move between campaigns. During a science campaign, with a very defined start and end location, every image and every workspace is carefully choregraphed to make sure we hit all of our science goals for the campaign. This is a lot of pressure!

But in between campaigns, the emphasis moves to driving towards the next major campaign. Our next major stop is the yardang unit, a series of intriguing wind sculpted, pale coloured hills which you can just see in the distance in the cover image for this blog. The rover planners (RPs) sometimes make our drives as long as they can and we drive as far as we can go, other times we stop a little short to look at interesting looking workspaces as we go. As part of the APXS team, I loved being part of the boxwork campaign and getting all the information we needed there …  but as a geologist, there is something very special about this kind of exploring, the sense of being a planetary explorer, ambling along to see what the rocks will show us.

So we continue southwards, trundling over laminated bedrock which varies from predominantly pale coloured laminated bedrock to bands with abundant thin flaky, darker coloured, layers and patches. Some of the rocks stick out at strange angles, which make planning drives more challenging. This past week there has been abundant dark layers interbedded with the more dominant pale coloured rock, both in place and in fragments around the workspace. APXS and MAHLI characterized some of this darker material, for example at “Rio Bio Bio” and “Placilla de Caracoles” and some of the paler material at the brushed targets “La Primavera” and “Los Quemados.” ChemCam also analyzed both types of rocks along the way.

We are busily acquiring Mastcam and ChemCam LD-RMI (“Long Distance Remote Micro Imager”) images of everything even remotely interesting – and there are lots and lots of cool features around here. The wide open landscape here allows us to image features from several different angles and distances, such as “Mira Flores,” a small erosional outlier seen from a distance in this image and closer up here. Another great example is the “Kimsa Chata” trough which shows some amazing sedimentary structures, which may help us to determine if this was a desert or a lake or maybe something in between, such as a desert with some water moving through.

The Environmental Theme Group continues to populate each plan with environmental monitoring activities. Activities varied from dust devil monitoring in Gale crater to looking at levels of dust in the skies overhead. The weekend drive is planned to take us further into that drive distance shown in the cover image, to an area where the contrast between dark and light bedrock is more pronounced, and just beyond that, to an area which looks very smooth, with no jutting out blocks. From where we sit today, its impossible to say what it is but that is the fun of exploring – who knows what we will find? Stay tuned to find out over the coming weeks. 

A rover sits on the hilly, orange Martian surface beneath a flat grey sky, surrounded by chunks of rock.
NASA’s Curiosity rover at the base of Mount Sharp
NASA/JPL-Caltech/MSSS

Share

Details

Last Updated
Jun 10, 2026

Related Terms

Curiosity Blog: Sols 4913-4919: Planetary explorers, freewheeling to the Yardang unit!

10 June 2026 at 22:23

3 min read

Curiosity Blog: Sols 4913-4919: Planetary explorers, freewheeling to the Yardang unit!

Black-and-white Mars rover image showing a rocky, flat terrain in the foreground with jagged hills and layered buttes in the distance under a hazy sky.
Navcam image from sol 4916 showing the rough drive direction. The yardang unit can be seen as a series of pale coloured hills in the centre of the image, at the very back.
NASA/JPL-Caltech

Written by Catherine O’Connell-Cooper, APXS Strategic Planner and Payload Uplink/Downlink Lead, University of New Brunswick, Canada

Earth planning day: Friday, June 5th, 2026

In a very broad sense, Curiosity has two modes of doing science – one centred around a defined science campaign (such as the recent boxwork campaign) and the other as we move between campaigns. During a science campaign, with a very defined start and end location, every image and every workspace is carefully choregraphed to make sure we hit all of our science goals for the campaign. This is a lot of pressure!

But in between campaigns, the emphasis moves to driving towards the next major campaign. Our next major stop is the yardang unit, a series of intriguing wind sculpted, pale coloured hills which you can just see in the distance in the cover image for this blog. The rover planners (RPs) sometimes make our drives as long as they can and we drive as far as we can go, other times we stop a little short to look at interesting looking workspaces as we go. As part of the APXS team, I loved being part of the boxwork campaign and getting all the information we needed there …  but as a geologist, there is something very special about this kind of exploring, the sense of being a planetary explorer, ambling along to see what the rocks will show us.

So we continue southwards, trundling over laminated bedrock which varies from predominantly pale coloured laminated bedrock to bands with abundant thin flaky, darker coloured, layers and patches. Some of the rocks stick out at strange angles, which make planning drives more challenging. This past week there has been abundant dark layers interbedded with the more dominant pale coloured rock, both in place and in fragments around the workspace. APXS and MAHLI characterized some of this darker material, for example at “Rio Bio Bio” and “Placilla de Caracoles” and some of the paler material at the brushed targets “La Primavera” and “Los Quemados.” ChemCam also analyzed both types of rocks along the way.

We are busily acquiring Mastcam and ChemCam LD-RMI (“Long Distance Remote Micro Imager”) images of everything even remotely interesting – and there are lots and lots of cool features around here. The wide open landscape here allows us to image features from several different angles and distances, such as “Mira Flores,” a small erosional outlier seen from a distance in this image and closer up here. Another great example is the “Kimsa Chata” trough which shows some amazing sedimentary structures, which may help us to determine if this was a desert or a lake or maybe something in between, such as a desert with some water moving through.

The Environmental Theme Group continues to populate each plan with environmental monitoring activities. Activities varied from dust devil monitoring in Gale crater to looking at levels of dust in the skies overhead. The weekend drive is planned to take us further into that drive distance shown in the cover image, to an area where the contrast between dark and light bedrock is more pronounced, and just beyond that, to an area which looks very smooth, with no jutting out blocks. From where we sit today, its impossible to say what it is but that is the fun of exploring – who knows what we will find? Stay tuned to find out over the coming weeks. 

A rover sits on the hilly, orange Martian surface beneath a flat grey sky, surrounded by chunks of rock.
NASA’s Curiosity rover at the base of Mount Sharp
NASA/JPL-Caltech/MSSS

Share

Details

Last Updated
Jun 10, 2026

Related Terms

The post Curiosity Blog: Sols 4913-4919: Planetary explorers, freewheeling to the Yardang unit! appeared first on NASA Science.

❌