"Apple co-founder Steve Wozniak's Woz Ed foundation is partnering with Realbotix, best known for their RealDoll-branded artificial companions, to deploy AI-powered robotic tutors in classrooms," writes Slashdot reader Hentes. "The doll will serve as a sort of artificial teaching assistant, helping students who get stuck or generating lessons. Students will be assigned an ID code, allowing the robot to provide personalized mentoring." NYS Focus reports: "This deployment in a working school district represents a landmark moment for both AI and humanoid robotics," said Andrew Kiguel, CEO of Realbotix, which is currently building the robot. "[Salamanca City Central School District in Western New York] marks the beginning of a new era where humanoid robots and intelligent AI assistants become standard tools in STEM education."
The female robot, named Sally, will have a "lifelike appearance" with silicone skin and long brown hair, Kiguel said in an interview with New York Focus. It will be stationary in a seated position but have a wide range of upper-body movements and facial expressions. [...]
Salamanca plans to introduce the robot and avatar in its high school AI and robotics courses, which use curriculum developed by Apple co-founder Steve Wozniak to prepare students for high-demand tech jobs. The district plans to expand it to high school students in other classes if the pilot is successful. Realbotix's classroom robot has drawn scrutiny because the company is connected to RealDoll, the longtime maker of hyperrealistic sex dolls and sex robots. Realbotix acquired RealDoll's parent company in 2024 but says the education-focused operation has separate employees, payroll, facilities, and technology, with plans to formally separate the businesses at the ownership level.
The "companion robots" are different from sex robots and intended to address what it's described as a "loneliness epidemic." Kiguel has previously said the company's goal is to produce robots and AI that are "indistinguishable from humans."
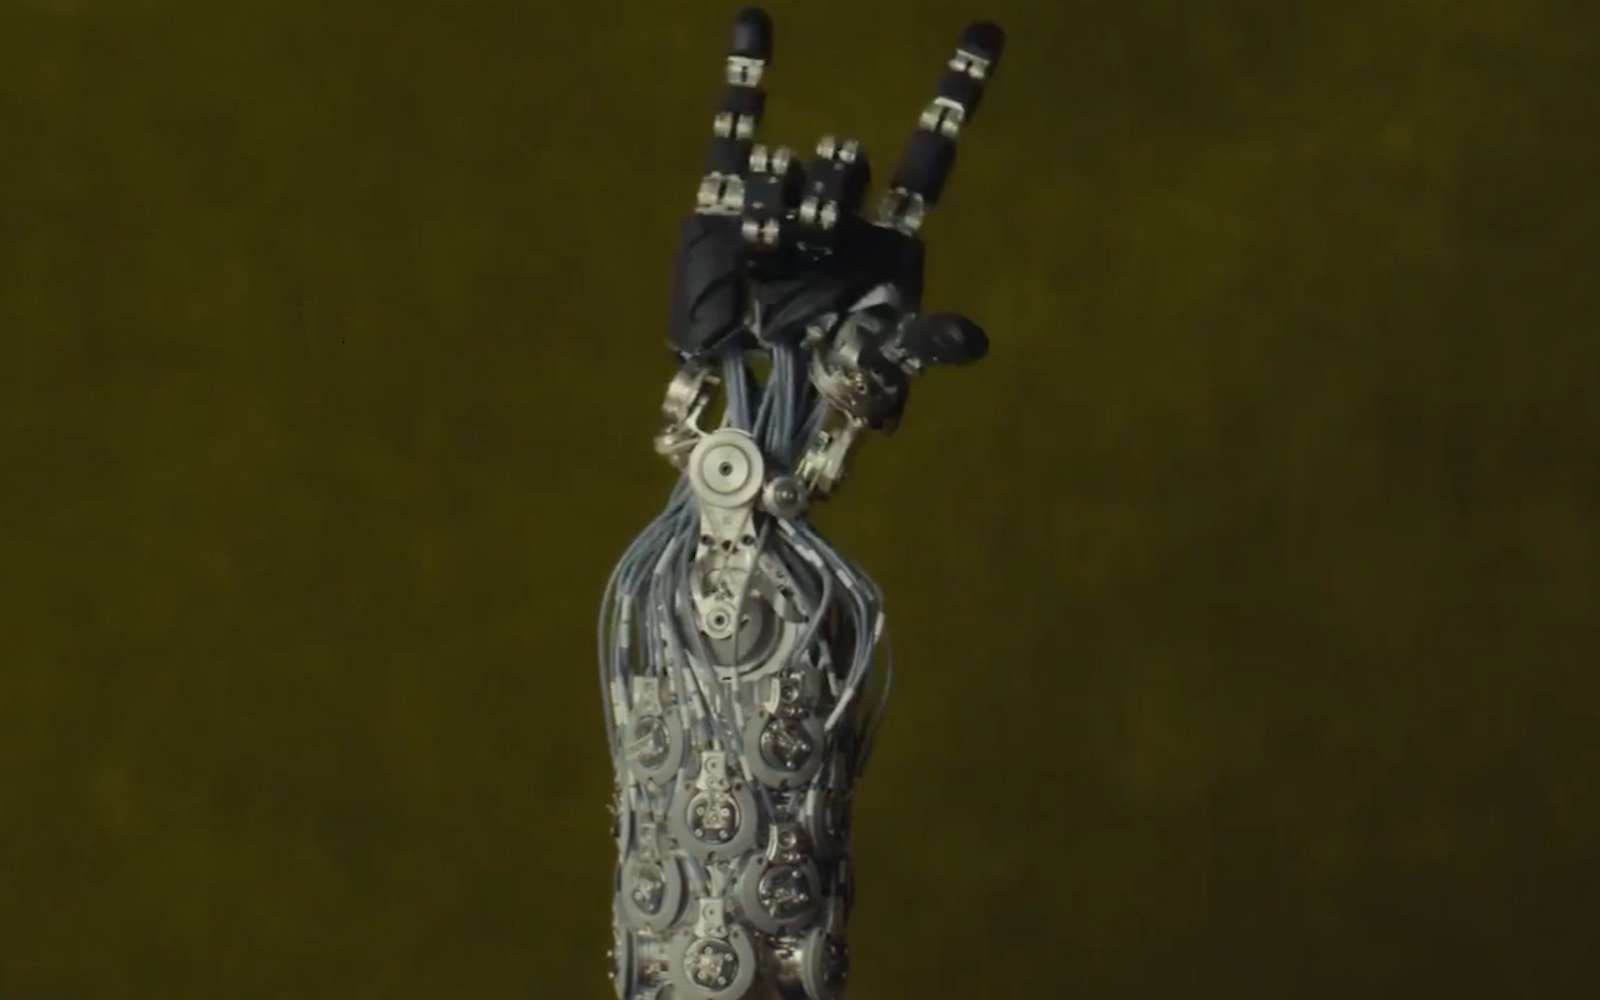
Le robot Neo de la société 1X revient avec une promesse déroutante : des mains presque humaines, capables de bouger à une vitesse troublante et de manipuler notre environnement avec une précision inédite. Est-ce trop beau pour être vrai ?
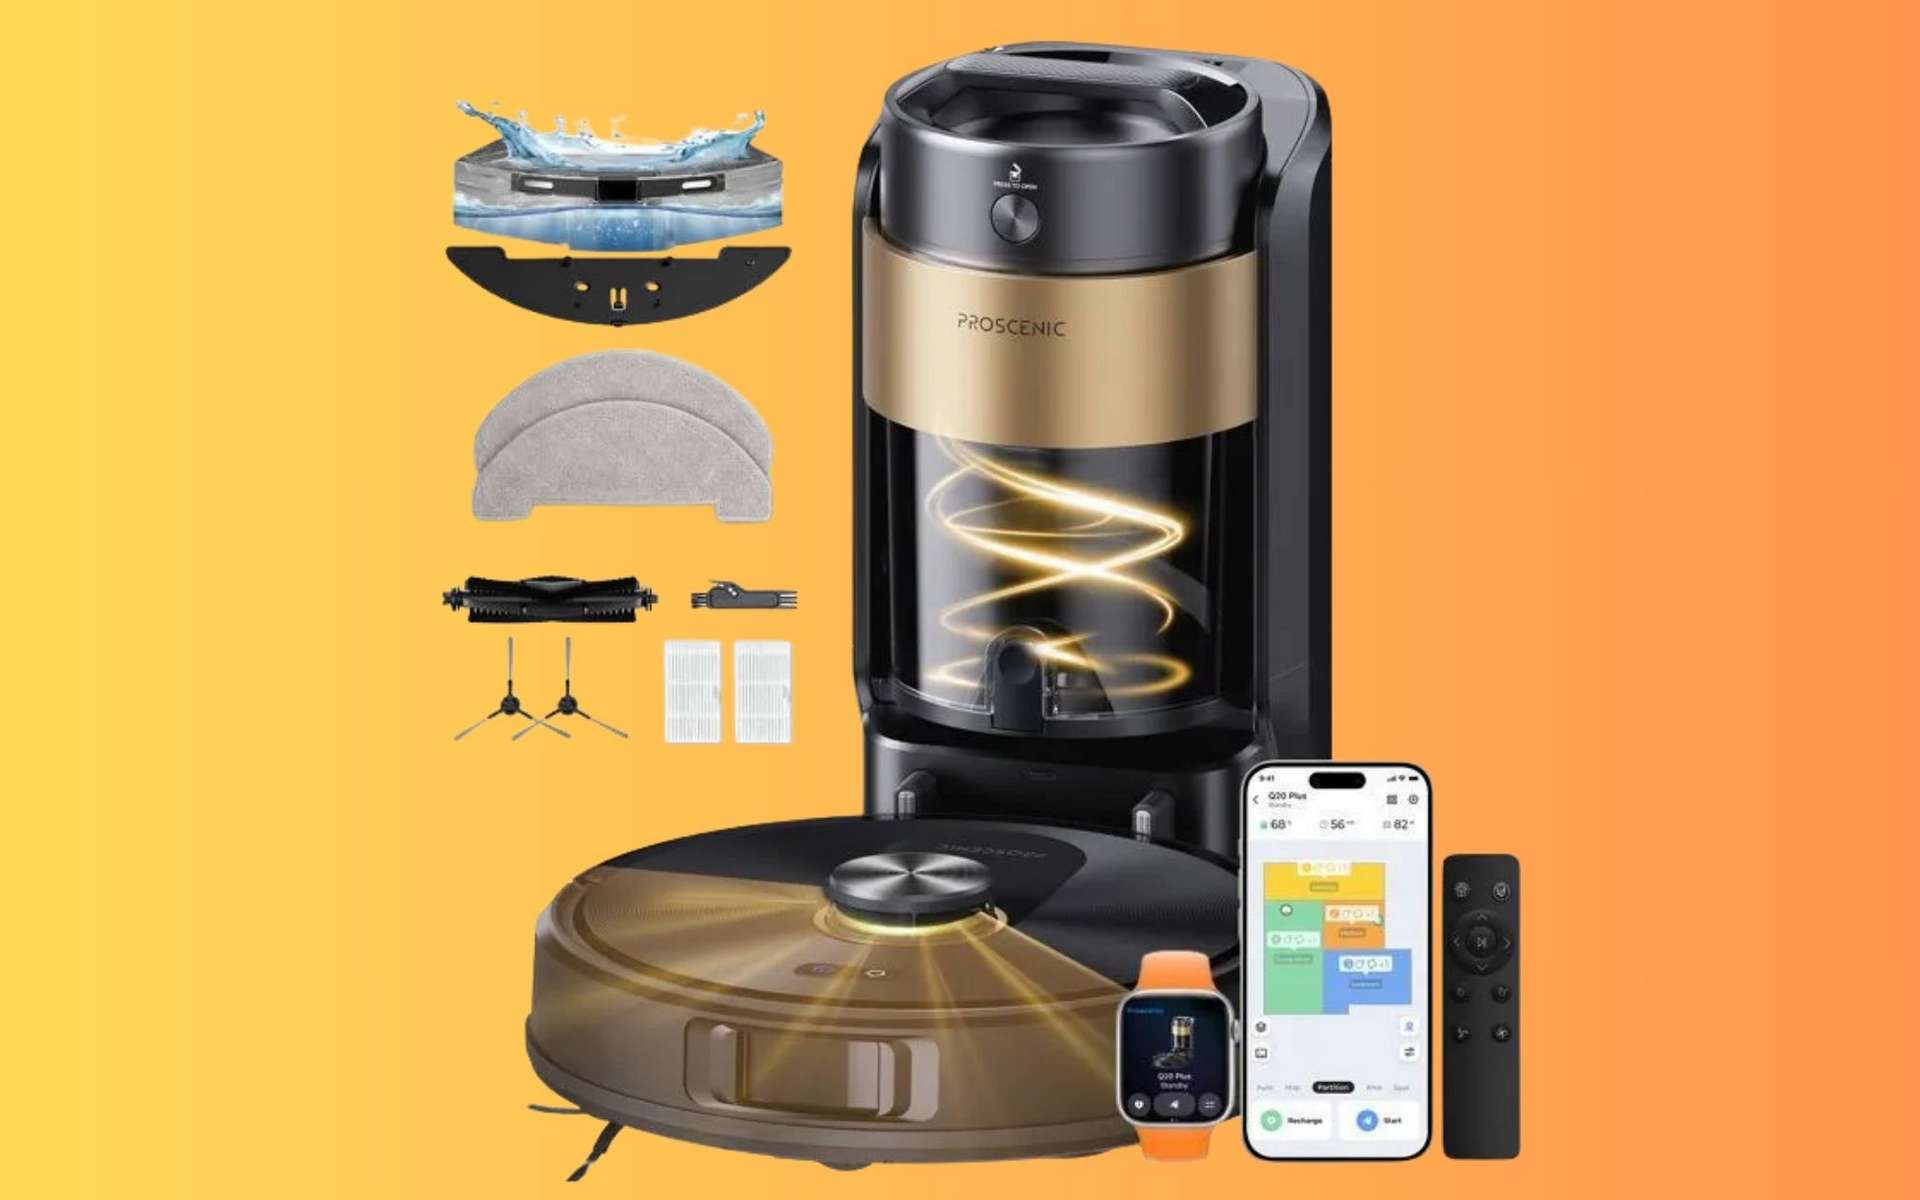
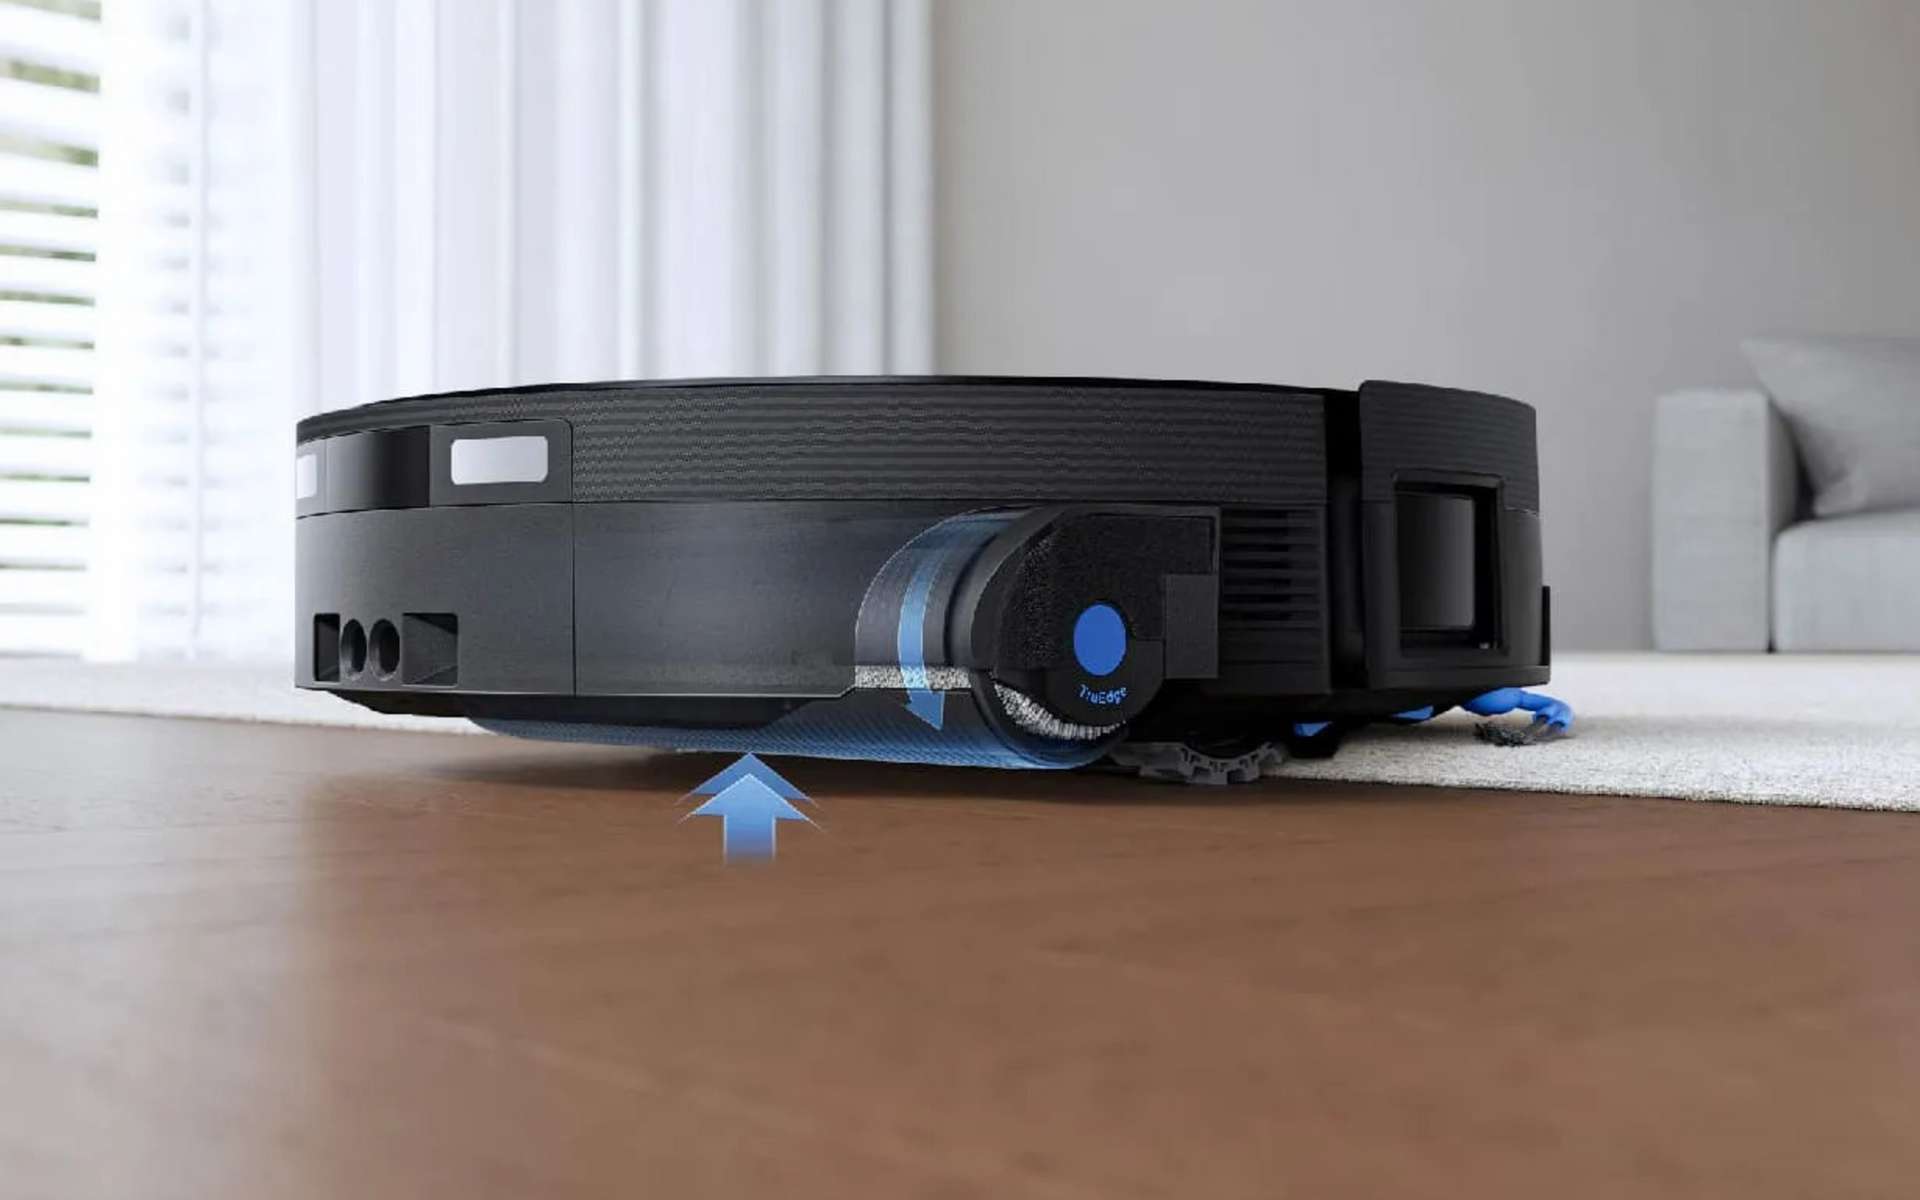
Les soldes battent leur plein chez Cdiscount, avec de nombreux bons plans à la clé. Parmi eux, le robot aspirateur laveur Proscenic Q20 Plus profite d'une offre intéressante pour automatiser le nettoyage de vos sols et alléger votre quotidien.
Engineers have developed a new robot that can swim underwater, then rise to the surface and take flight, in an aerial-aquatic feat that mimics some of nature’s most formidable fliers and swimmers.
Developed by researchers at the Massachusetts Institute of Technology (MIT) and the Swiss Federal Institute of Technology Lausanne (EPFL), the new robot’s capabilities could help launch a new generation of aerial-aquatic exploration vehicles.
Dubbed the “Flapping-Wing Aerial-Aquatic Vehicle” (FAAV), this lightweight robotic platform weighs less than 300 grams and can transition seamlessly between water and air with its very flexible flapping wings. Now, the team’s findings, published in the journal Science, could help scientists better understand how diving birds, which include puffins, petrels, loons, and gulls, are so adept at navigating two vastly different environments.
Such capabilities, the team says, could also pave the way toward advanced drones in the coming years that could transform ocean research.
Inspired by Diving Birds
Departing from conventional modern designs employed for aircraft or underwater vehicles, the team based their design on diving birds, which evolved to fly over water, then plunge beneath the waves to hunt for food, before surfacing and resuming flight.
MIT’s new aerial aquatic robot seen launching from water into the air (Image Credit: Raphael Zufferey/MIT)
One problem when it comes to replicating these abilities in robots involves the density of water, which is around 1,000 times denser than air. Because of this, the engineering team had to carefully balance the flexibility of the robotic wings in their design, along with flapping frequency, tail angle, and other factors that allowed the robot to move efficiently through both environments without requiring propellers or separate propulsion systems.
Finding the Sweet Spot for Transmedium Travel
Experiments were undertaken by the team in the lab and in Switzerland’s Lake Geneva, and helped the team determine that the robot achieved best performance with medium-sized wings that flap at approximately five times per second. Under such conditions, the robot was able to swim one meter per second, then by pitching upward at a 70-degree angle, it could break through the surface, and continue this same movement to propel itself through the air.
Although the robot still has some limitations compared to the avian examples that inspired it, interestingly, it does appear to have one advantage: unlike diving birds, which paddle using their feet to achieve aquatic launches into the air, the new robot has no such requirement, and can transition from water to air relying only on its wings and adjustable tail.
Future Drones with “Aerial-Aquatic” Abilities
In the future, drones equipped with such capabilities could be leveraged to monitor marine ecosystems in a variety of ways. The team also says it could help to observe environmental concerns, such as water near glaciers or offshore infrastructure, or even collect data from hazardous locations that are either too difficult or simply too costly for ships to reach.
“Our dream vision is for oceanographers, marine biologists, and members of coastal communities to launch this robot from a boat, or from shore, and it would fly close to the area of interest, such as an iceberg or a port facility, or over a pod of whales,” according to Raphael Zufferey, assistant professor of mechanical engineering at MIT.
“It would dive into the water to take a measurement or collect a sample, and fly back to deliver the data at a fraction of the cost of traditional methods. Then it could go back out to dive for more,” Zufferey recently told MIT News.
Drawing from movements in nature influenced by evolution, the researchers hope their bird-inspired design may eventually help scientists by introducing cost-effective, but formidable new tools to help obtain information from some of the most challenging environments, all with help from robots that can do what only nature’s diving birds could once achieve.
The achievement is detailed in a new paper, “Leaping out of the water: aerial-aquatic locomotion with flapping wings,” which appeared in the journal Science.
Micah Hanks is the Editor-in-Chief and Co-Founder of The Debrief. A longtime reporter on science, defense, and technology with a focus on space and astronomy, he can be reached atmicah@thedebrief.org. Follow him on X @MicahHanks, and at micahhanks.com.
This effect, known as structural color, is the same reason butterfly wings look iridescent without pigment. Pressure causes microscopic structures within the material to shift, altering how light reflects and creating a real-time visual indicator of force.
Touch Without the Computation
Most vision-based tactile sensors can map contact and force in detail, but only at the cost of heavy computation that slows them down. Simpler systems are faster, but sacrifice detail. The new material developed by Sasso’s team sidesteps this problem by building the sensing function into the material itself. With just a standard USB camera, researchers can track color changes on the surface and immediately infer pressure, strain, and contact shape without complex data reconstruction.
“You won’t guess how much information is generated when your finger presses a light switch. A human hand contains more than 10,000 mechanoreceptors to do the job, yet touch sensing remains one of the major challenges in robotics,” Sasso said. “We were happy to capture the finger ridges, as no existing technology can reproduce such sensor density at [a] comparable scale and simplicity. The key idea behind this project was to think outside the box: instead of embedding dense and overengineered sensor arrays, sensing is moved into the material itself, where mechanical cues are directly transformed into colour fields and captured using a simple low-cost USB camera.”
Professor James Busfield, one of the paper’s co-authors, described the advantage more simply: “What is particularly powerful is that the information is already in the light signal. You are no longer reconstructing touch – you are observing it directly.”
From Precision Manufacturing to the Operating Room
Reducing the computational demands of touch sensing opens up new possibilities. A robotic gripper made with this material could handle tiny parts more gently, since changes in force are immediately detectable. Prosthetic limbs equipped with similar sensors could also provide users with more detailed tactile feedback.
The researchers also see potential applications in surgery, where detecting subtle pressure differences could help clinicians interpret tissue properties.
A Decade of Groundwork Behind One Material
Professor Federico Carpi from the University of Florence and Professor James Busfield from Queen Mary worked together on this project, merging years of separate work on stretchable sensors and polymer behavior into one material system. This allowed the team to use a mechanochromic material as the sensor itself, not just as a base for electronics.
Many approaches to robotic touch have relied on increasingly complex sensor arrays, wiring, and computing systems. Rather than adding more electronics, Sasso’s team’s approach allows the material itself to encode touch into visible color. It remains unclear whether this color-based method can be scaled for use in commercial robotic hands, but this work suggests that the future of robotic touch might rely as much on smart materials as on advanced electronics.
Austin Burgess is a writer and researcher with a background in sales, marketing, and data analytics. He holds an MBA, a Bachelor of Science in Business Administration, and a data analytics certification. His work focuses on breaking scientific developments, with an emphasis on emerging biology, cognitive neuroscience, and archaeological discoveries.
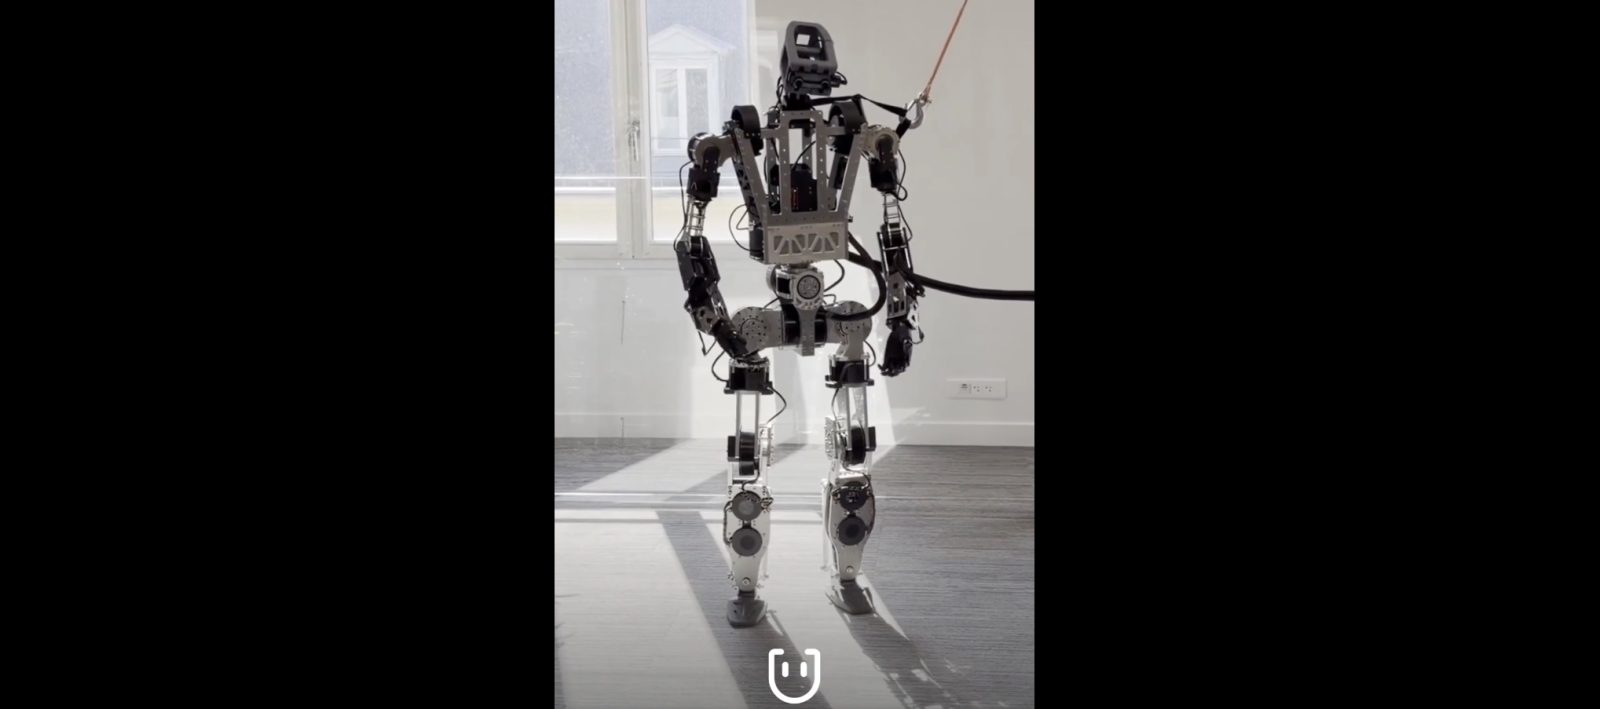
A scientist who worked on Tesla’s Optimus humanoid robot is now building a rival of his own — in Europe, not Silicon Valley.
Rémi Cadène, co-founder and CEO of Paris-based startup UMA, unveiled plans for a lightweight humanoid robot called Northstar and says the company is already talking to 50 potential customers.
A Nvidia continua a apostar no ecossistema de robótica e apresentou o primeiro sistema de segurança que prepara o ambiente para os robots agirem em ambientes dinâmicos, ao lado de trabalhadores humanos.
An anonymous reader quotes a report from Ars Technica: Dozens of new robot arms have been installed at General Motors' flagship electric vehicle factory in Detroit -- even as 1,300 workers remain out of work following what was supposed to be a temporary layoff. The latest automation push has spurred union pushback over a potentially existential issue for automakers and their workers. General Motors installed approximately 50 robot arms at GM's Factory Zero plant in Detroit, Michigan, according to reporting by Crain's Detroit Business. Made by the Japanese robotics company FANUC, the robots are designed to help attach various components to vehicles during the assembly line process. But leaders at United Auto Workers (UAW), the primary US union for autoworkers, reacted with anger to the new robotic presence, given how GM has not yet called back any of the workers affected by supposedly temporary layoffs in March.
More than 1,000 union members are still "laid off indefinitely," James Cotton, president of UAW Local 22, told The Detroit News. He said that the company could bring some of those members back to work instead of installing the 50 robots. The temporary layoffs were preceded by permanent layoffs involving another 1,200 workers at GM's Factory Zero in October 2025. Many automakers, including Stellantis NV and Ford Motor Company, have deployed assembly-line robots, such as Fanuc robot arms, as they push to automate more of their US operations. Hyundai Motor Company plans to deploy Atlas humanoid robots made by Boston Dynamics -- which Hyundai acquired in 2020 -- to start working in the automaker's flagship EV facility in Georgia by 2028. "Technological development has the capability of making work safer for the working class and enabling workers to have a shorter work week without losing pay," said Andrew Bergman, a Local 22 member and union organizer who was among those laid off by GM. "But in the bosses' and billionaires' hands it's used to pad profits and lay off workers."
The elephant’s trunk is one of the animal world’s most formidable facial appendages; it is capable of tearing a tree limb from its base and, moments later, carefully lifting a single blade of grass.
A boneless appendage that can both move heavy logs and peel fruit like a banana, the elephant’s trunk has long been studied by engineers seeking to understand how it can perform both powerful and delicate tasks effectively. Now, in a new study published in PNAS Nexus, researchers have identified the skin, rather than the underlying muscle, as a key factor in the versatility of this pachyderm appendage.
Lucia Beccai and colleagues at the Istituto Italiano di Tecnologia studied the trunk of an adult Asian elephant that died of natural causes at Zurich Zoo in 2020. They collected 35 samples from different regions of the trunk and analyzed them using biomechanical testing, histology, various imaging techniques, and computational modeling. The team’s analysis revealed a trunk that combines two very different mechanical strategies within a single structure.
One Trunk, Two Skins
The elephant trunk acts as a muscular hydrostat, similar to an octopus tentacle or the human tongue. With no bones and over 100,000 muscles, the trunk can stretch, compress, twist, and bend in any direction. The trunk achieves this flexibility through a combination of muscle power and specialized skin architecture. The study found that the trunk’s outer surface varies in structure depending on location and the types of forces it encounters.
The researchers identified clear differences between the upper and lower surfaces of the trunk, reflecting what scientists call functional anisotropy. The trunk’s upper surface serves as a tough, protective layer, which is over three times stiffer than the underside. In contrast, the trunk’s lower surface remains soft and flexible, allowing the elephant to grip objects with delicacy and precision.
The way elephants use their trunks reflects this structural difference. The upper surface faces the environment and absorbs impacts and abrasions. The underside is used for gripping objects. Its lower stiffness allows it to adapt to the shape of objects and hold them securely. The design of the elephant trunk may offer a solution to a persistent challenge that has stumped soft-robotics engineers in balancing protection and precision by assigning each function to a different layer of skin.
A Lens Made of Tissue
Another significant finding was made beneath the gripping surface. The researchers identified dome-shaped structures known as dermal papillae. Finite element modeling suggested that these structures act as subsurface mechanical lenses, concentrating mechanical stress in regions where sensory nerves are located.
This design could solve an additional problem in robotics: touch sensors are often fragile and require protective coatings that can reduce their sensitivity. The tissue in the elephant trunk appears to protect sensory structures while still allowing mechanical signals to reach them.
The Biomimetic Blueprint
For Beccai’s group, which specializes in soft robotics, the possible design template represents a huge opportunity for their field. A robotic gripping device built on this idea would feature a stiff outer shell over a flexible inner layer, with structures underneath to direct pressure to protected sensors. This setup would keep sensitive electronics shielded while still allowing for mechanical feedback from touch.
This research adds to the growing scientific interest in the elephant trunk as a model for engineering. Another 2024 study in Communications Biology found that the trunk’s dermis is reinforced by tangled collagen fibers, creating skin armor thicker than an armadillo’s shell. Together, these studies show a structure optimized at every level, from the protein fibers in the dermis to the clear split between the upper and lower surfaces.
Today’s robotic hands still struggle to balance durability with sensitivity. The elephant trunk offers biological inspiration for this challenge, providing a model for future engineering designs.
Austin Burgess is a writer and researcher with a background in sales, marketing, and data analytics. He holds an MBA, a Bachelor of Science in Business Administration, and a data analytics certification. His work focuses on breaking scientific developments, with an emphasis on emerging biology, cognitive neuroscience, and archaeological discoveries.
Hyundai Motor Group is acquiring SoftBank's remaining 9.65% stake in Boston Dynamics for $325 million, "closing out SoftBank's last piece of Boston Dynamics and turning the Waltham, Massachusetts robotics company into a wholly owned Hyundai business," reports Startup Fortune. From the report: The price is $325 million for the remaining stake, according to the deal terms, and it follows the put option SoftBank retained when Hyundai bought control of Boston Dynamics in 2021. You should read that as a signal, not a footnote. Hyundai paid about $880 million for an 80% stake in Boston Dynamics in the 2021 transaction, valuing the company at roughly $1.1 billion at the time. SoftBank had bought Boston Dynamics from Alphabet in 2017, after Google had acquired the robotics lab in 2013. It was a strange ownership path for a company whose robots became famous on YouTube long before they became obvious commercial products.
That part is changing. At CES in Las Vegas on January 5, 2026, Hyundai and Boston Dynamics showed the electric Atlas humanoid robot in public, with the Associated Press reporting that the life-sized robot stood up, walked around the stage and was remotely piloted for the demonstration. The useful detail was not the stagecraft. It was the deployment plan. A production version of Atlas is expected to begin work at Hyundai's electric vehicle plant near Savannah, Georgia, by 2028. [...] If Hyundai can turn that into repeatable manufacturing value, the SoftBank exit will look less like a tidy cleanup and more like the moment Hyundai stopped borrowing a robotics future and decided to own it outright.
Ils servent déjà des cocktails, courent des marathons ou plient le linge, mais les robots humanoïdes sont encore loin de pouvoir multiplier les tâches différentes sur demande, malgré les promesses et le marketing. Le décalage était frappant, dans les allées du salon Robotics Summit à Boston, fin mai 2026, entre d'un côté, les brochures publicitaires, et de l'autre, le discours des professionnels.
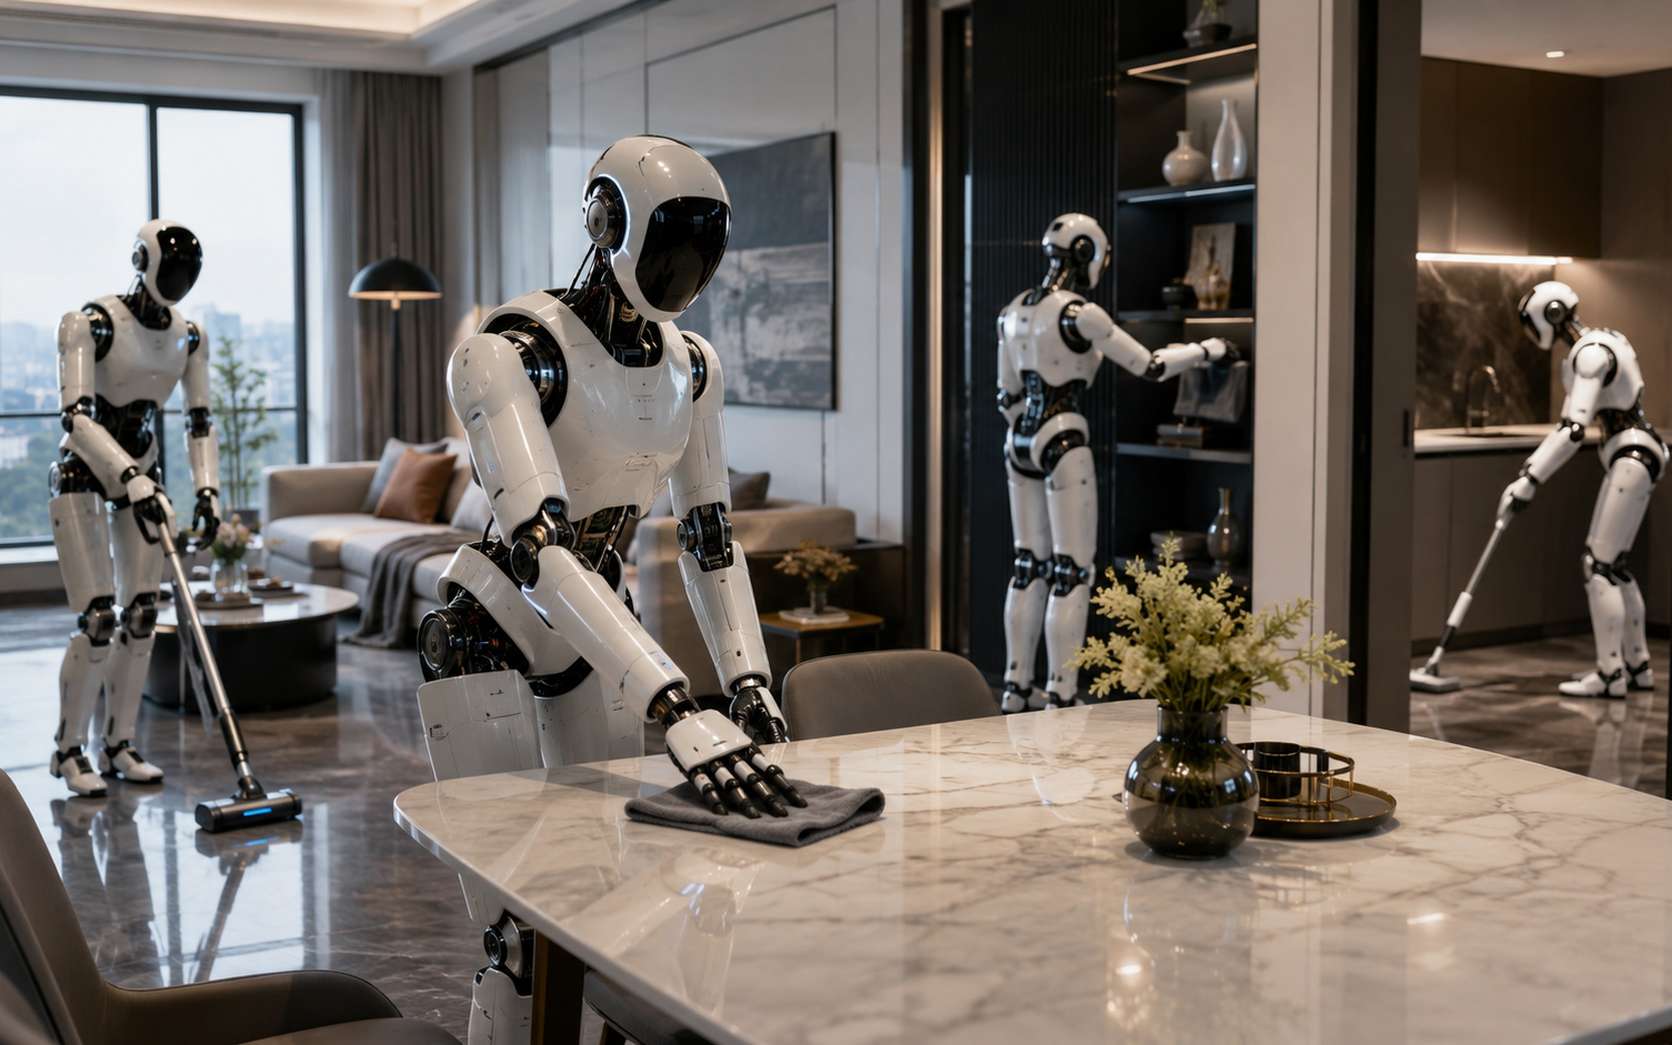
À Pékin et à Shenzhen, des robots humanoïdes dopés à l’intelligence artificielle sont testés dans des logements privés. Encore lents, maladroits et accompagnés par des humains, ces assistants mécaniques servent autant à nettoyer qu’à collecter les données indispensables à la prochaine génération...
The next humanoid robot might not have a head. It might not have legs. It might even sit on a wheeled base and fold down like a deck chair. But, as Genesis AI puts it, "humanoid robots don't need to look human."
That explains the look of Eno, the new robot from the French startup backed by former Google CEO Eric Schmidt. Genesis says Eno is designed "around human capability" rather than human appearance and is intended as a fully "general-purpose" robot rather than a machine built around a single task, like folding laundry. One part is still very human though: its hands, which the company says are designed to "exactly match the form and fu …
Les soldes n'ont pas encore commencé que les prix prennent déjà la poussière. Ecovacs dégaine de fortes remises sur trois robots aspirateurs laveurs de sa gamme, du très ambitieux X12 Omnicyclone au polyvalent T50 Omni Gen2. De quoi automatiser le ménage sans attendre le coup d'envoi officiel...
Depuis des décennies, l'industrie robotique repose sur un postulat tacite : pour évoluer dans un monde conçu par et pour les humains, un robot devrait leur ressembler. Argus, une machine développée par l'université Duke, vient remettre ce dogme en question avec des arguments plutôt solides.
À Pékin et Shenzhen, un service de ménage associant humains et robots équipés d'intelligence artificielle est testé chez des particuliers. Au-delà de l'assistance au quotidien, ces expérimentations servent surtout à collecter des données pour entraîner les futurs robots domestiques.
Miettes, poussières, traces de pas... les sols durs n'accordent aucun répit. Aspirateurs balais ou laveurs, nous avons sélectionné les modèles les plus convaincants pour retrouver un intérieur propre sans transformer chaque séance de ménage en épreuve de fond.
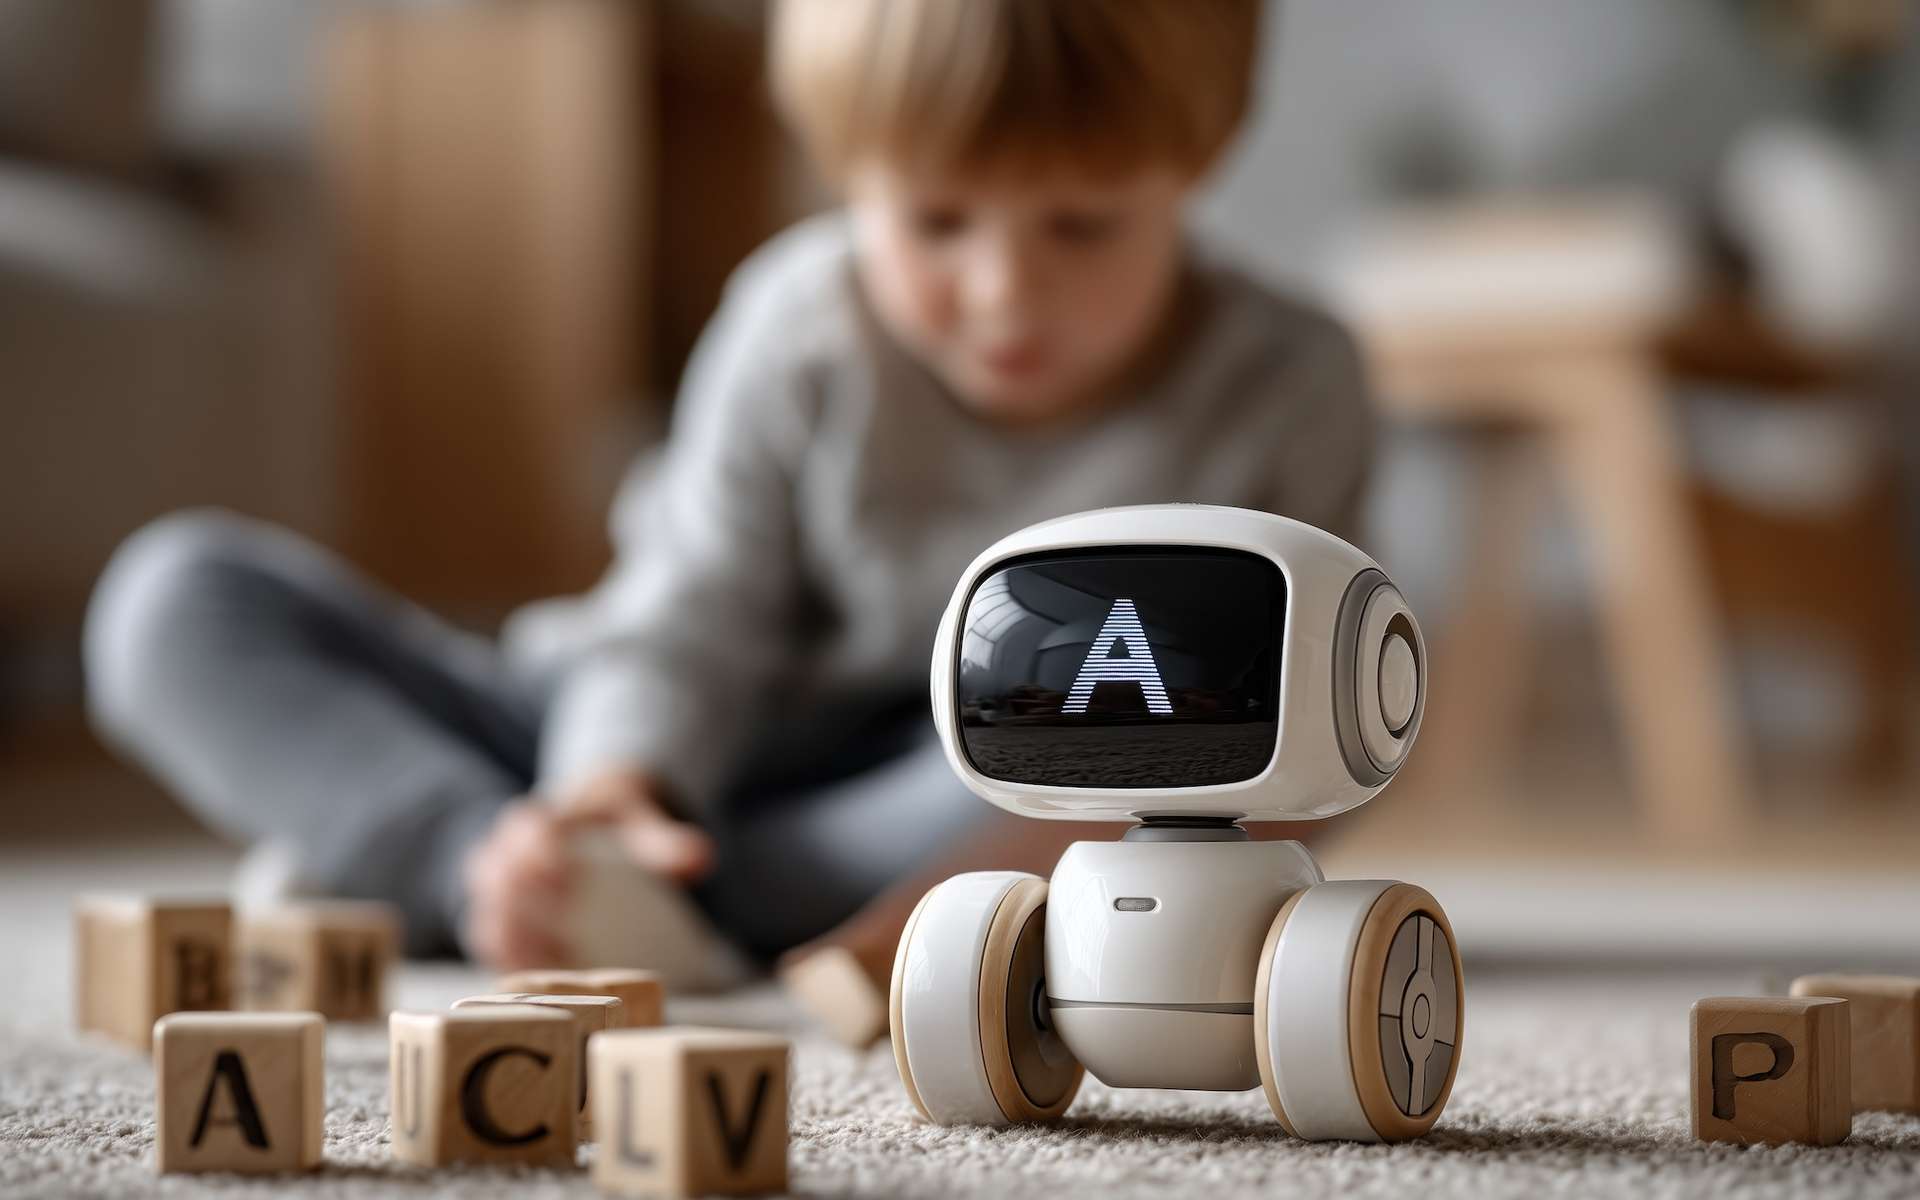
Ils racontent des histoires, répondent aux questions et semblent devenir les meilleurs amis des enfants. Mais derrière les promesses éducatives des jouets dopés à l'intelligence artificielle, des experts alertent sur des risques encore largement méconnus pour leur développement, leur vie privée...
Os cães-robot podem ser a próxima aposta das forças armadas em Taiwan para reforçar a vigilância e a defesa do território, juntando-se aos esforços de modernização militar face às crescentes tensões com Pequim.

 Login