❌

Reading view

NASA’s Curiosity Uncovers New Clues to Mars’ Potential of Supporting Ancient Life


NASA’s Curiosity rover and its mission to investigate whether Mars could have ever supported microbial life have taken one step closer to achieving its goal, with one of the most significant discoveries in the ongoing search for evidence of life on the Red Planet.

While exploring Gale Crater, NASA’s robotic rover uncovered a sample in 2020 and, using a chemical technique, determined that 21 carbon-based molecules were preserved in the clay-rich sedimentary rock. This also included seven that had never been identified on Mars before. 

While the discovery does not definitively point to life on the Red Planet, it does strengthen the case that Mars has the chemical conditions to support life. 

According to scientists, the most remarkable aspect of the discovery is not the molecules themselves, but their preservation

“The actual organic components they found are not strong evidence for life,” said Texas A&M University astrobiologist and geobiologist Dr. Michael Tice in a statement. Tice acknowledged that these compounds may also have evolved through abiotic processes, including formation in meteorites or other non-biological pathways.

“These organics were likely preserved in the rocks for a very long time, possibly billions of years, despite radiation and other harsh conditions on Mars,” Tice said.

“It blows my mind.”

Building Blocks of Life

Organic molecules are critical building blocks of life, but they can also form through non-biological processes, such as geological reactions or meteorite delivery. Similar preserved compounds on Earth help scientists study ancient environments, and their discovery on Mars provides new clues about the planet’s billion-year-old history.

“Studying how those compounds vary between different rocks can tell a story of how life and environments changed,” Tice recently said in a statement issued by Texas A&M. “Finding organics stored in similar ways on Mars tells us that there could be similar stories preserved there as well.”

The findings also suggest that Martian rocks may contain evidence from a time before life began, a record of sorts that Earth’s past geology has mostly erased.

“It is even possible that some Mars rocks will tell us about times when there was no life there,” he said, with organics formed instead through prebiotic chemistry or delivered from space. “We do not have an equivalent record of such a time preserved on Earth.”

The findings build on earlier research by Tice and his team that identified possible biosignatures in Mars rocks studied by NASA’s Perseverance rover. 

Tice suggests, “When we looked even closer, we saw things that are easy to explain with early Martian life but very difficult to explain with only geological processes.”

The rocks contained organic carbon and key elements connected to microbial energy sources, along with chemical patterns that may show redox reactions (processes often associated with life on Earth).

“With the right collection, we could find the next step in evidence for past life on Mars or learn about the kinds of processes that eventually led to life on our planet.”

Tice and his colleagues will continue their work exploring the Martian land. 

“I’m continuing to study the record of early Martian evolution as part of the PIXL instrument team on the Perseverance rover,” he said.

“In addition, I’m comparing how organisms affected some of the oldest sediments on Earth — now preserved in rocks in South Africa—with the potential biosignatures we discovered on Mars.”

Additional details about Tice and his team’s work can be found in a pair of papers, “Diverse organic molecules on Mars revealed by the first SAM TMAH experiment,” which appeared in Nature Communications, and “Redox-driven mineral and organic associations in Jezero Crater, Mars,” which was published in the journal Nature.

Chrissy Newton is a PR professional and founder of VOCAB Communications. She hosts the Rebelliously Curious podcast, which can be found on The Debrief’s YouTube Channel. Follow her on X: @ChrissyNewton and at chrissynewton.com.

  •  

Transformers on the Moon? Japan Reveals Details of Tiny Shape-Shifting Rover’s Historic Lunar Exploration


Over two years after Japan’s Smart Lander for Investigating Moon (SLIM) mission deployed a tiny, shape-shifting rover on the Moon, the country’s space agency JAXA has finally revealed previously unreleased details about the first-of-its-kind autonomous robotic lunar exploration.

According to a statement announcing the recently published mission account, the SLIM team deployed the rover on the Moon’s surface, “after which the rover transformed from a tiny sphere into a wheeled robot that took images of the lander and its environment.” A second rover transmitted the data back to Earth, with all steps occurring autonomously.

The team behind the historic mission said their success could pave the way for swarms of small, transformable robots capable of exploring high-scientific value areas that larger spacecraft and robots cannot reach, including caves, tunnels, lava tubes, vents, and deep extraterrestrial craters.

The Benefits of Tiny Robots and Autonomous Shape-Shifting Rovers

In the published study, the JAXA team explains that robotic technologies like SLIM “are expected to drive substantial advancements in planetary exploration and resource prospecting” by performing tasks in extraterrestrial environments that are inaccessible to other platforms, including human astronauts. For example, the team noted that miniature robots offer tremendous weight savings over bulkier platforms, especially when added to missions with “strict payload limitations.”

“Miniature robots have the potential to reduce payloads and to reach cramped spaces such as small vents and craters that are inaccessible to larger, conventional robots,” they explain.

Still, the SLIM team notes that building tiny, shape-shifting rovers capable of exploring a variety of complex environments presents its own set of challenges. The most limiting constraints involve computational power and battery capacity. The team also observed that smaller robotics platforms inherently suffer from “reduced locomotion performance” due to their small size.

Now, when revealing the details of the SLIM mission, the researchers note that advancements in miniaturization and computational performance spurred by the Internet of Things “have catalyzed the emergence of smaller, lighter, and more intelligent rovers at lower costs.”

Introducing the ‘Hopping’ Lev-1 and the ‘Transforming’ Lev-2

To build a tiny, shapeshifting robot capable of exploring the lunar surface autonomously, team leader Daichi Hirano and colleagues designed the Lunar Excursion Vehicle (LEV) system, which comprises LEV-1 and LEV-2. According to the team’s statement, LEV-1 can communicate directly with mission planners back on Earth. For locomotion, the robot moves via what the team termed “a controlled hopping mechanism.”

The second robot, LEV-2, starts out as a compact sphere 8 inches in diameter. However, once on the Moon, the mission controllers said that the tiny robot can transform into a “two-wheeled rover with cameras and a tail stabilizer.”

“Here, we introduce a two-wheeled centimeter-scale rover, designated Lunar Excursion Vehicle 2 (LEV-2), also known as SORA-Q (named after the Japanese words for space and sphere), which transforms into a wheeled configuration from a compact spherical form, enabling efficient traversal of soft lunar terrains,” they write.

Transformers Make Autonomous Robotic Exploration History

According to the new mission details, the SLIM lander deployed LEV-2 “immediately before its landing on the lunar surface.” In the mission details, the team explained that upon deployment, the rover autonomously extended its wheels, tail stabilizer, and cameras, “thereby enhancing its mobility and stability on soft lunar terrain.”

tiny robot shape-shifting rover autonomous
Overview of the motion sequence on the lunar surface. (A) Deployment of LEV-1 and LEV-2 from the SLIM lander prior to landing on the lunar surface. (B) Data transmission from LEV-2 through LEV-1 to the Earth. (C) Mode transition and motion sequence on the lunar surface. Image Credit: D. Hirano.

After deployment, LEV-2 navigated the lunar surface in the immediate area around the lander. According to the published study, “the palm-sized rover accomplished autonomous lunar exploration by navigating around the SLIM lander, capturing images of both the SLIM lander and its environment.” Critically, the rover’s exploration was autonomous and “without reliance on ground-based teleoperation,” marking a historic first in lunar exploration.

After finishing its exploration, the tiny robot transmitted images of its adventures to LEV-1. The hopping rover then transmitted the data to Earth. The team notes that all these steps were also accomplished autonomously.

The team notes that the LEV-2 shape-shifting rover operated for “more than 100 minutes: before losing communication with LEV-1. Although determining the exact cause may require direct examination of the two robots, Hirano’s team suspects that issues caused by LEV-1’s hopping motions or battery depletion “may have contributed to connectivity issues.”

Exploring High-Risk, Scientifically Valuable Environments

When discussing the implication of an autonomous, shape-shifting rover successfully navigating the lunar surface and completing its mission directives, the team concedes that the capabilities of a single, small rover like LEV-2 “are inherently limited.” However, they also note that their mission success highlights the potential of this category of robotic platform “as independent explorers, capable of accessing environments beyond the reach of a primary large spacecraft.” 

“Swarm-controlled small robots are poised to be deployed in high-risk yet scientifically valuable environments, such as vents, caves, and steep slope craters, that are inaccessible to larger, conventional rovers,” the researchers conclude. “This approach promises to enhance both the efficiency and safety of future planetary surface exploration.”

The study “From ball to rover: Transformable palm-sized rover SORA-Q for autonomous lunar exploration” was published in Science Robotics.

Christopher Plain is a Science Fiction and Fantasy novelist and Head Science Writer at The Debrief. Follow and connect with him on X, learn about his books at plainfiction.com, or email him directly at christopher@thedebrief.org.

  •  

Jason Momoa’s 1920s Harleys become electric hybrids in wildest EV conversions yet

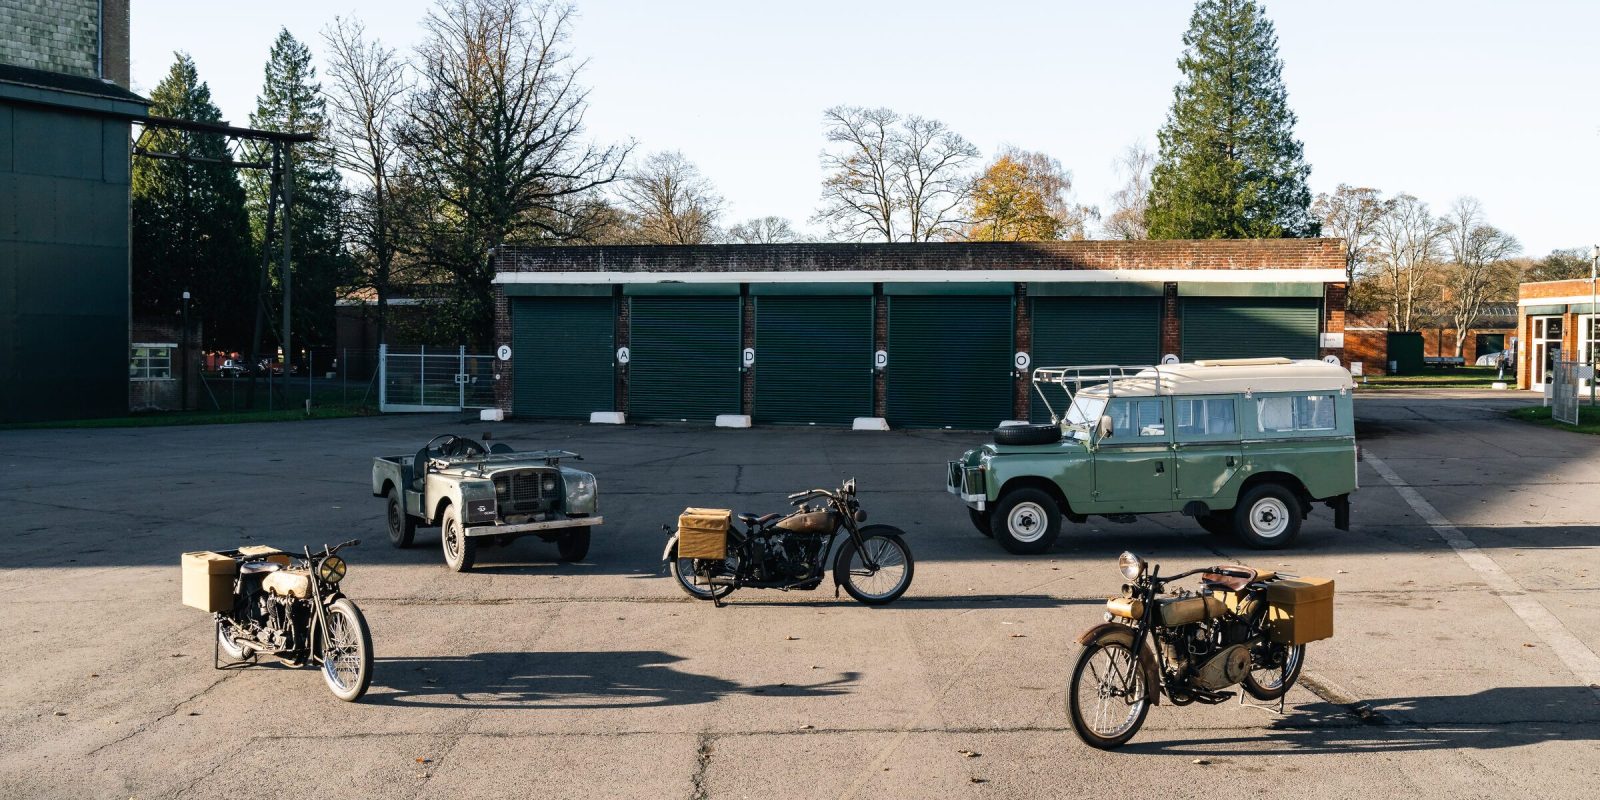
UK-based EV conversion specialist Electrogenic has converted five of Jason Momoa’s cherished vintage vehicles to electric power — including three 100-year-old Harley-Davidson motorcycles reimagined as plug-in hybrids. The builds are featured in Season 2 of Momoa’s HBO documentary series On The Roam, streaming now.

The project includes two extremely rare classic Land Rovers converted to all-electric drive with 150+ miles of range, a battery-equipped off-grid camping trailer, and the three Harleys that can switch between electric, petrol, and combined hybrid power on the fly. Electrogenic is now selling conversion kits for both the Land Rovers and the Harleys.

  •  
❌