❌

Reading view

From Lunar Dust to Lunar Cities:Β  Engineers Turn the Moon’s Harsh Surface into a Blueprint for Settlement


As NASA prepares for humanity’s return to the Moon, researchers at Texas A&M University are exploring how the same material could become a key building block for the first permanent settlements beyond Earth.

The Moon’s surface is surprisingly unlike anything we would consider soil on Earth. Instead, it is covered by a fine powder of pulverized rock and jagged glass that slips into every gap, grinds through seals and gaskets, and exists in a vacuum exposed to intense radiation and extreme temperature swings capable of bending steel. Yet researchers at Texas A&M University see opportunity rather than obstacles in this harsh environment.

Scientists refer to this material as lunar regolith, and it is considered one of the greatest challenges to long-term human habitation beyond Earth.

As NASA advances plans for a permanent human presence on the Moon through its Lunar Innovation Park initiative, Texas A&M researchers are developing technologies designed to transform the lunar surface into a foundation for future settlements.

β€œWe are moving past the era of β€˜flags and footprints,’” said Dr. Patrick Suermann, professor of construction science and retired U.S. Air Force lieutenant colonel in a statement. β€œWe have to stop thinking like explorers and start thinking like settlers.”

Money as a HurdleΒ 

Arguably, the greatest challenge facing lunar construction may not be engineering, but cost. Transporting materials from Earth remains extraordinarily expensive, with estimates ranging from roughly $1 million to $1.3 million per kilogram delivered to the Moon. As a result, researchers are increasingly focused on utilizing resources already available on the lunar surface rather than transporting materials from Earth.

β€œThe future depends on building infrastructure from resources already on the moon,” explained Suermann.

β€œThe high cost of shipping to the moon is the million-dollar problem,” Suermann said. β€œEvery time you can cut the mass of a payload, you save a fortune. That’s why the future depends on building infrastructure from resources already on the moon.”

Helping advance that vision is Dr. Robert Ambrose of the Texas A&M Space Institute, located near NASA’s Johnson Space Center in Houston. The institute has received $200 million in support from the Texas Legislature.

β€œOne of the most exciting features of the 240-acre facility is it’s two-and-a-half acre testing areas: one replicating the surface of the moon, the other Mars,” says Suermann.

These facilities allow researchers to evaluate robotic systems, autonomous vehicles, and construction technologies under conditions similar to those expected during future lunar and Martian missions.

Meanwhile, the university’s Construction Automation, Safety and Education (CASE) Lab is exploring how humans and machines can collaborate in extreme environments. Led by Dr. Gilles Albeaino, the lab focuses on mixed-reality technologies and semi-autonomous robotic systems capable of performing construction tasks on the Moon.

β€œOn the moon, construction operations will depend on semi-autonomous robotic systems,” Suermann said. β€œThe CASE lab is leading research into how humans and machines can work together in environments where humans can’t safely do everything themselves.”

β€œEvery tool matters. Every ounce of material you ship matters,” added Suermann. β€œSo, the question becomes: how do you use the environment itself as your supply chain, and how can you augment machines to become your partner in austere environments?”

Arctic to Afghanistan

Suermann’s experience combines two worlds: military service and construction science. Before joining Texas A&M in 2017, he served in the U.S. Air Force, deploying to remote locations that included Afghanistan, Guam, and Greenland.

Those experiences operating in challenging and isolated environments continue to inform his thinking about future lunar settlements.

β€œMy experiences in serving the U.S. Air Force were formative and transformative,” Suermann said. β€œIt taught me a great deal about construction, and that what can go wrong will go wrong.”

It shows, to me, that lunar regolith isn’t too dissimilar from the terrain we have here on Earth,” Suermann adds. β€œAt the end of the day, construction is construction.”

ShouldΒ We Develop on the Moon?

The broader question remains whether humanity should be expanding its footprint beyond Earth at all. While plans for lunar settlements continue to advance, critics point out that many environmental, political, and social challenges remain unresolved here at home.

As governments and private companies invest billions into space infrastructure, some argue that humanity must carefully consider how development beyond Earth aligns with priorities on our own planet. Others contend that technologies developed for lunar habitation could ultimately provide benefits back on Earth, helping address challenges ranging from resource management to sustainability.

Chrissy Newton is a PR professional and founder of VOCAB Communications. She hosts the Rebelliously Curious podcast, which can be found onΒ The Debrief’sΒ YouTube Channel. Follow her on X:Β @ChrissyNewtonΒ and atΒ chrissynewton.com.

  •  

Revised Artemis lunar lander plans take shape

Blue Moon Artemis 3

NASA has provided more details about the revised approaches that Blue Origin and SpaceX are taking to accelerate work on Artemis lunar landers.

The post Revised Artemis lunar lander plans take shape appeared first on SpaceNews.

  •  

Transformers on the Moon? Japan Reveals Details of Tiny Shape-Shifting Rover’s Historic Lunar Exploration


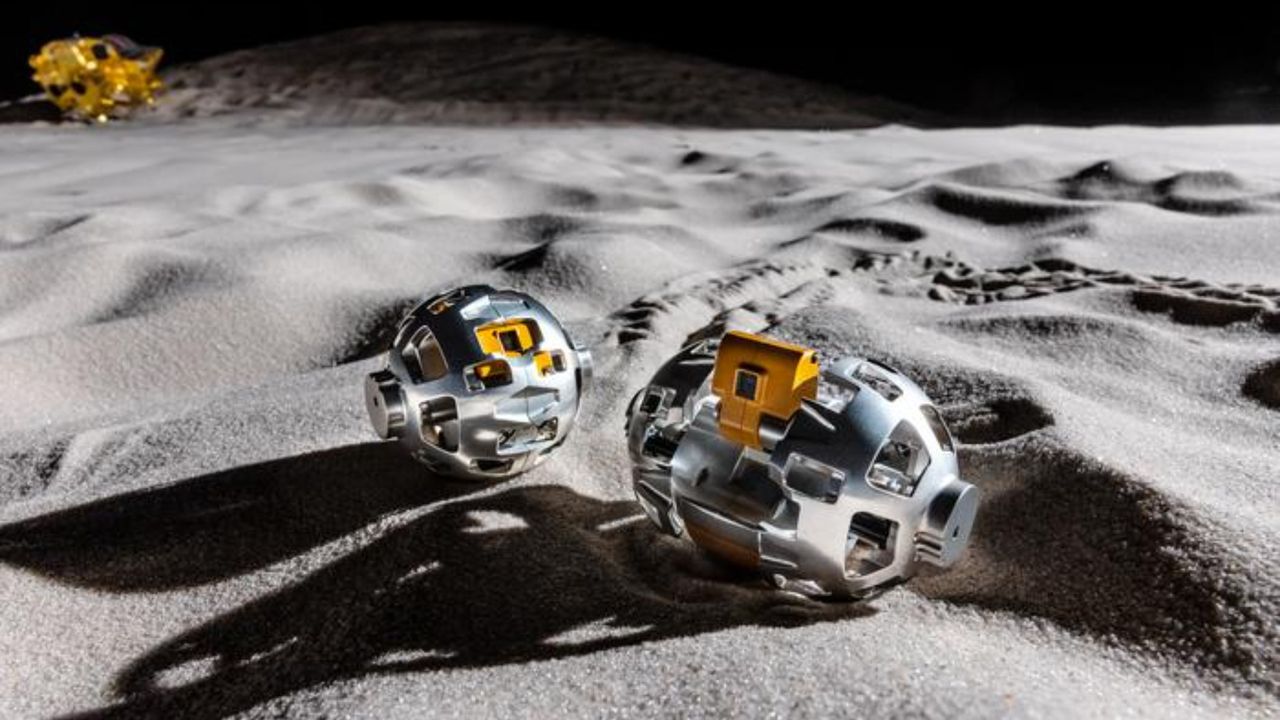
Over two years after Japan’s Smart Lander for Investigating Moon (SLIM) mission deployed a tiny, shape-shifting rover on the Moon, the country’s space agency JAXA has finally revealed previously unreleased details about the first-of-its-kind autonomous robotic lunar exploration.

According to a statement announcing the recently published mission account, the SLIM team deployed the rover on the Moon’s surface, β€œafter which the rover transformed from a tiny sphereΒ into a wheeled robot that took images of the lander and its environment.” A second rover transmitted the data back to Earth, with all steps occurring autonomously.

The team behind the historic mission said their success could pave the way for swarms of small, transformable robots capable of exploring high-scientific value areas that larger spacecraft and robots cannot reach, including caves, tunnels, lava tubes, vents, and deep extraterrestrial craters.

The Benefits of Tiny Robots and Autonomous Shape-Shifting Rovers

In the published study, the JAXA team explains that robotic technologies like SLIM β€œare expected to drive substantial advancements in planetary exploration and resource prospecting” by performing tasks in extraterrestrial environments that are inaccessible to other platforms, including human astronauts. For example, the team noted that miniature robots offer tremendous weight savings over bulkier platforms, especially when added to missions with β€œstrict payload limitations.”

β€œMiniature robots have the potential to reduce payloads and to reach cramped spaces such as small vents and craters that are inaccessible to larger, conventional robots,” they explain.

Still, the SLIM team notes that building tiny, shape-shifting rovers capable of exploring a variety of complex environments presents its own set of challenges. The most limiting constraints involve computational power and battery capacity. The team also observed that smaller robotics platforms inherently suffer from β€œreduced locomotion performance” due to their small size.

Now, when revealing the details of the SLIM mission, the researchers note that advancements in miniaturization and computational performance spurred by the Internet of Things β€œhave catalyzed the emergence of smaller, lighter, and more intelligent rovers at lower costs.”

Introducing the β€˜Hopping’ Lev-1 and the β€˜Transforming’ Lev-2

To build a tiny, shapeshifting robot capable of exploring the lunar surface autonomously, team leader Daichi Hirano and colleagues designed the Lunar Excursion Vehicle (LEV) system, which comprises LEV-1 and LEV-2. According to the team’s statement, LEV-1 can communicate directly with mission planners back on Earth. For locomotion, the robot moves via what the team termed β€œa controlled hopping mechanism.”

The second robot, LEV-2, starts out as a compact sphere 8 inches in diameter. However, once on the Moon, the mission controllers said that the tiny robot can transform into a β€œtwo-wheeled rover with cameras and a tail stabilizer.”

β€œHere, we introduce a two-wheeled centimeter-scale rover, designated Lunar Excursion Vehicle 2 (LEV-2), also known as SORA-Q (named after the Japanese words for space and sphere), which transforms into a wheeled configuration from a compact spherical form, enabling efficient traversal of soft lunar terrains,” they write.

Transformers Make Autonomous Robotic Exploration History

According to the new mission details, the SLIM lander deployed LEV-2 β€œimmediately before its landing on the lunar surface.” In the mission details, the team explained that upon deployment, the rover autonomously extended its wheels, tail stabilizer, and cameras, β€œthereby enhancing its mobility and stability on soft lunar terrain.”

tiny robot shape-shifting rover autonomous
Overview of the motion sequence on the lunar surface. (A) Deployment of LEV-1 and LEV-2 from the SLIM lander prior to landing on the lunar surface. (B) Data transmission from LEV-2 through LEV-1 to the Earth. (C) Mode transition and motion sequence on the lunar surface. Image Credit: D. Hirano.

After deployment, LEV-2 navigated the lunar surface in the immediate area around the lander. According to the published study, β€œthe palm-sized rover accomplished autonomous lunar exploration by navigating around the SLIM lander, capturing images of both the SLIM lander and its environment.” Critically, the rover’s exploration was autonomous and β€œwithout reliance on ground-based teleoperation,” marking a historic first in lunar exploration.

After finishing its exploration, the tiny robot transmitted images of its adventures to LEV-1. The hopping rover then transmitted the data to Earth. The team notes that all these steps were also accomplished autonomously.

The team notes that the LEV-2 shape-shifting rover operated for β€œmore than 100 minutes: before losing communication with LEV-1. Although determining the exact cause may require direct examination of the two robots, Hirano’s team suspects that issues caused by LEV-1’s hopping motions or battery depletion β€œmay have contributed to connectivity issues.”

Exploring High-Risk, Scientifically Valuable Environments

When discussing the implication of an autonomous, shape-shifting rover successfully navigating the lunar surface and completing its mission directives, the team concedes that the capabilities of a single, small rover like LEV-2 β€œare inherently limited.” However, they also note that their mission success highlights the potential of this category of robotic platform β€œas independent explorers, capable of accessing environments beyond the reach of a primary large spacecraft.” 

β€œSwarm-controlled small robots are poised to be deployed in high-risk yet scientifically valuable environments, such as vents, caves, and steep slope craters, that are inaccessible to larger, conventional rovers,” the researchers conclude. β€œThis approach promises to enhance both the efficiency and safety of future planetary surface exploration.”

The study β€œFrom ball to rover: Transformable palm-sized rover SORA-Q for autonomous lunar exploration” was published in Science Robotics.

Christopher Plain is a Science Fiction and Fantasy novelist and Head Science Writer at The Debrief. Follow and connect with him on X, learn about his books at plainfiction.com, or email him directly at christopher@thedebrief.org.

  •  
  •  
  •  

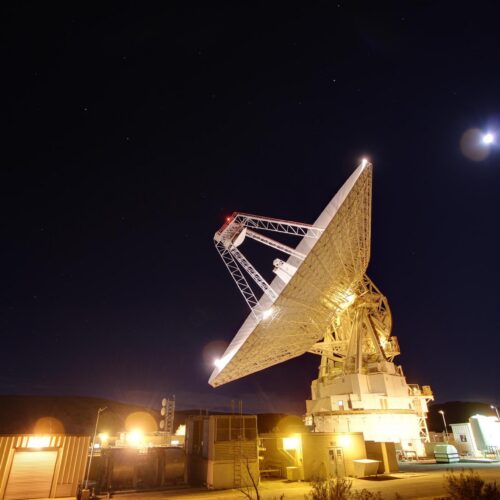
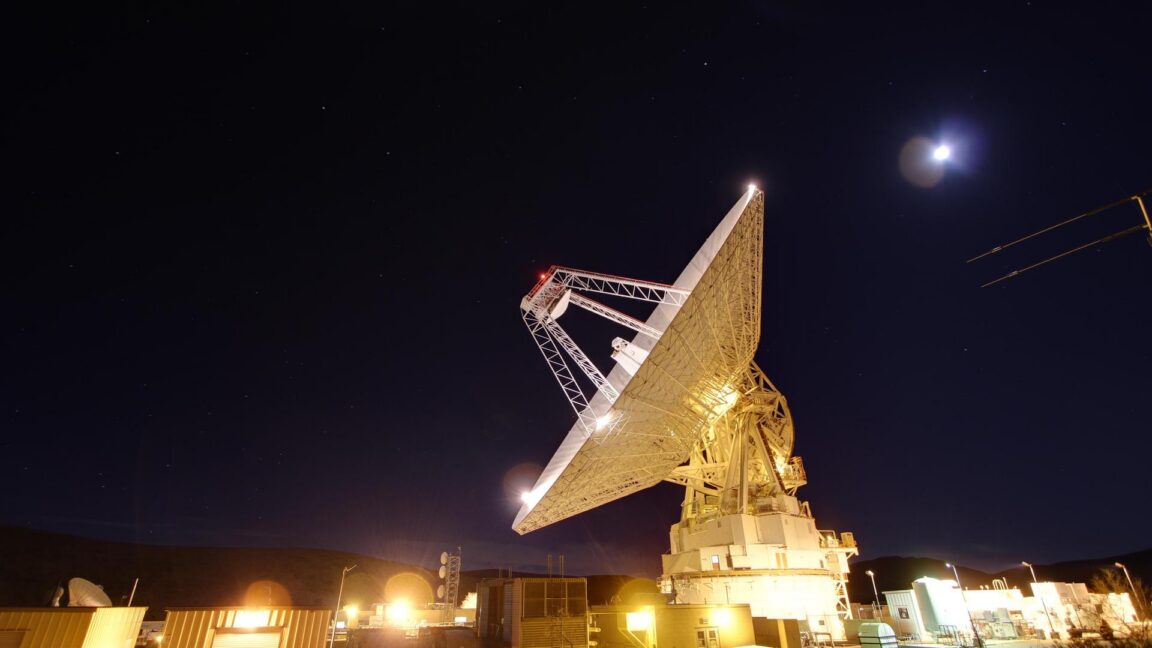
After nearly breaking, NASA's Deep Space Network "worked well" on Artemis II

NASA pushed its Deep Space Network beyond its limits during the Artemis I mission nearly four years ago. The global array of deep space communications antennas couldn't keep up with the routine demands of 40 robotic science missions and the extraordinary surge required by NASA's Orion space capsule as it flew around the Moon.

The experience in late 2022 reduced or delayed downlinks from several high-profile science missions, including the James Webb Space Telescope and Mars rovers, as the data-hungry Artemis I mission took priority on NASA's communications network. And that was before the first Artemis mission with astronauts onboard. When Artemis II launched April 1, NASA called upon the Deep Space Network (DSN) again to connect Mission Control to the Orion capsule as it soared more than a quarter of a million miles from Earth.

With a crew of four flying inside the spacecraft, the agency's appetite for data from Orion on Artemis II was even higher than it was on Artemis I. But at a little more than nine days, the Artemis II mission was shorter than the 25 days Artemis I spent in space, helping alleviate the communications overload. Artemis I also launched 10 small CubeSats into deep space, many of which required tracking and telecom services from the DSN. Artemis II carried fewer CubeSats.

Read full article

Comments

Β© NASA/JPL-Caltech

  •  

Lunar Meteorite Preserves Evidence of Colossal Asteroid Strike

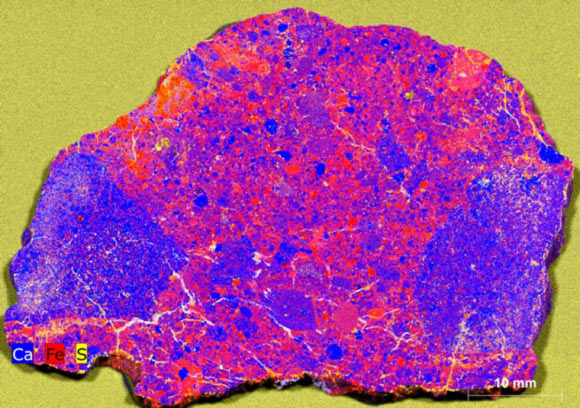
XRF map of 7.53 g slice of NWA 12593: calcium (Ca) and iron (Fe) illustrate the location and diversity of clasts; sulfur (S) highlights the location of cracks and terrestrial weathering. Image credit: Crow et al., doi: 10.1130/G54386.1.

Planetary scientists analyzing a lunar meteorite known as Northwest Africa (NWA) 12593 have uncovered evidence of an asteroid impact that occurred 3.5 billion years ago on the Moon, helping to reconstruct a period of intense bombardment that left lasting marks across the inner Solar System.

The post Lunar Meteorite Preserves Evidence of Colossal Asteroid Strike appeared first on Sci.News: Breaking Science News.

  •  

This Curious Moon Rock Preserves Evidence of Ancient Impacts Across Three Worlds


The ancient history of our planet’s impact events is coming into focus, thanks to researchers who have triangulated similarly aged impacts on Earth, the Moon, and the asteroid 4 Vesta in a new study.

The lunar meteorite NWA 12593 correlates not only with impact events observed across three locations in our solar system but also contains evidence of three separate impact events that occurred at different times.

The findings, revealed in a recent paper published in Geology, show that scientists are using this new impact data to fill in the volatile early-Earth period when life began.

Early Earth Impacts

The Archean period, roughly 4 to 2.5 billion years ago, was a consequential time from which our earliest fossil records date, corresponding to around 3.5 billion years ago. Researchers believe that life likely first arose at this time, yet it may have faced adversity from bombardment by space rocks between 3.2 and 3.5 billion years ago, although scientists disagree on how intense this impact activity was.

Our planet’s geological activity eventually destroys evidence of the ancient past through erosion, subduction, and burial, continually reshaping the surface. Yet those early years are essential to understanding the origins of water, atmospheres, and life on Earth.Β 

β€œOn Earth, the first fossil evidence of life shows up around 3.5 billion years ago, meaning that life is emerging and evolving before then. The question that we often have, even going back further, is what was the impact record when life was emerging?” said lead author Carolyn Crow, a planetary scientist at the University of Colorado Boulder.

β€œIt is important for understanding how life is taking hold, how life is emerging,” Crow added. β€œThe cadence of these catastrophic events is an important part of the equation.”

A Neighbor Remembers

While Earth’s surface is constantly renewed by geological processes, our nearest significant neighbor, the Moon, is much more stable, retaining its geological record for longer periods. Because of this, lunar meteorites provide a resource for scientists to understand the impact of Earth and the inner solar system by matching them to known impacts on our planet and in the asteroid belt.

For the recent study, the team focused on a lunar meteorite discovered in northwest Africa, designated NWA 12593, and identified three separate impact events in a single sample.Β 

Radiometric dating traced the oldest to 3.5 million years ago, intriguingly close to the time of the earliest known fossils. Extraordinary in power, this impact produced the mineral zirconia by melting the lunar surface into a lava-like flow. Without the precise laboratory conditions required to produce stable cubic zirconia, only traces of mineral remained in the sample.

According to the team, the first impact aligns with previously known impact events on Earth, and the fourth-largest object in the asteroid belt, 4 Vesta. It’s extremely rare to find such corresponding evidence between three bodies, providing important data on this time of frequent collisions.

β€œIt’s not very common, which is why we’re very excited about it,” says Crow. β€œIt’s pretty rare to have all three records line up like this.”

Later Impacts

Evidence of later impacts included breccia composed of large, angular, broken mineral fragments cemented together. The team believes the breccia resulted from a second impact that struck the melt sheet formed by the first.

β€œBreccias are similar to what you would see if you went and chipped out a chunk of concrete. You would see all these little rocks, and then it’s fused together by the cement,” says Crow. β€œBut the meteorite is fused together by the impact process. You get all these chunks of different kinds of rocks that the impact hit into. These all get mixed up, and then it gets fused together like your concrete sidewalk.”

As for the third impact, the evidence for this is the meteorite’s mere presence on Earth; an event that occurred some time after the first would have ejected the lunar breccia, the researchers say, allowing it to eventually land on our planet.

In total, the sample reveals an intriguing impact history, preserving a record of bombardment that provides solid evidence for a flurry of activity in the inner solar system during a violent chapter in the early history of our Solar System.

The paper, β€œThree-Body Evidence of Ca. 3.7 Ga to 3.2 Ga Bombardment Across the Inner Solar System,” appeared in Geology on May 12, 2026.

Ryan Whalen covers science and technology for The Debrief. He holds an MA in History and a Master of Library and Information Science with a certificate in Data Science. He can be contacted at ryan@thedebrief.org, and follow him on Twitter @mdntwvlf.

  •  

NASA names crew for Artemis 3 mission to test lunar landers

Artemis 3 crew

NASA has named the astronauts who will fly the next Artemis mission, a test flight in low Earth orbit where Orion will attempt to dock with two lunar lander prototypes.

The post NASA names crew for Artemis 3 mission to test lunar landers appeared first on SpaceNews.

  •  

Meet the NASA Astronauts in the Artemis III 4-Person Crew

NASA’s next mission in its effort to return humans to the moon will be led by an all-male crew. Three of them have extensive experience in space, while the other was a backup on Artemis II.
  •  

Why does one side of the Moon have a lot of craters, while the other does not?

Why does one side of the Moon have a lot of craters, while the other side does not? Stephen LogesBrooksville, Florida When the first photos of the Moon’s farside were obtained, people usually expressed the difference between the back and the front in terms of β€œmore craters on the back.” It might be better toContinue reading "Why does one side of the Moon have a lot of craters, while the other does not?"

The post Why does one side of the Moon have a lot of craters, while the other does not? appeared first on Astronomy Magazine.

  •  
❌