❌

Reading view

South Korean 'robot dog' became first to run a marathon on a single battery charge β€” now we know how

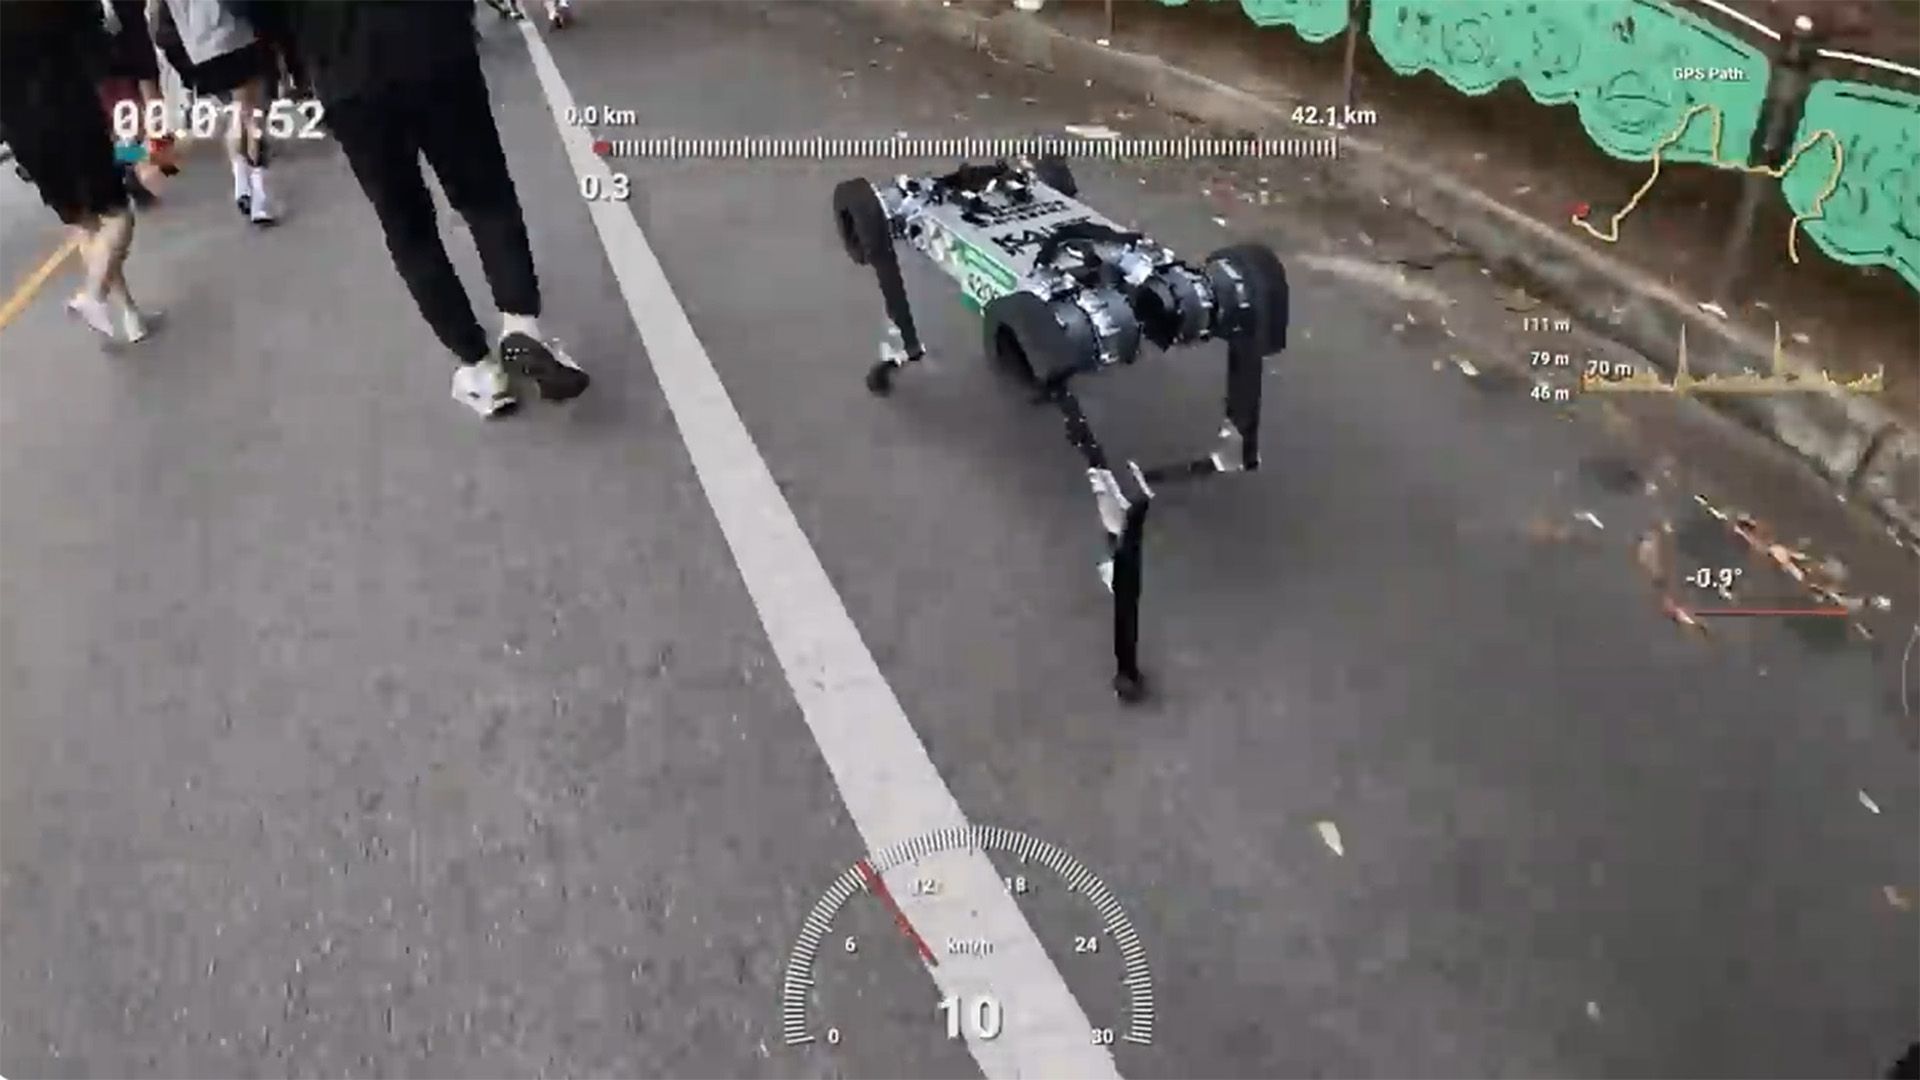
A four-legged robot completed a full marathon on a single battery charge, covering 26.2 miles (42.2 kilometers) on a hilly public-road course in South Korea two years ago. Now we know a lot more about how it achieved this record-breaking feat.

The dog-like robot, called RAIBO2, finished the 22nd annual Sangju Dried-Persimmon Marathon in just over 4 hours, 19 minutes. The bot's developers say it's the first quadruped robot to have completed an official marathon-distance event without stopping to recharge. They're commonly referred to as "robot dogs" because the movement of their joints in both front and hind legs resembles that of canines.

The scientists outlined their findings about the robot's feat, which it achieved Nov. 17, 2024, in a study published Sept. 23 in the journal Nature.

This achievement represented a new milestone in overcoming a critical limitation for quadruped robots: endurance. Although four-legged robots can cross difficult terrain that wheeled machines struggle to traverse (like stairs and rugged trails), their endurance has been limited because powering multiple joints while repeatedly lifting and stabilizing the machine's body consumes huge amounts of energy.

"Unlike wheeled robots, quadrupeds continuously expend energy at their joints to support body weight and incur kinetic energy losses during intermittent foot-ground contact," the researchers wrote in the study.

RAIBO2's race was a demanding real-world trial. It took place during the Sangju Dried-Persimmon Marathon, with the bot racing alongside human participants. The route covered two 50-meter [164 feet] elevation climbs, with slopes of up to 10 degrees. Those kinds of gradients put increased strain on the robot's energy resources, stress-testing the bot's battery management capabilities, the scientists said.

RAIBO2 had previously run a 26.7-mile (43 km), GPS-guided route across a flat athletic field, which it knocked out in 4 hours, 40 minutes on one charge. However, an earlier marathon attempt across uneven terrain against other competitors had to be aborted around the 23-mile (37 km) mark after the robot's battery ran out. The robot's developers attributed that shortfall in part to frequent pace changes as the machine attempted to adjust to the pace of nearby runners.

To compensate, the team boosted the robot's battery capacity by 33% and tinkered with the control system, including implementing joint-stiffness control at the actuator. This allowed the bot to soften its leg when it had to absorb an impact or it needed a stable, forceful push-off. After the adjustments, RAIBO2 expanded to a maximum range of 41.6 miles (67 km) on a single charge, albeit on straight paths, according to the researchers.

Another key metric was RAIBO2's total cost of transport β€” a measure of the energy required to move a body over a given distance, with lower values indicating less energy expended. Researchers reported that RAIBO2 achieved a total cost of transport of 0.25, compared with a human benchmark of 0.37. The researchers said their machine was the first quadruped robot to surpass that figure.

The team attributed that efficiency to several optimizations across RAIBO2's software and hardware. Especially vital were its lightweight mechanical components, which were capable of transmitting kinetic energy from its joints with very little interference. They also credited a low-loss motor-driving circuit and, on the software side, a locomotion policy specifically streamlined to limit energy use. The system was also trained using the team's simulation environment, called RaiSim, which includes models of slopes, stairs and icy roads.

Like many electric vehicles, RAIBO2 can regenerate some battery by capturing kinetic energy, particularly while traveling downhill. That capability allows it to offset some of the energy it expends while climbing, though it doesn't eliminate the extra cost of hilly terrain.

The researchers said RAIBO2 has more than three times the travel range per charge of existing quadruped robots, with a total battery capacity of 2,016 watt-hours. It's in part because of that capacity increase that the team now estimates that the robot could travel up to 15.5 miles (25 km) farther than its marathon stint, up to a total of 41.6 miles (67 km).

That kind of endurance could broaden the roles for quadruped robots in places where wheeled models are impractical, the developers added in the study. For example, they could be useful in disaster zones and mountainous areas, where a sufficiently mobile, high-endurance robot could carry cameras, sensors or communications gear across uneven terrain.
  •  

Powerful new AI model will map the moon's surface in more detail than ever, NASA and IBM scientists say

IBM and NASA have partnered to create a new artificial intelligence (AI) model capable of processing decades of lunar data so scientists can more accurately map the moon's surface one day.

Decades of robotic lunar missions have left scientists with a massive, disjointed trove of data. Traditionally, this data has been parsed by limited transformer models such as SwinV2-B, created in 2022 as a general-purpose model to understand images and improve accuracy on photo recognition and related vision tasks. Spacecraft orbiting the moon captured this data using a mismatched array of sensors, without an accessible way to analyze or utilize it.

Specifically, images from high-resolution optical cameras, laser altimeters, radar reflectance tools and spectrometers that measure elemental density have created huge datasets β€” but unifying them into a cohesive picture of the lunar surface has been a labor-intensive and computationally demanding process.

To crack the data bottleneck, researchers from NASA and IBM teamed up to build the Lunar Foundation Model (LFM). This agile AI system is designed to piece together multimodal, multiresolution data to build a detailed picture of the lunar surface to support future missions. The team published their findings Sept. 10 in a technical paper shared with Live Science.

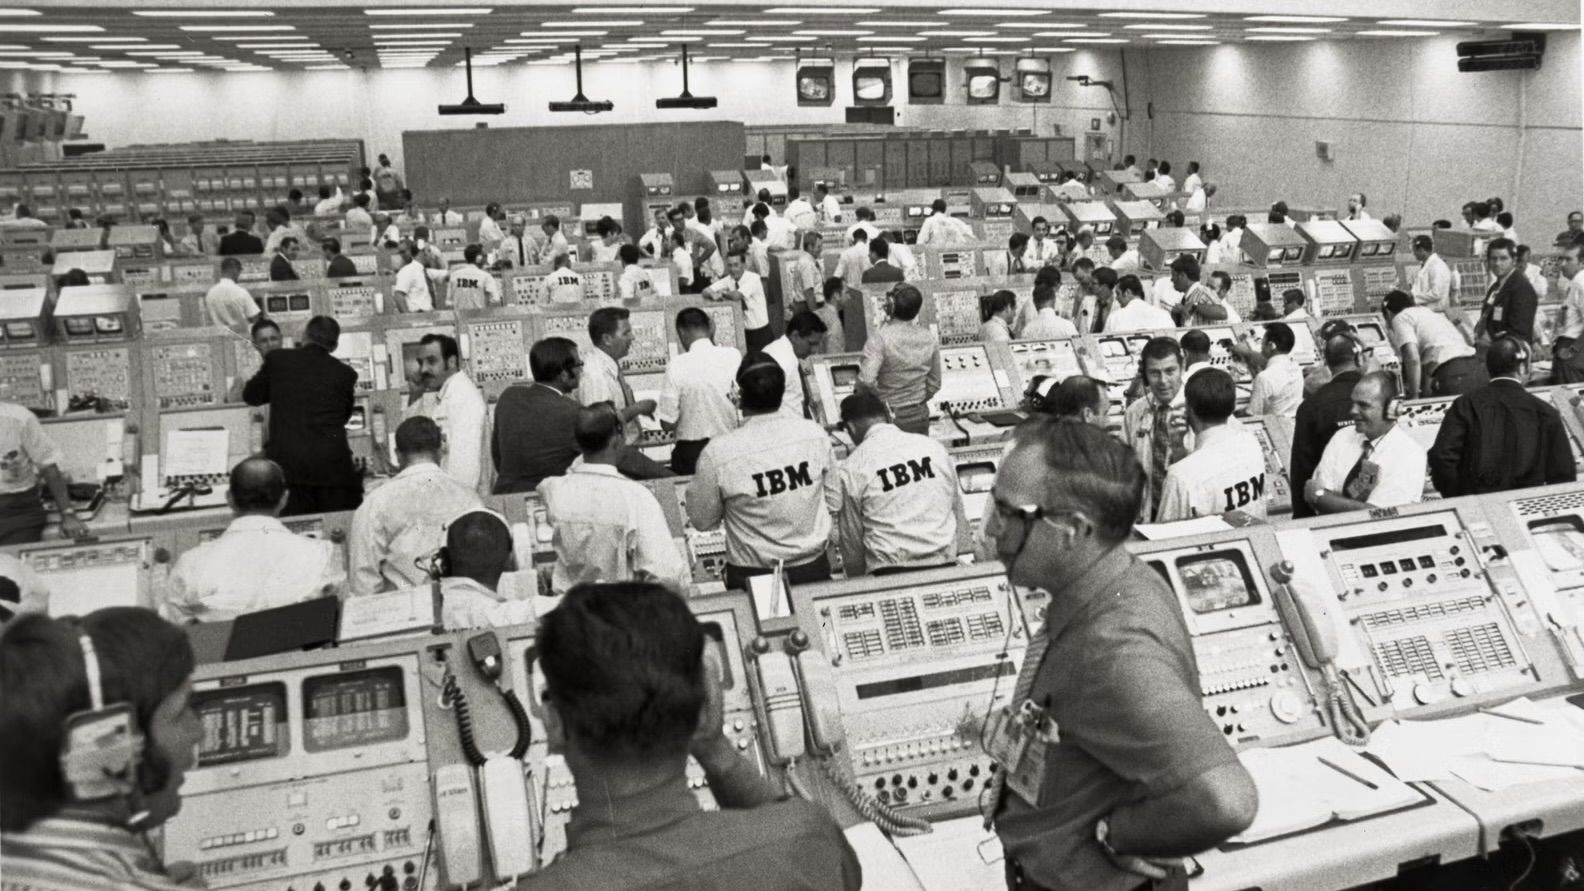
The Cape Kennedy Launch Control Center.

Scientists have collected troves of data about the moon over many decades β€” but much of it is disjointed and difficult to analyze. (Image credit: IBM)

The scientists wanted to build a single, reusable backbone AI model that would be freely available to scientists via the open-source AI model repository Hugging Face. Because the model is open-source, researchers could fine-tune the AI to tackle specific questions as part of different projects.

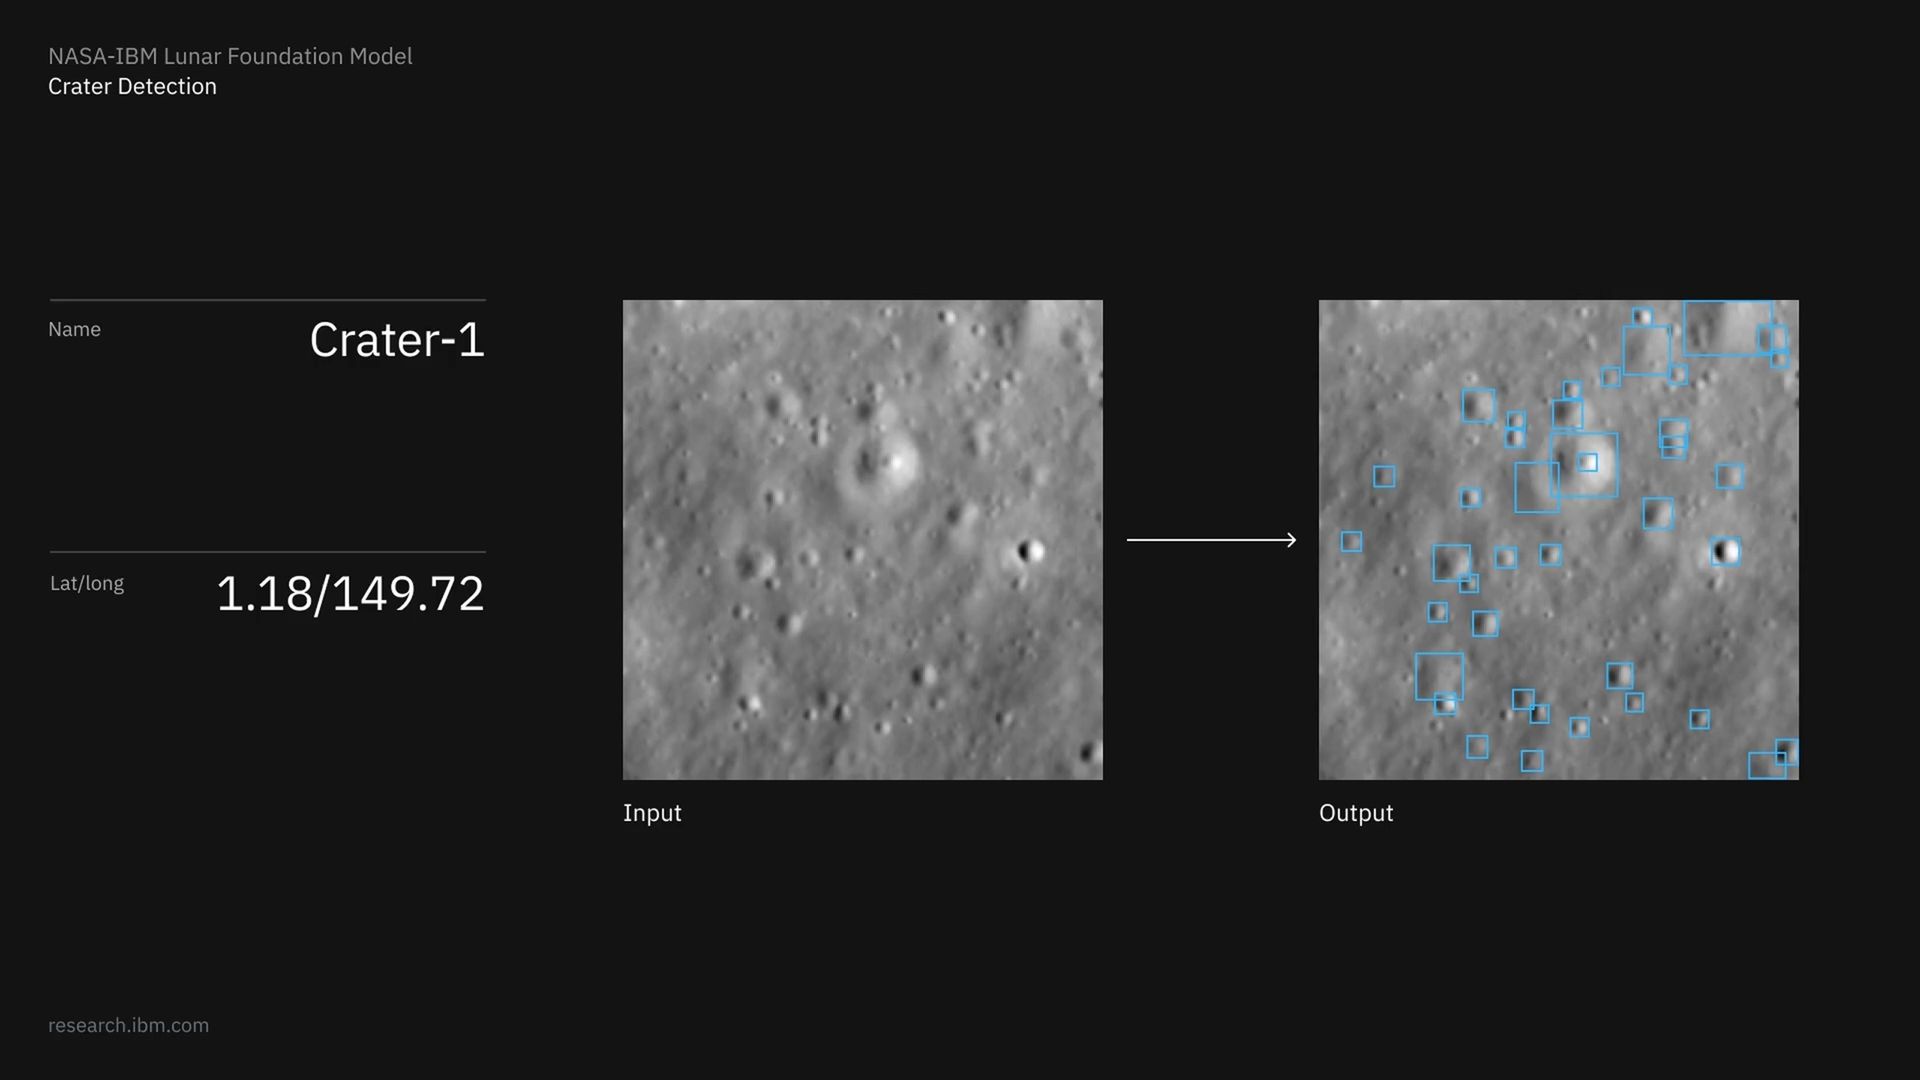
For NASA, this includes thorny issues such as generating a reliable crater map so researchers can plot safe landing zones, or analyzing those craters for clues about the chemical makeup of the moon's interior and its history.

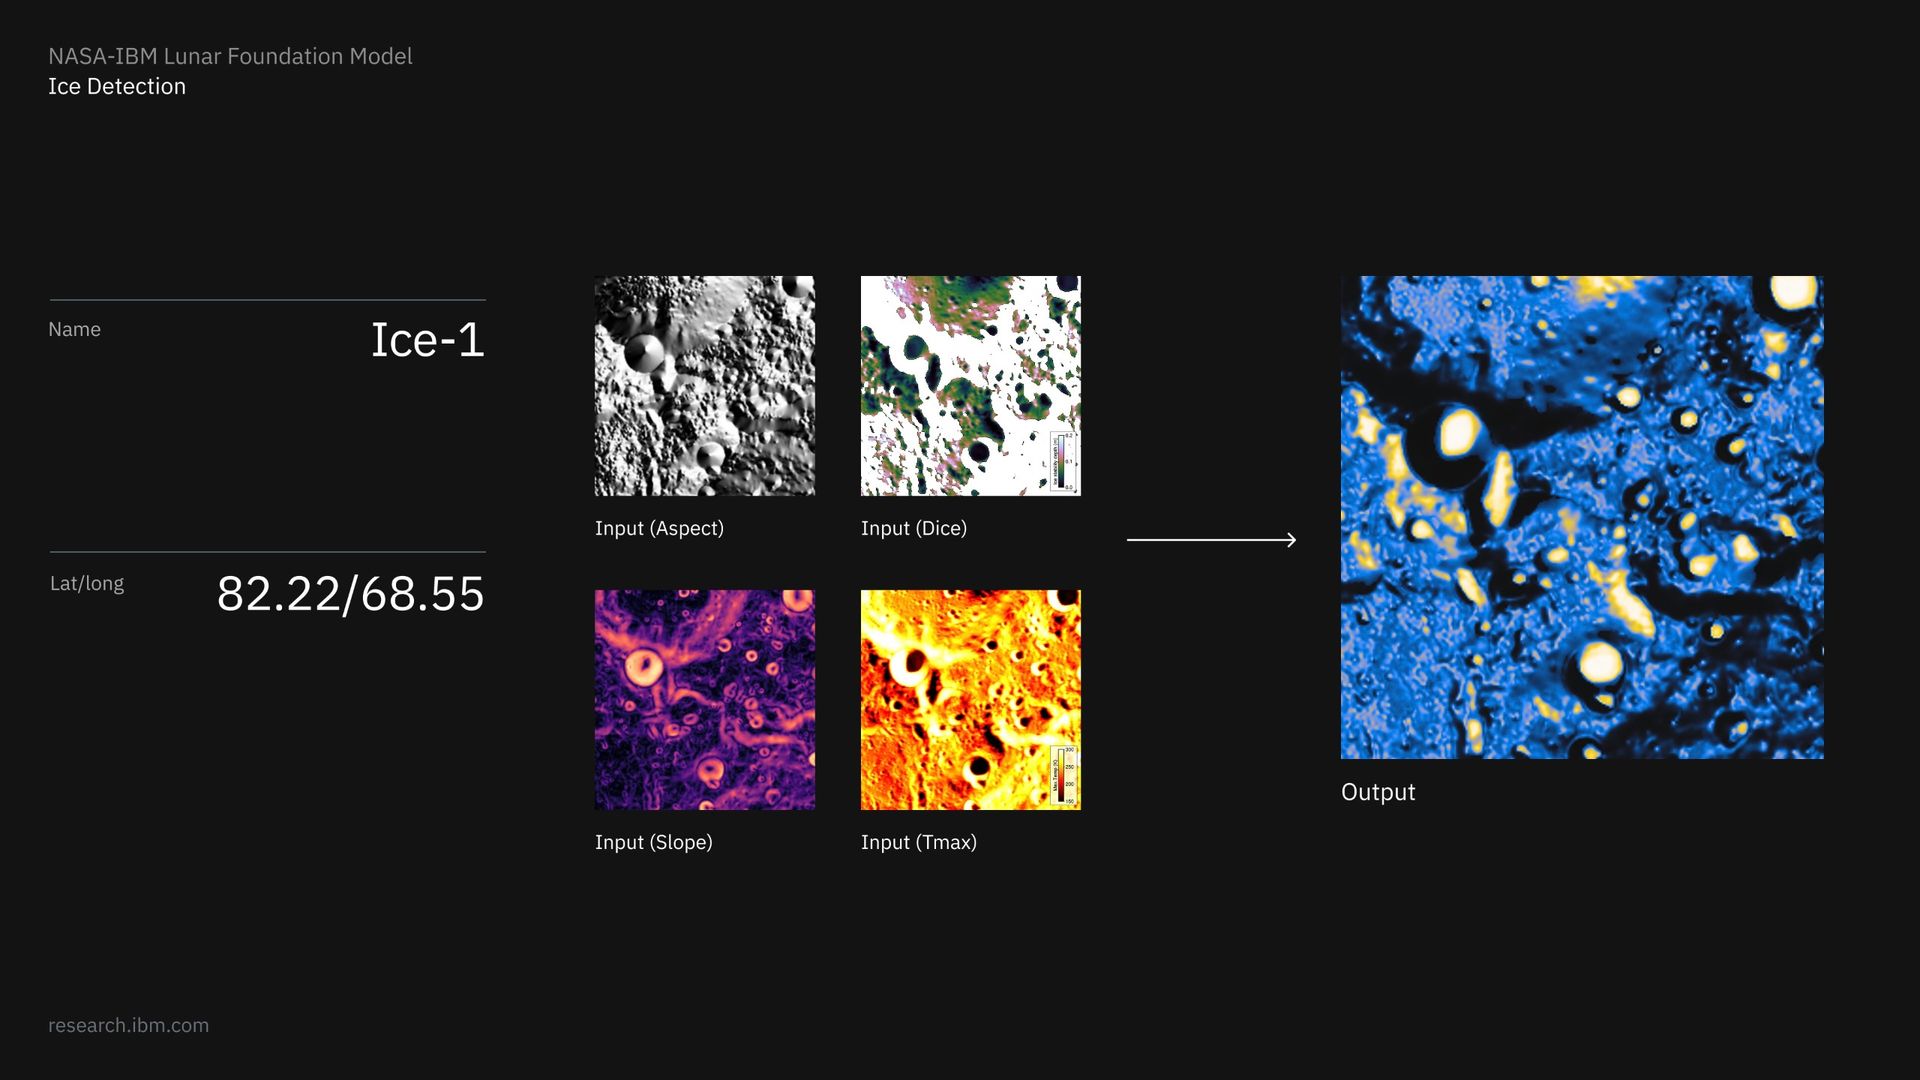
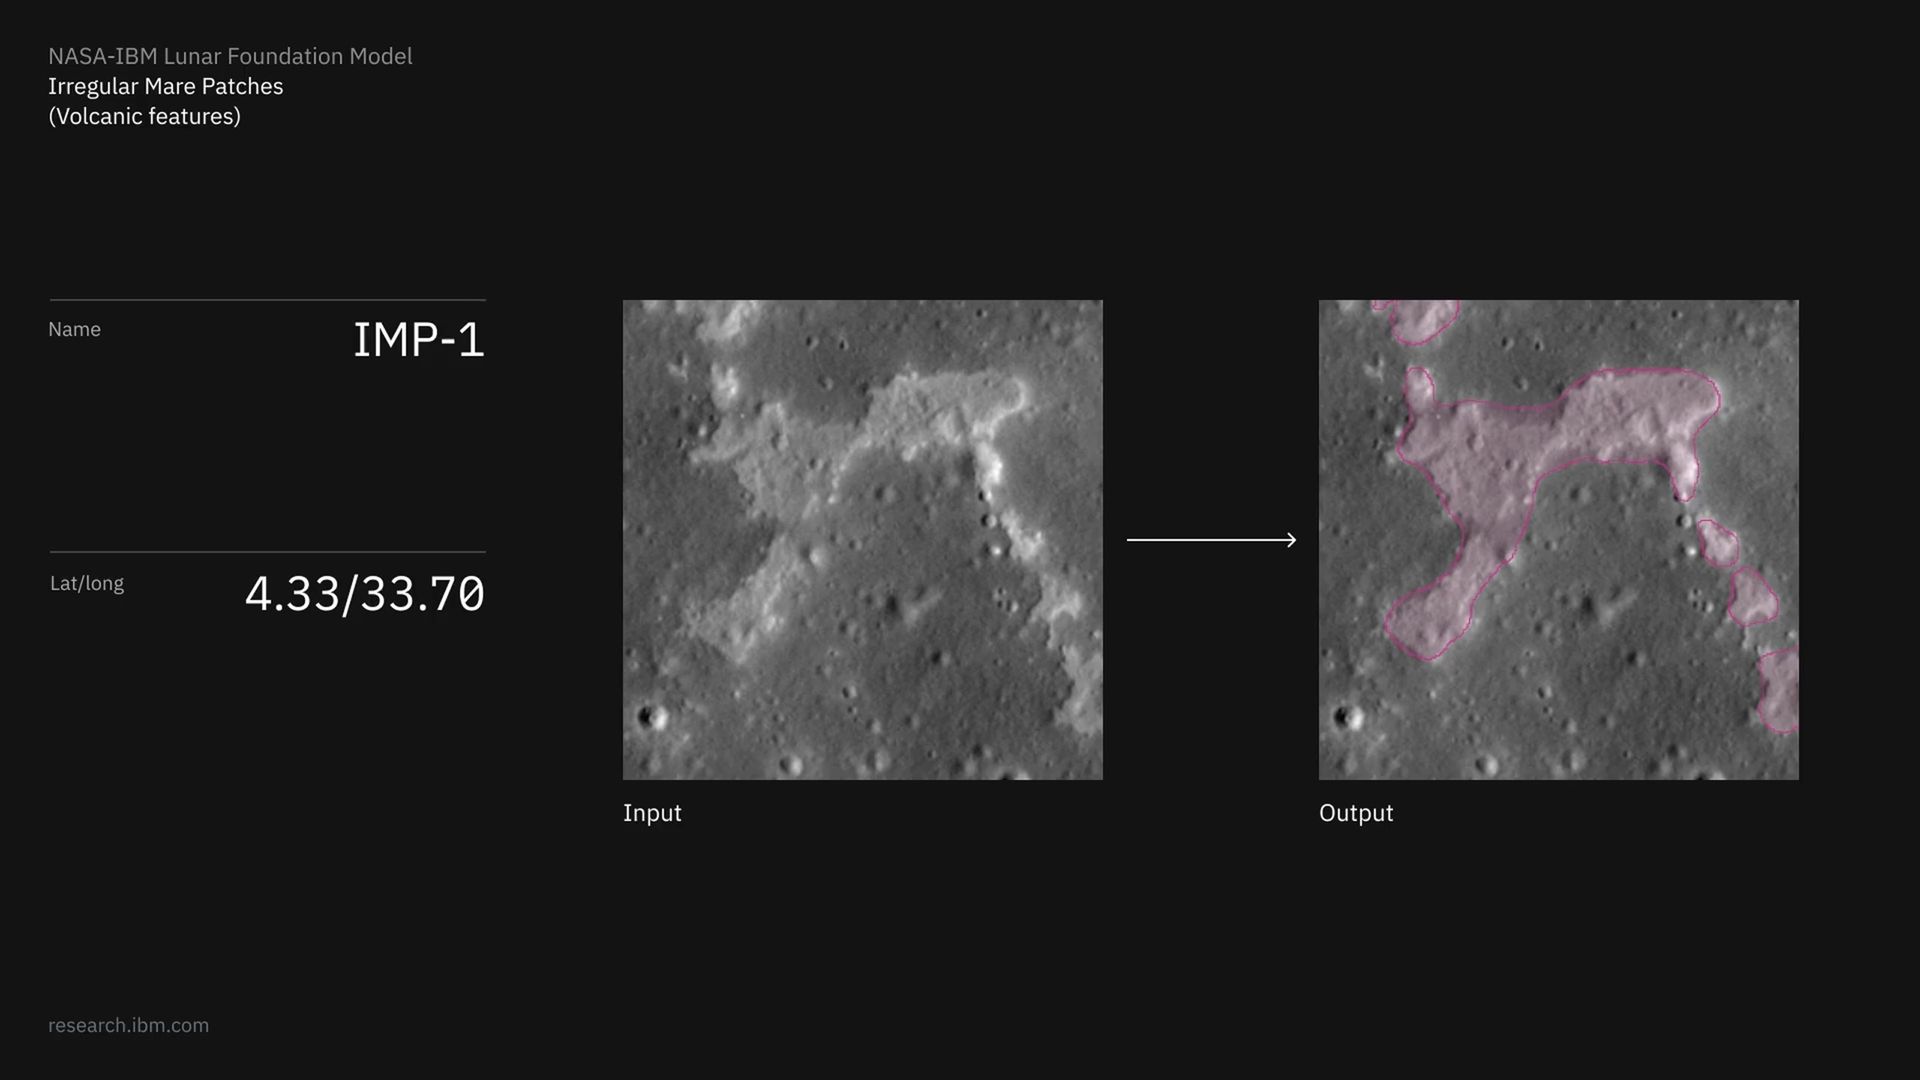
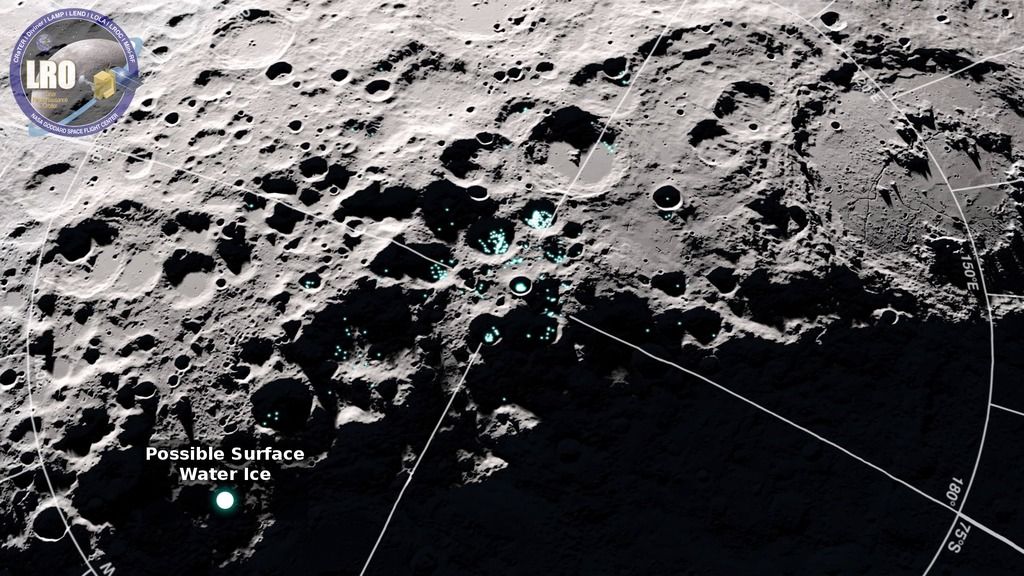
LFM also enables scientists to comb through the data for heavily shadowed sites on the moon that often conceal subsurface ice, which is critical for establishing long-term lunar bases. Volcanic activity can be tracked and collated too, which will allow future projects to avoid unstable terrain and reveal insight into the moon's thermal evolution.

Unique challenges

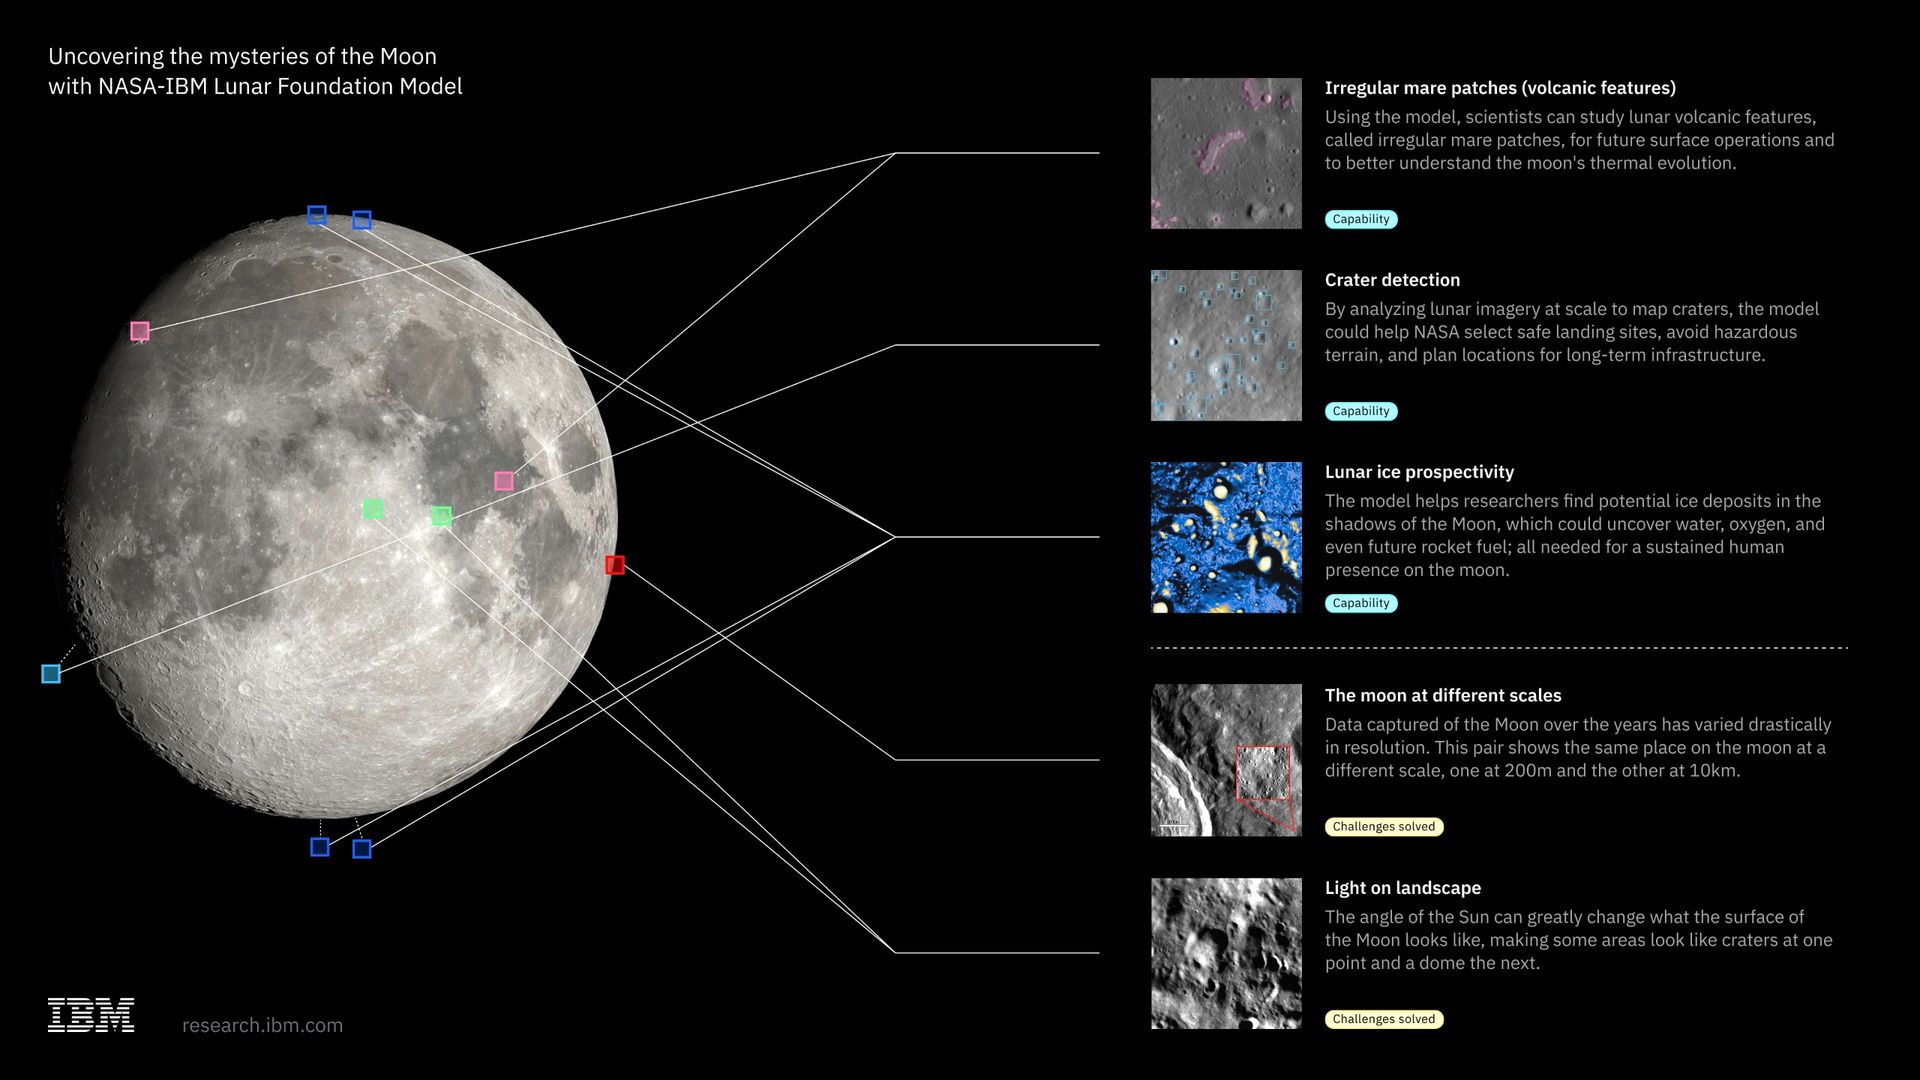
Processing lunar observations presents unique computational challenges that differ from those of similar models, which cover things like weather, geospatial data and heliophysics. NASA's Lunar Reconnaissance Orbiter and other spacecraft collect measurements across vastly different spatial scales, ranging from broad regional maps at a resolution of 100 meters per pixel down to terrain scans resolving at 1 m per pixel.

Because the moon lacks an atmosphere, extreme sunlight geometry is an issue, creating deep, deceptive shadows. Sunlight can also wash out subtle geological details, depending on when an image was captured.

To overcome these problems, the team compiled a layered benchmark dataset named SomBench, made up of nearly 2 million overlapping map patches called tiles. SomBench organizes that data into aligned tracks so data from completely different instruments, or imagery taken at different resolutions or angles, all end up together as long as they're capturing the same tiles.

The lower-resolution layers provide wide-angle overviews, as well as ultraviolet reflectance and elevation data. High-res layers combine tight, detailed camera shots with meter-scale terrain, slope and orientation maps. Specialized readings of thermal behavior, surface mineralogy and local gravitational anomalies also get layered in.

Visualization of the NASA-IBM Lunar Foundation Model’s ice prospectivity capability.
A visualization of the NASA-IBM Lunar Foundation Model’s ice prospectivity capability.IBM
A visualization demonstrating the NASA-IBM Lunar Foundation Model’s craterdetection capability.
A visualization demonstrating the NASA-IBM Lunar Foundation Model’s craterdetection capability.IBM
A visualization demonstrating the NASA-IBM Lunar Foundation Model’s ability to identify and map irregular mare patches (IMPs), rare volcanic features on the Moon’s surface.
A visualization demonstrating the NASA-IBM Lunar Foundation Model’s ability to identify and map irregular mare patches (IMPs), rare volcanic features on the Moon’s surface.IBM
An infographic illustrating how the NASA-IBM Lunar Foundation Model assists withanalyzing lunar imagery and data at scale.
An infographic illustrating how the NASA-IBM Lunar Foundation Model assists withanalyzing lunar imagery and data at scale.IBM

LFM learns to interpret all that layered data through a technique called masked-token learning, which is where parts of a dataset are hidden so the AI has to fill in the blanks. During training, the AI is shown a portion of a lunar tile, like its visible light appearance and elevation, and nothing else. The model then continuously predicts the concealed information across millions of examples, and learns the relationships between elements like lighting, terrain structure and physical geography.

Lighting analysis is built directly into the model's core architecture. Rather than forcing the model to infer light levels solely from shadows, researchers supplied explicit metadata describing solar angles and spacecraft positions. This allows the model to use its processing power to recognize actual terrain features rather than getting tricked by shadows.

One giant leap

The AI model performed well across four tasks it was evaluated on. In crater detection, it outperformed SwinV2-B by nearly 19% using half as many training labels. When estimating polar ice prospectivity within the top meter of regolith (lunar dust and rocks), LFM maintained strong predictive power with fewer data channels and reduced errors in identifying areas with high potential for lunar ice by up to 22% compared with SwinV2-B. Its performance on meter-scale crater mapping and rare volcanic landforms was similarly competitive with top custom models.

Scientists can customize LFM using lightweight techniques like low-rank adaptation β€” a way to fine-tune an AI by changing a tiny set of weights and not touching most of the original model. This allows researchers to tailor the model to specialized exploration tasks, without the steep computing costs of training an AI from scratch.

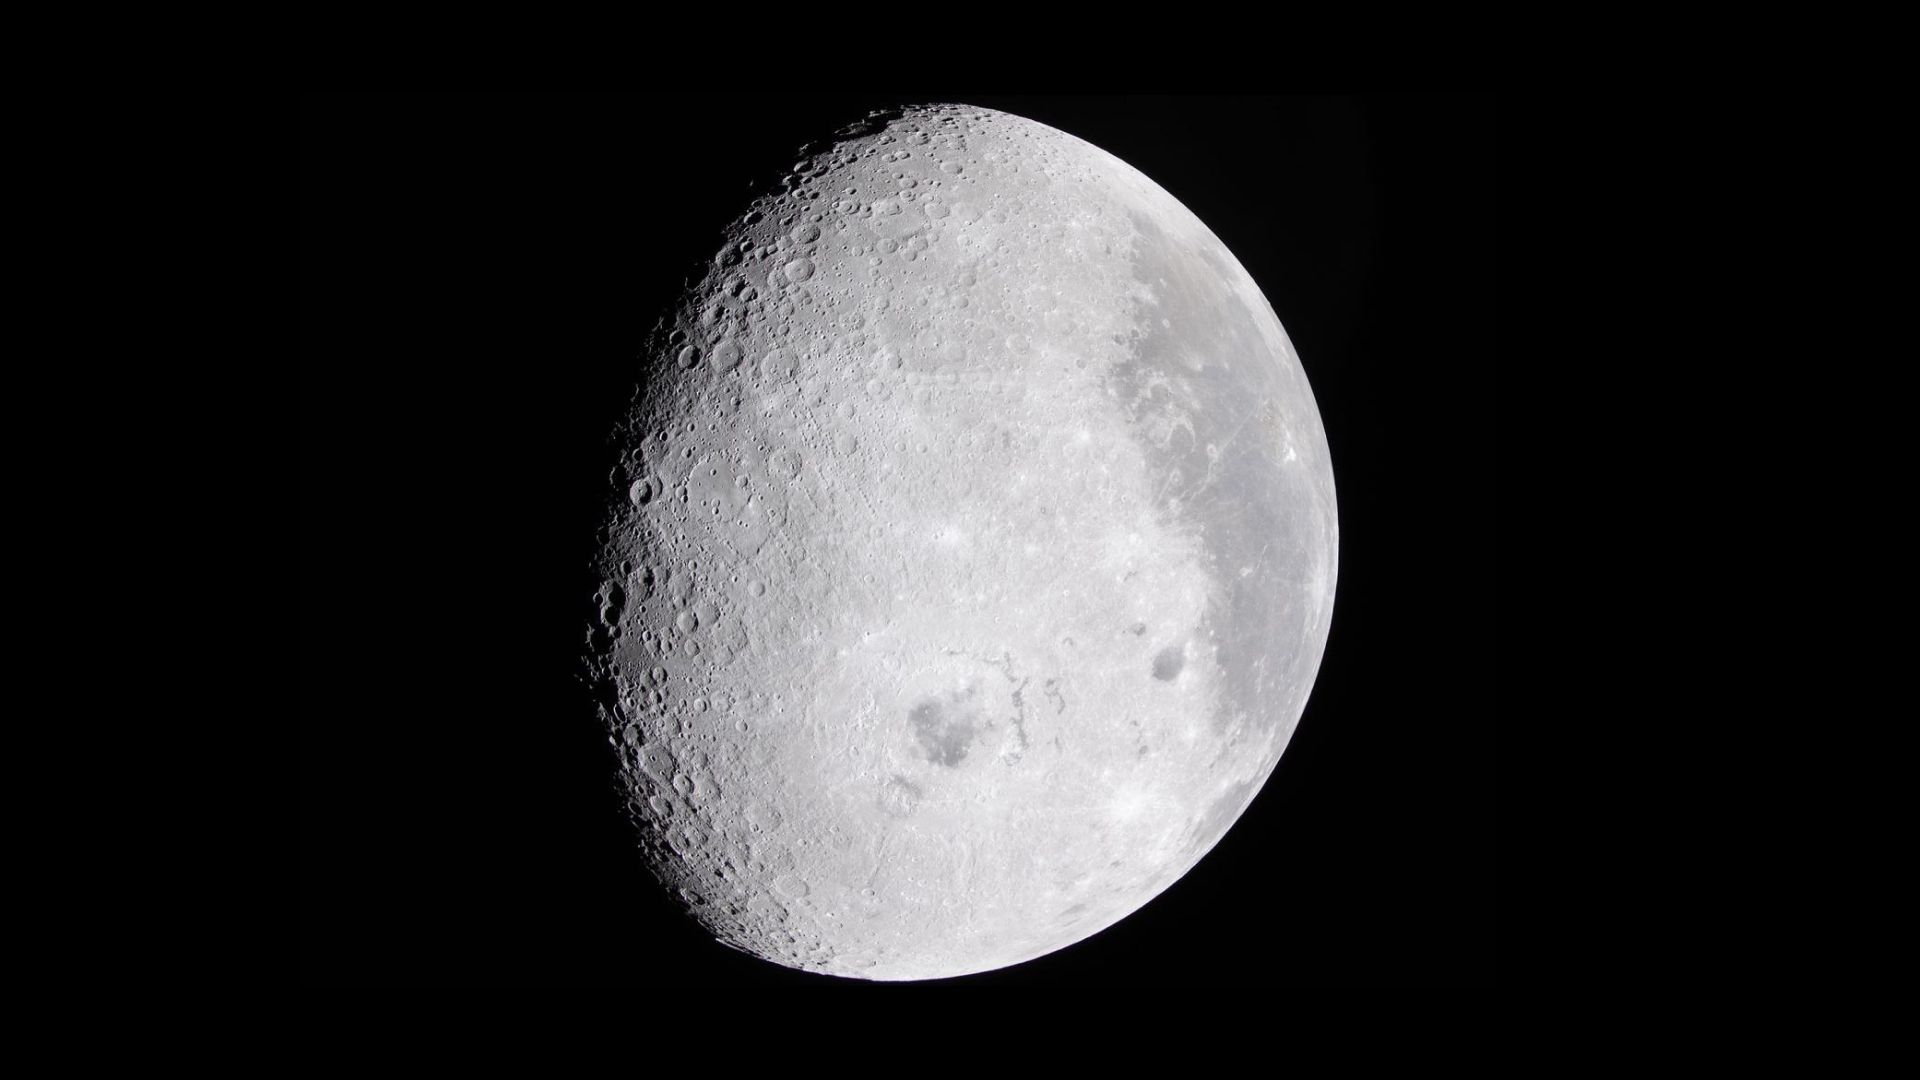
During the first shift of the lunar flyby observation period, the Artemis II crewcaptured more than two-thirds of the Moon, highlighting surface details on the nearside

LFM will be made available to researchers freely through the open-source AI repository Hugging Face so that teams can tailor it to their specific needs when studying the lunar surface. (Image credit: NASA)

However, the researchers cautioned in a statement that the system best serves as a pattern-recognition assistant and is not a replacement for direct physical measurements. Nonetheless, the team said the model represents a major leap toward transforming decades of raw data into a unified, intelligent toolkit for future robotic and crewed lunar missions.

In the near term, scientists will likely use the LFM as a backbone for key lunar remote-sensing tasks, while the long process of fine-tuning it ramps up. Over time, the model will be refined for tasks like improved crater detection and mapping, segmenting subtle geomorphic units such as irregular mare (volcanic activity) patches, and improving polar ice detection by integrating terrain, illumination, and thermal layers.

  •  

Faster than Usain Bolt? Here's all the records robot 'athletes' broke at this year's World Humanoid Robot Games in China.

Humanoid robots in Beijing have beaten a number of men's athletics world records at the 2026 World Humanoid Robot Games, claiming high-water marks in the 100-meter sprint, the 400 m, 1,500 m and high jump. While these performances aren't official replacements for the human records, as the robots competed under robot-specific categories and conditions, they highlight the progress made since last year's inaugural robot games .

The five-day games were held between Aug. 22nd and 26 at Beijing’s National Speed Skating Oval and drew 2,056 robots from 666 teams across 16 countries. The events included sports like football and martial arts, as well as practical applications like warehouse logistics, factory-style assembly and charging tasks.

Robots broke four human athletics records:

100 meters: Tiangong Ultra, 8.64 seconds

Human benchmark: Usain Bolt ran 9.58 seconds at the 2009 World Athletics Championships in Berlin.

Robot result: Tiangong Ultra is a humanoid robot developed by the Beijing Humanoid Robot Innovation Center. It won the large-size 100 m final, completing it in 8.64 seconds on Aug. 26. It set an early mark of 9.39 seconds, already enough to smash Bolt's record, then improved to 8.86 seconds in qualifying before the blistering 8.64 time in the final. That 8.64-second time is 0.94 seconds below Bolt’s mark.

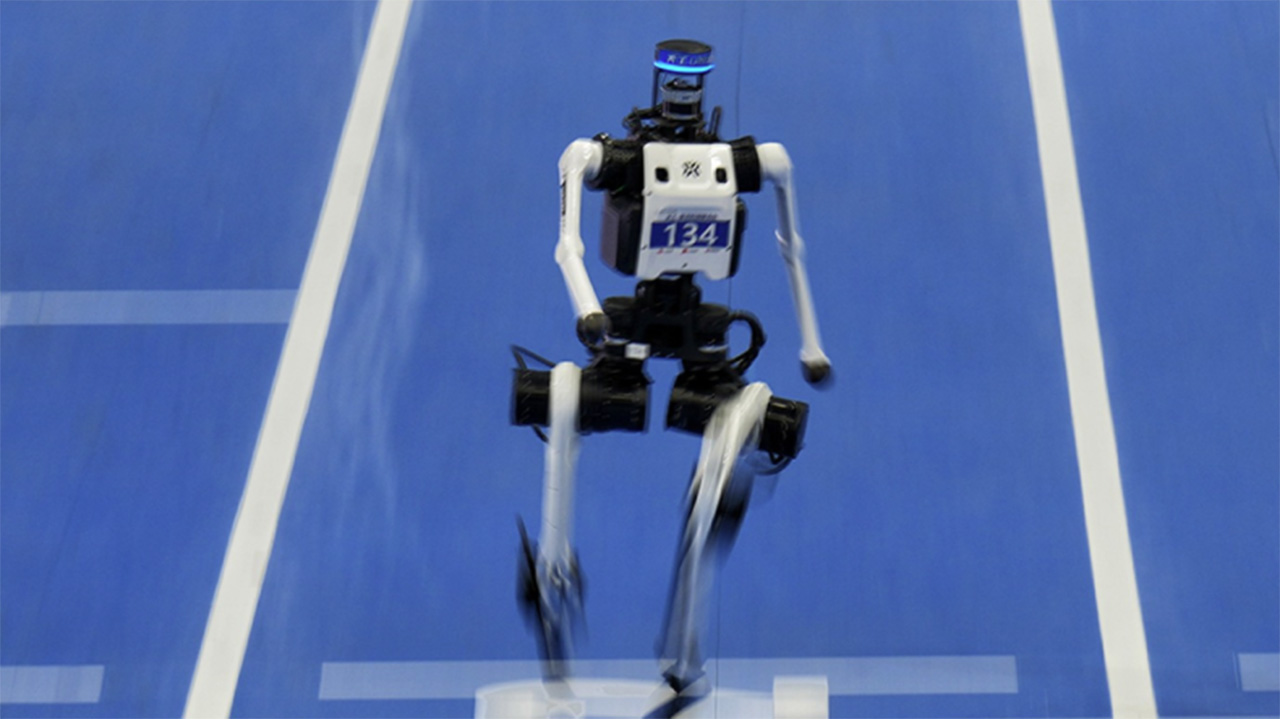
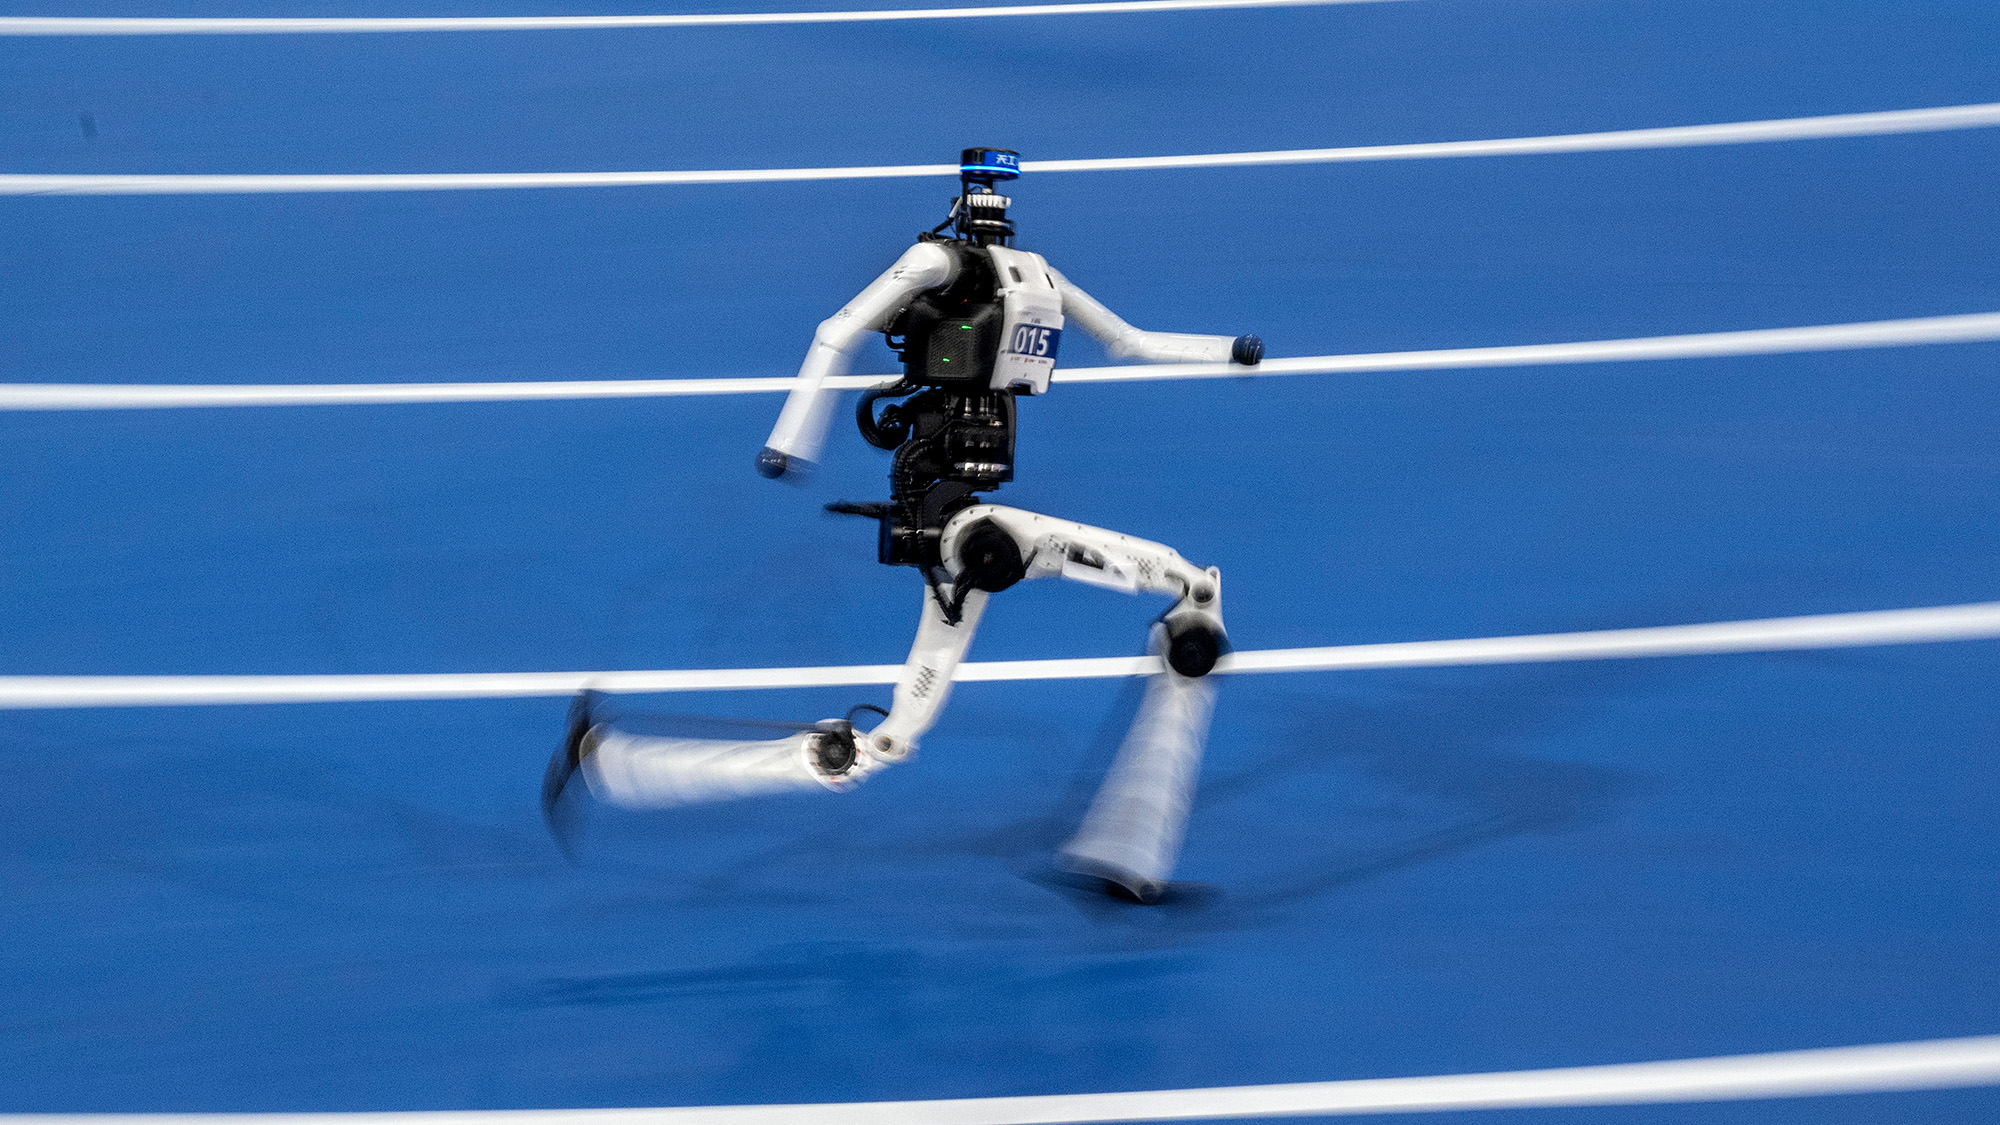
A humanoid robot runs on a blue track

The Tiangong Ultra robot running. (Image credit: X-Humanoid)

400 meters: Tiangong Ultra, 38.15 seconds

Human benchmark: Wayde van Niekerk's 43.03 seconds, set at the Rio Olympics on Aug. 14, 2016.

Robot result: The same robot that set the 100 m record dominated the 400 m competition as well. Tiangong Ultra won the 400 m final in 38.15 seconds, nearly 5 seconds faster than van Niekerk's world record.

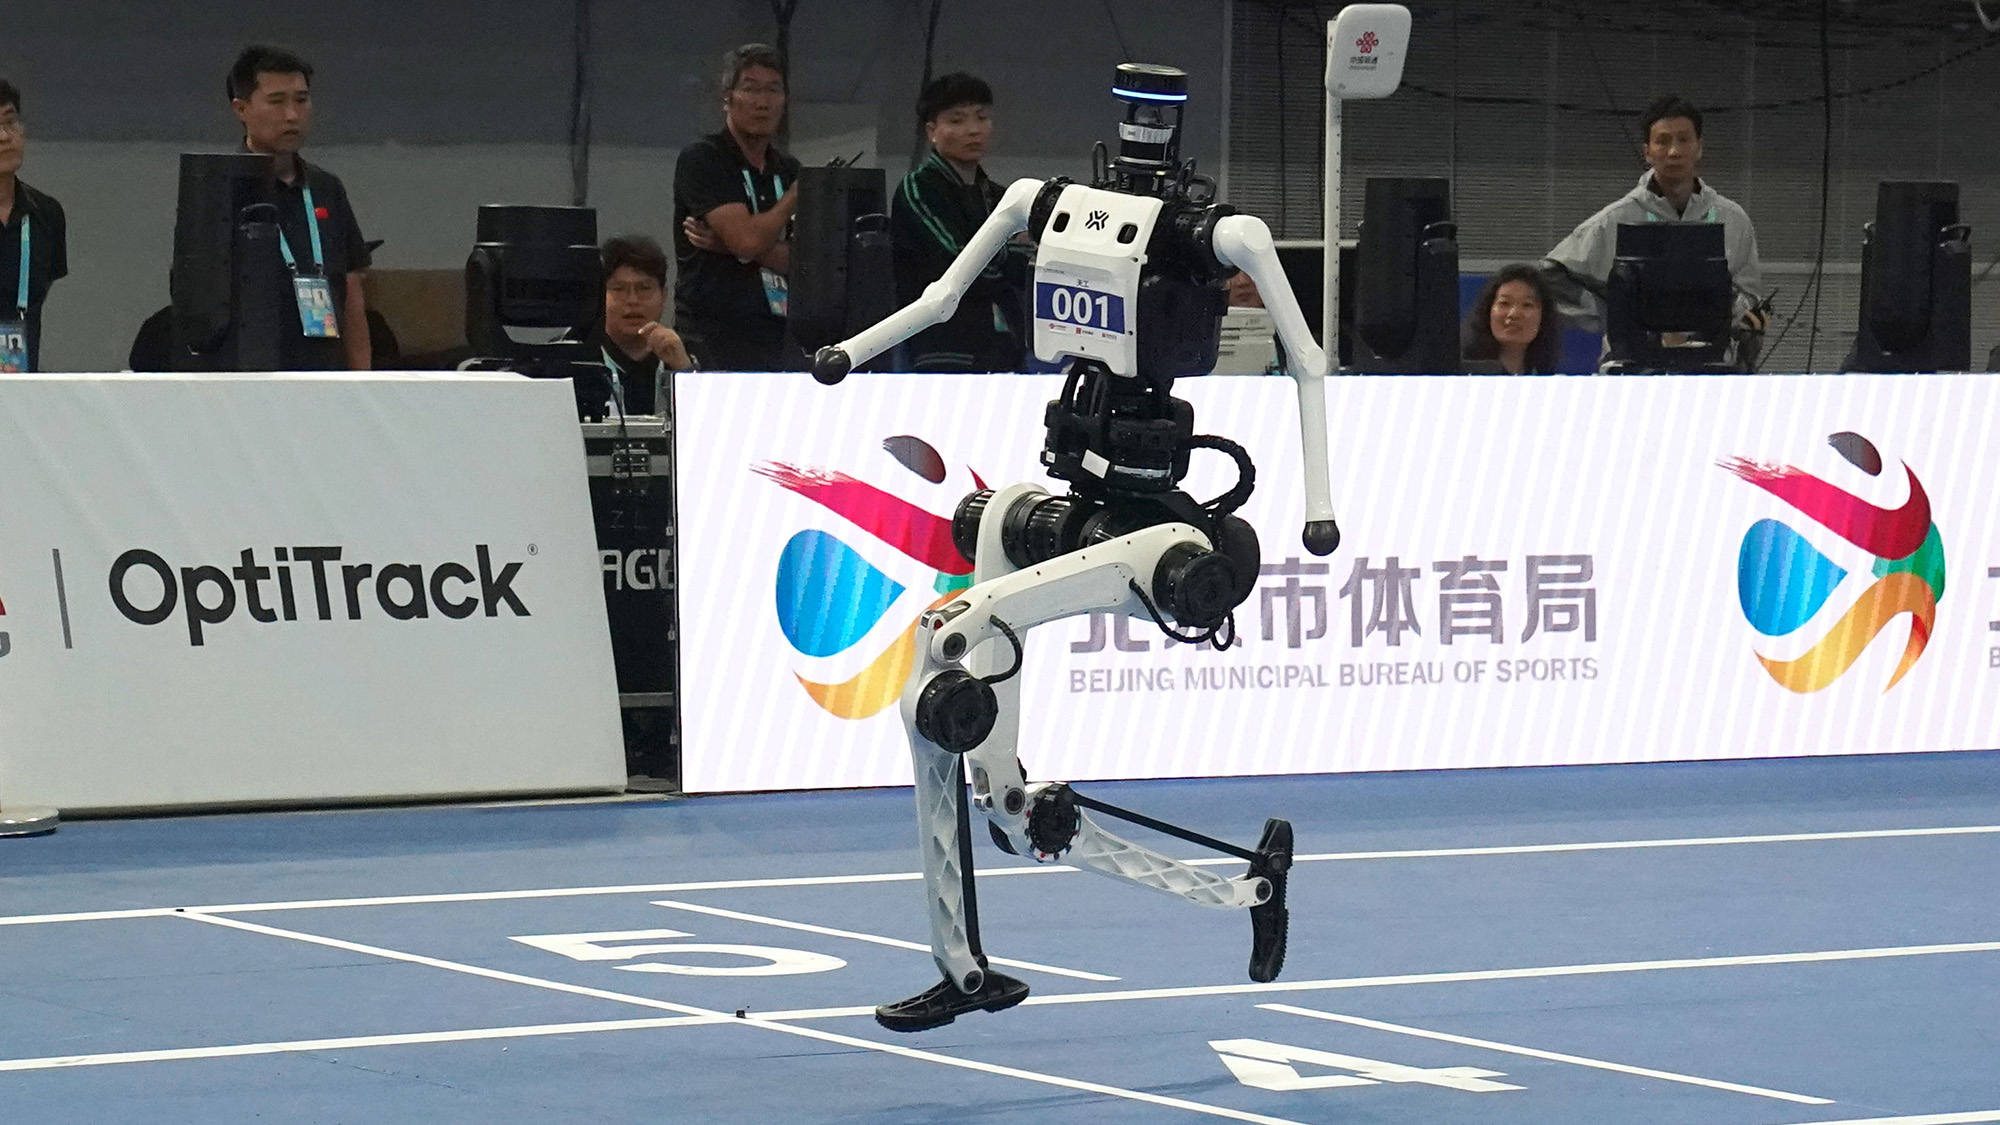
A humanoid robot runs on a blue track

Robots from Team Tiangong Ultra compete in the 4x100 meter relay final of the 2nd World Humanoid Robot Games at National Speed Skating Oval in Beijing, China, on August 25, 2026. (Image credit: VCG via Getty Images)

1,500 meters: Tiangong Ultra, 2 minutes, 21.6 seconds

Human benchmark: Hicham El Guerrouj of Morocco set the men’s 1,500 m world record of 3 minutes, 26 seconds in Rome on July 14, 1998.

Robot result: Team Tianzhuo's Tiangong Ultra completed its record-smashing hat trick, winning the 1,500 m in 2 minutes, 21.6 seconds β€” well below El Guerrouj's time. The next two finishers, at 2 minutes, 30.00 seconds and 2 minutes, 30.22 seconds, also bettered the human benchmark.

A black-and-white humanoid robot sprints on a blue track.

A Tai Gong Ultra humanoid robot runs to victory in the 1500 meter final at the 2nd World Robot Games at National Speed Skating Oval on August 23, 2026 in Beijing, China. (Image credit: Kevin Frayer / Stringer via Getty Images)

High jump: 2.88 m (9.45 feet) standing jump

Human benchmark: Javier Sotomayor of Cuba cleared 2.45 m (8.04 feet) in Salamanca, Spain, on July 27, 1993.

Robot result: A robot made by X-Humanoid cleared 2.88 m in a standing high jump, which smashed the previous best robot result of 0.95 m (3.12 feet) at the inaugural games in 2025. However, Sotomayor’s record came in a standard running high jump, in which athletes use a curved approach, generate speed and clear the bar using a technique called the Fosbury flop. The robot completed a standing high jump, a different event with different mechanics. The running high jump is both harder and higher than the standing jump, because athletes can convert horizontal speed into greater lift using a one-foot takeoff and the Fosbury flop, enabling higher clearances than the purely muscular, two-footed standing high jump.

What the record claims mean

These games showcase the expanding abilities of humanoid robots. Disciplines like running, particularly across longer distance events like the 1500 m, and high standing jumps require powerful actuators, fast balance corrections, foot-placement control and software that can compensate for tiny errors in real time.

"In my view, these World Records were achieved using, 'The Best Part is No Part' principle, through mostly mechanical optimization to perform a single task extremely well," said Scott Walter, the Robotics Research Diligence director at RoboStrategy, an investment fund that gives retail and institutional investors exposure to private and public companies in robotics and β€œembodied” or physical AI. "Locomotion is mostly solved as witnessed by these games, albeit with optimizations," he told Live Science in an email.

Walter said the key to many of the impressive advances we've seen is simplicity, shearing off unnecessary components that introduce more points of failure and can make coordination more difficult.

"Many degrees of freedom were removed in the arms (shoulders, elbow, no wrist, no hands), hips and ankles. This reduced mass, and allowed distal mass to be moved higher up in the kinematic chain, improving movement efficiency," he said.

However, although the robots were very capable in the specific events in which they competed, we shouldn't take that to mean they're top performers in other, more diverse tasks.

"The bots are barely humanoid and could only accelerate in a straight line, not stop without crashing nor run the curve to slow down," Walter said. "The winners were in no shape afterwards to stand on the podium to receive their medals. Nor could they run in the 4x100 relay as, ironically, they had no hands for the 'hand-off.'"

Some robots were seen crashing into barriers or falling, and others caught fire, highlighting that reliability is still an issue.

But other robots at the games were made for more than just going faster, higher, stronger. Alongside track-style events, robots performed practical tasks such as connecting charging cables, handling objects, using tools and working in simulated industrial or service settings.

In many cases, the greater challenge is not raw strength or speed but reliably seeing an object, judging its position, applying the right amount of force and recovering when something does not go as planned. More than 40% of the games' events required robots to operate autonomously, without direct human control.

"Manipulation is the greatest biggest challenge as that is the business end of the humanoid and a dexterous and robust hand is still elusive," Walter said. "Specialization is easy, general purpose is not."

Walter noted that the decathlon record may be the next target as it demonstrates a range of abilities.

"The human Decathlon record is the true test of speed, endurance, power, strength, robustness, coordination and dexterity. I would not be surprised to see an attempt at the record next year," he said.

  •  

Remembering the pre-Google web, when search was an experiment

In the mid-'90s, the web was exploding, but finding anything of actual value on it felt like an elaborate negotiation with whatever proto-search engine happened to be standing closest to the door. Unlike now, when Google is widely seen as both portal and gatekeeper, sites like AltaVista, Lycos, Excite, HotBot, and Ask Jeeves promised to tame the chaos, each with its own suite of quirks, charms, and flaws.

The real story of pre-Google search is not that early engines were inferior. It's that they reflected a different Internet entirely, one where directories mattered, crawling was still an art, ranking was fragile, and the idea of β€œsearch” had not yet hardened into a single dominant interface.

A different kind of web

The first thing to remember about the pre-Google Internet is that there was no built-in assumption that you could search for everything. Many users found pages through Yahoo-style directories, bookmarks, newsgroups, email signatures, and links from site to site because the web was still small enough that human organization could compete with machine indexing. It was an era of Wild West-style discoverability. Search engines existed, but they were only one part of a larger ecosystem that blended curation and accident.

Read full article

Comments

Β© Aurich Lawson

  •  
❌