Login

Video: Ceiling-mounted DIY robot picks up toys, clothes, and household clutter
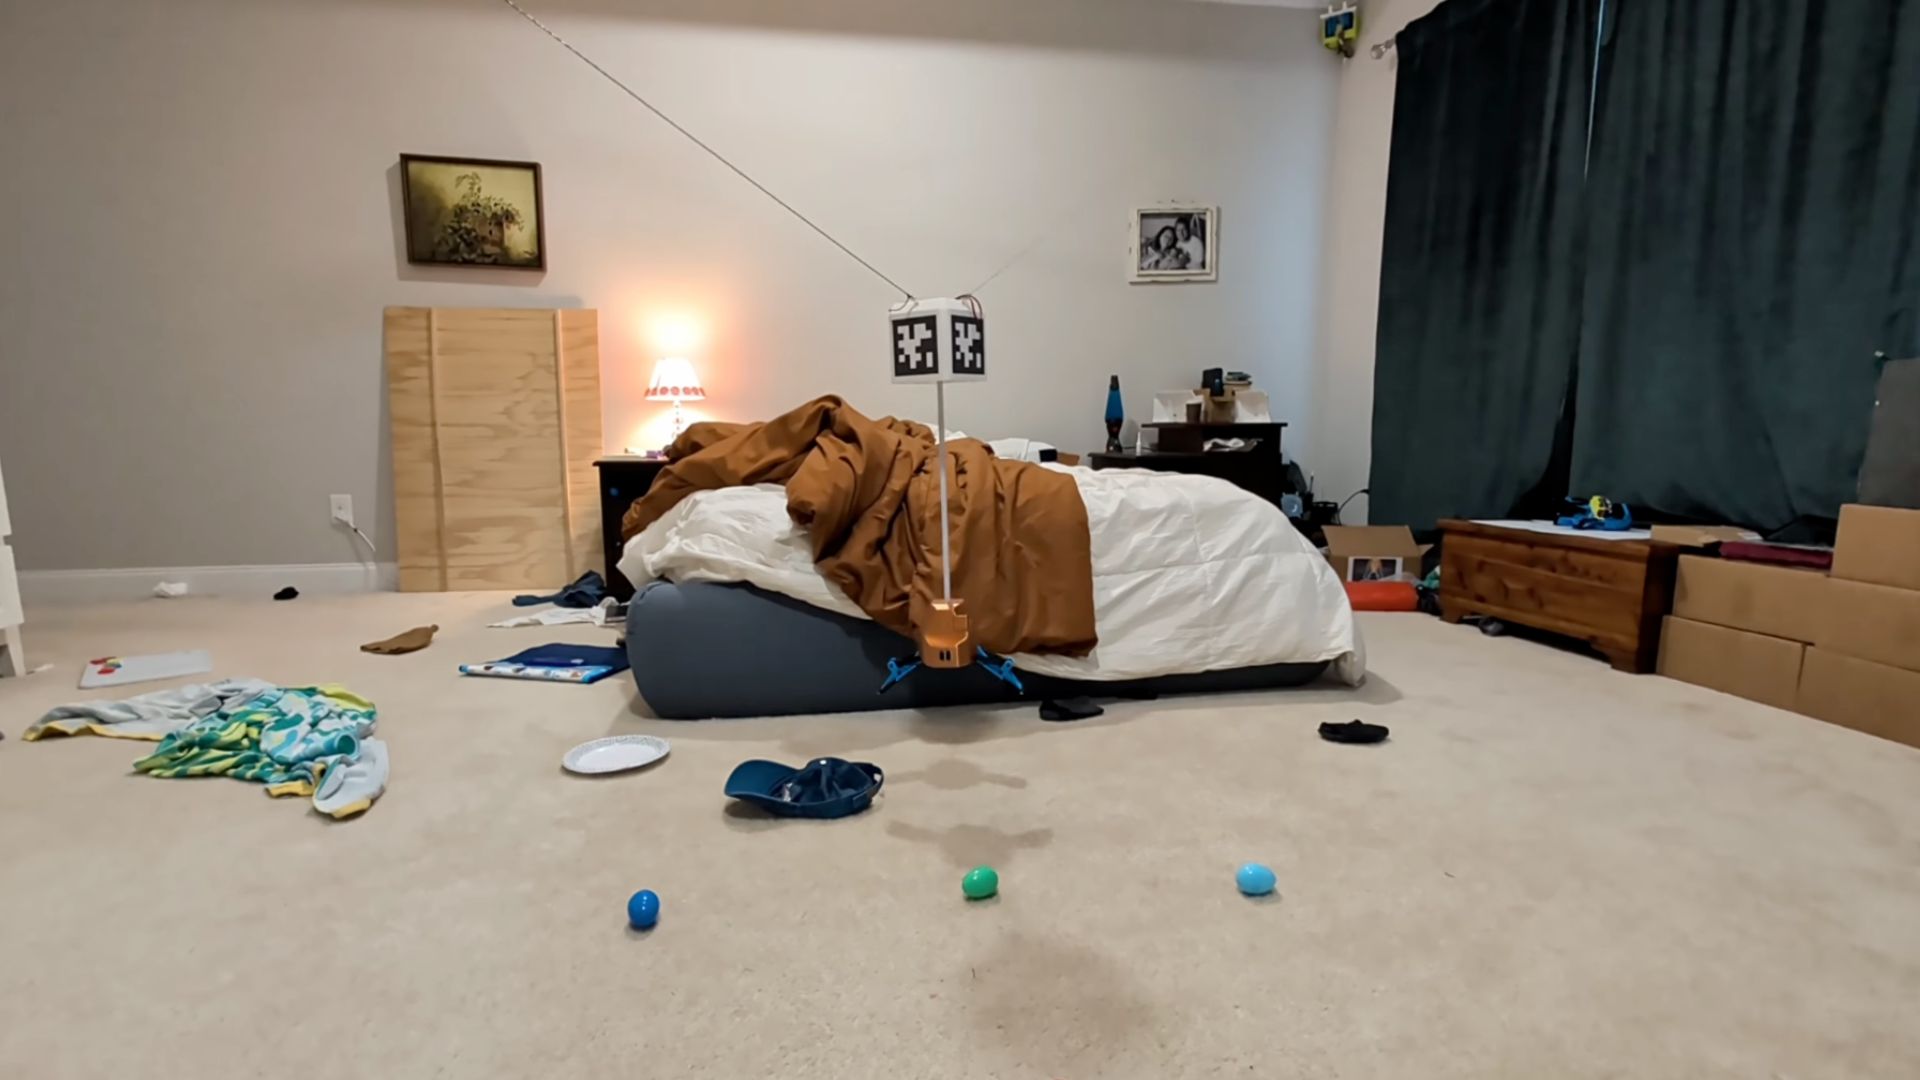
An engineer has developed an open-source ceiling-mounted robotic claw designed to tackle one of the constant challenges of family life—cleaning up clutter.
Called Stringman, the system uses cables suspended from four corners of a room to move a robotic gripper across the ceiling, locating and collecting items such as toys, clothing, and other household mess.
Powered by LeRobot-based firmware, the robot can identify objects, pick them up, and transport them to designated drop-off points.
According to its maker, the project’s software, hardware designs, and build instructions are available on GitHub. At the same time, ready-to-use kits are also being offered for users who prefer not to build the system themselves.
Stringman tackles clutter
The DIY cleaning robot is designed to tackle one of the most common household challenges—clutter left behind by children and pets.
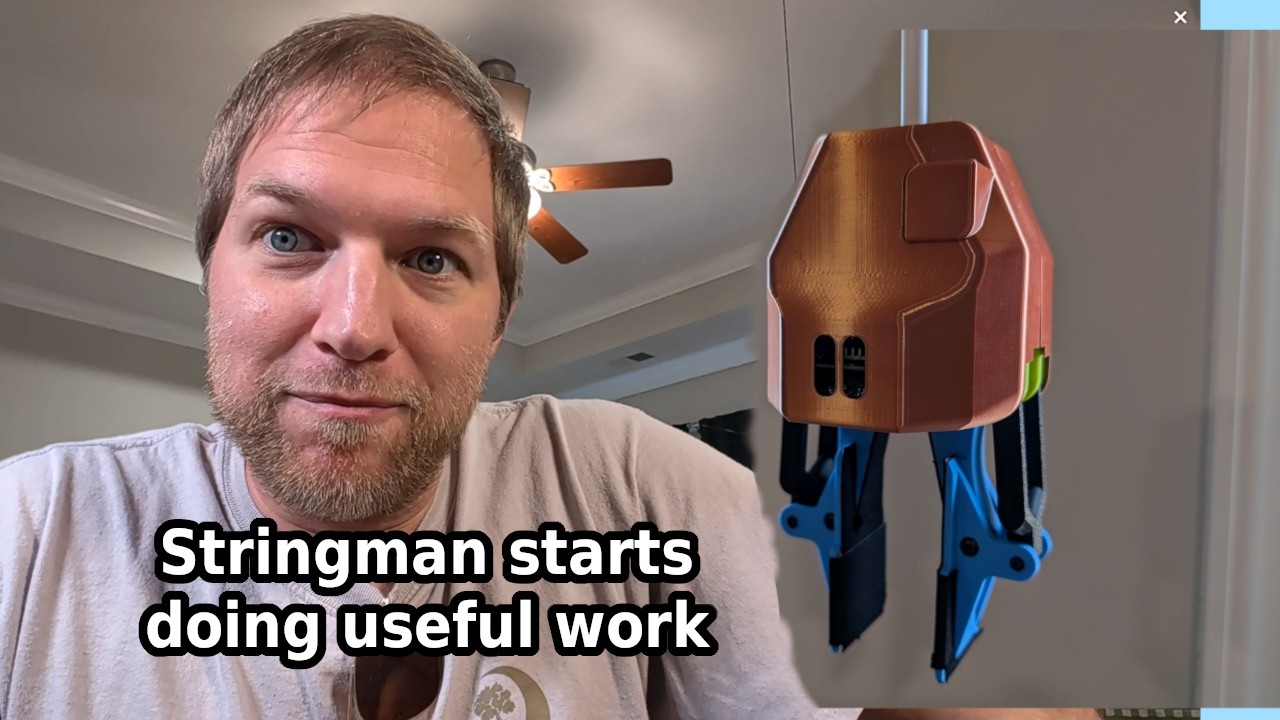
Stringman is a cable-driven robotic crane that moves across a room using high-strength lines suspended from anchors mounted in its four corners. Rather than relying on a humanoid design or a mobile robot, Stringman uses a lightweight gripper that travels through the room’s airspace, identifying and collecting objects from the floor before transporting them to designated drop-off locations.
The project was created by Nathaniel Nifong, who believes many household tasks can be automated without the complexity and cost associated with humanoid robots. According to the project’s website, reducing the number of actuators significantly lowers the overall cost of robotics hardware. Stringman relies on just four motors and a two-finger gripper with a wrist mechanism, allowing it to perform basic pick-and-place tasks while remaining relatively affordable.
The robot is built on the open-source LeRobot platform and uses imitation learning to improve its grasping capabilities. Users can train the system through teleoperation, teaching it how to pick up various household objects. The software, firmware, mechanical designs, and build instructions are publicly available under an Apache 2.0 license, allowing enthusiasts to build, modify, and contribute to the project.
To organize items, users simply designate destinations such as laundry baskets, toy bins, or trash cans using clip-on fiducial markers. Stringman’s vision system maps these locations and generates a list of objects it believes should be collected. Users can review and modify these selections through an interface or manually click objects they want the robot to remove.
Open-source robot
One of the system’s biggest advantages is its reach. Unlike robotic arms that are confined to a limited workspace, Stringman can access much of an entire room. Its cable-driven architecture enables it to move from floor-level pickups to elevated shelves without requiring rails, wheels, or articulated limbs. Because it is powered directly from a wall outlet, it also avoids the charging downtime that limits many mobile robots.
The design incorporates active swing-cancellation algorithms to stabilize the gripper as it moves. This is particularly important because the gripper hangs approximately 50 centimeters below the suspension point, allowing it to reach beneath furniture and alongside obstacles. The software continuously compensates for momentum, helping maintain accurate positioning during movement, according to its website.
Privacy has also been a focus of the project. Stringman supports a fully local operating mode in which video processing and telemetry remain within the home network. Users who prefer remote access can connect the robot to an online account and monitor or control it through a web-based interface.
Despite its promise, the system remains a work in progress. The machine-vision models still require refinement, and certain objects—particularly flat items such as books—can be difficult for the gripper to handle reliably. The suspended cables also descend into the room while the robot is operating, creating practical limitations for occupied spaces.
Even with these challenges, Stringman represents an intriguing alternative to humanoid domestic robots. By focusing on a single household task and simplifying the hardware, the project demonstrates how practical home automation may emerge from specialized, low-cost designs rather than human-shaped machines. Future developments could potentially allow the robot not only to collect clutter into bins but also to return items directly to their proper storage locations.